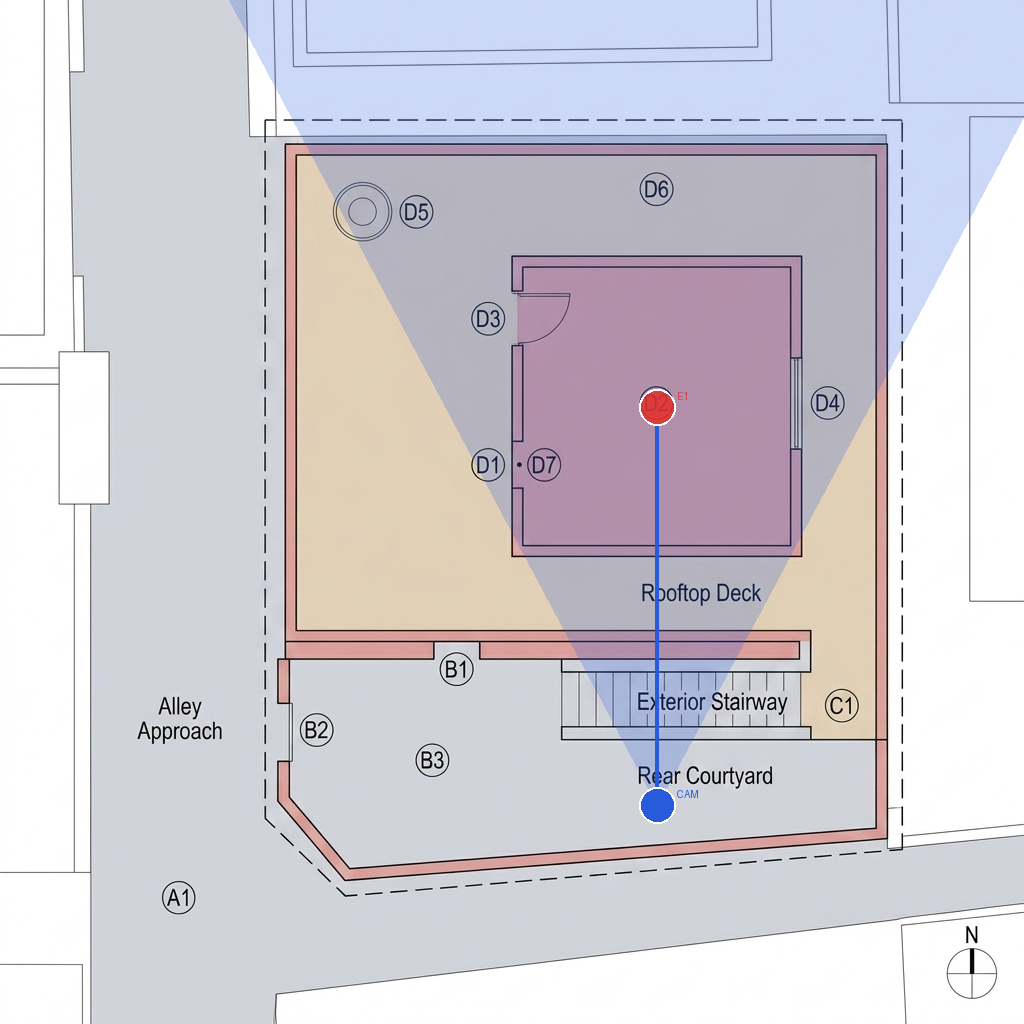
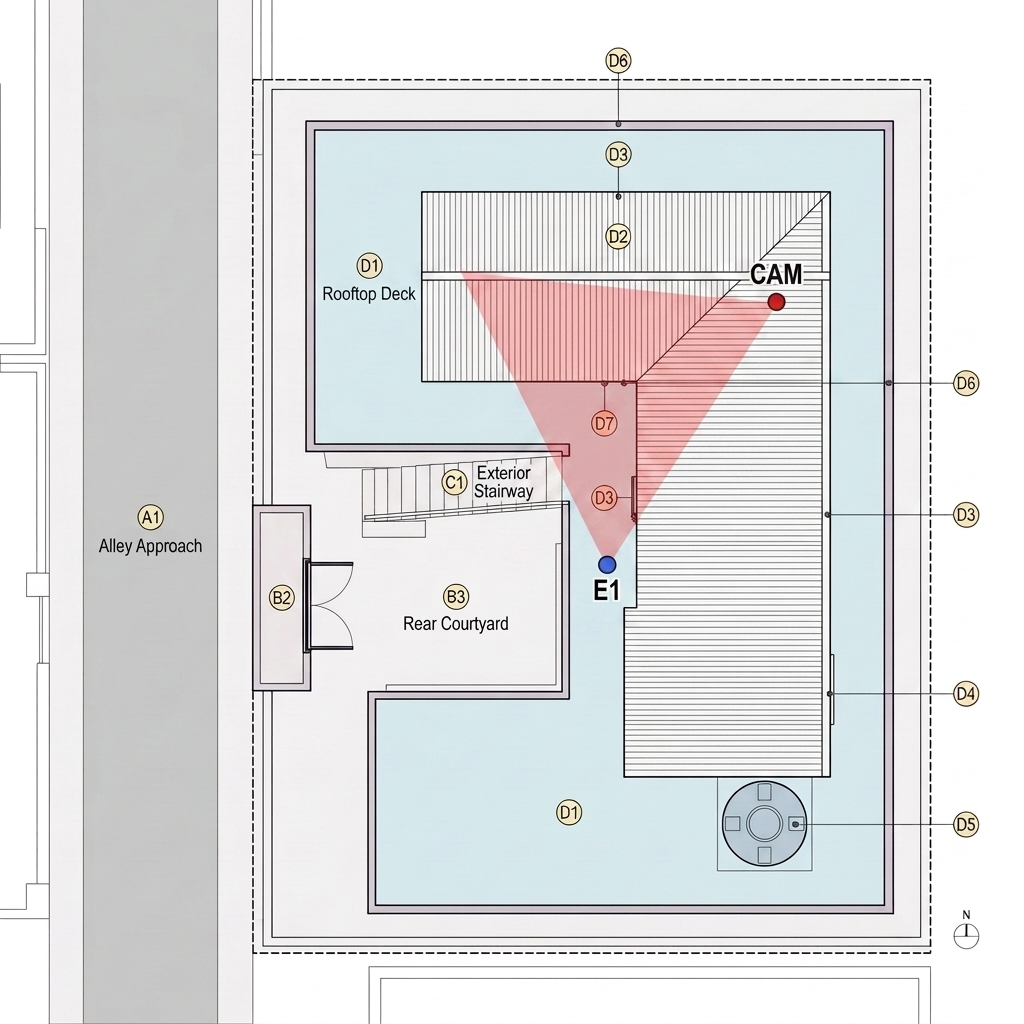
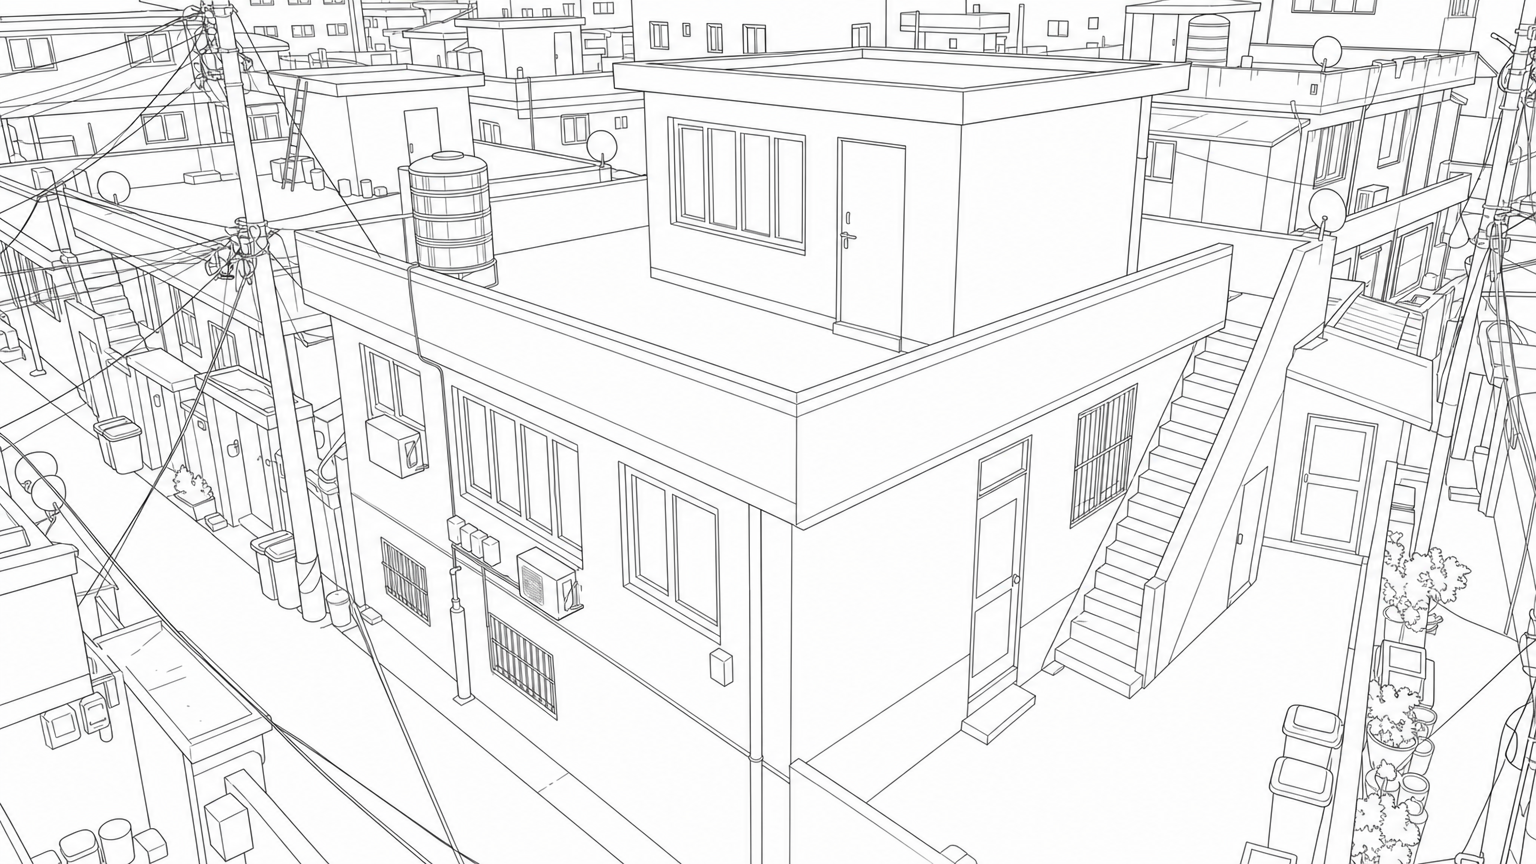
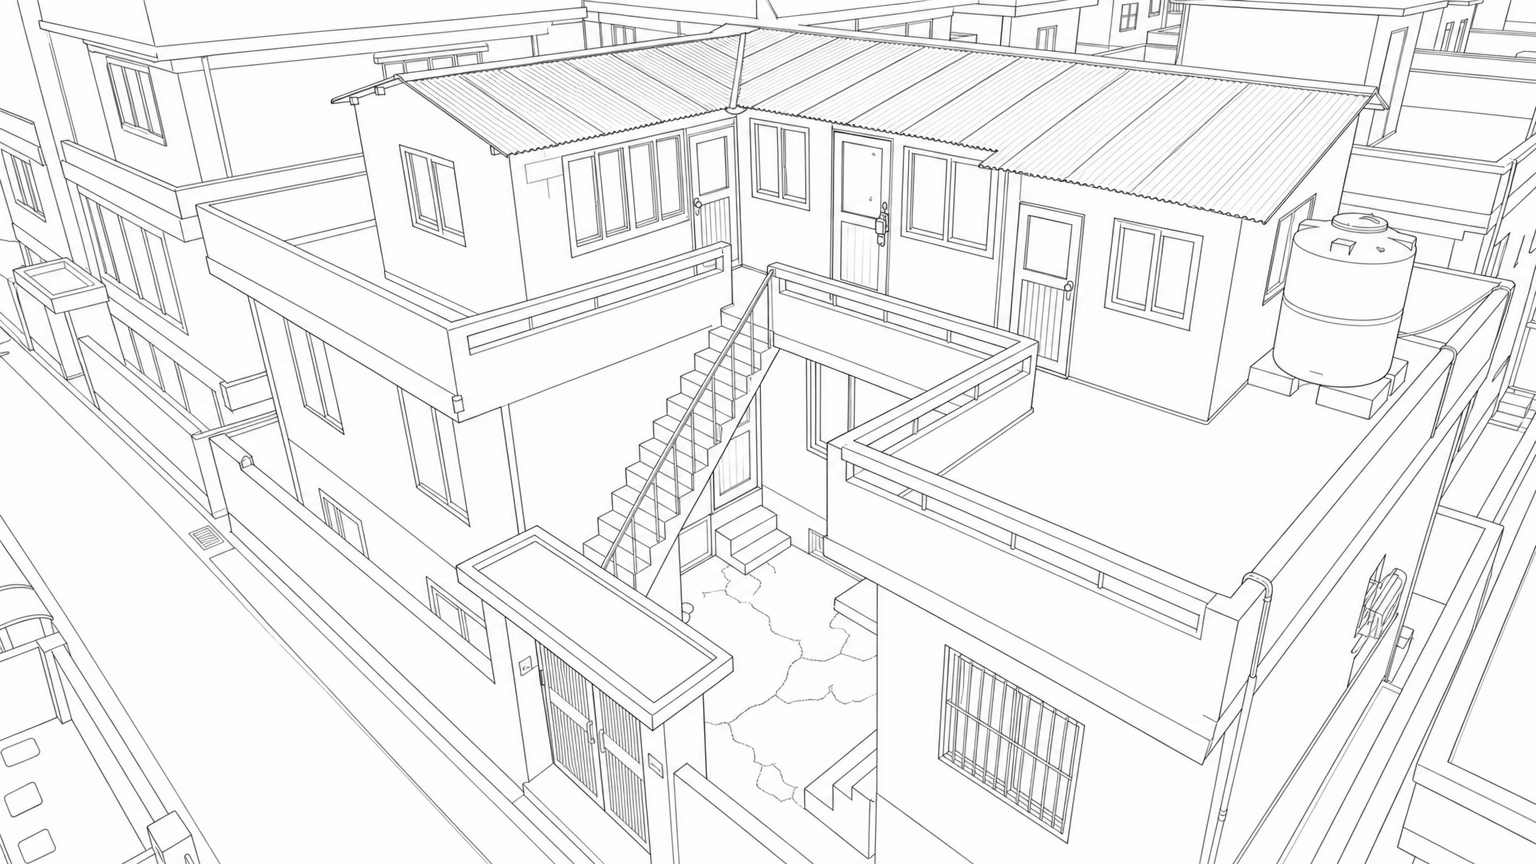
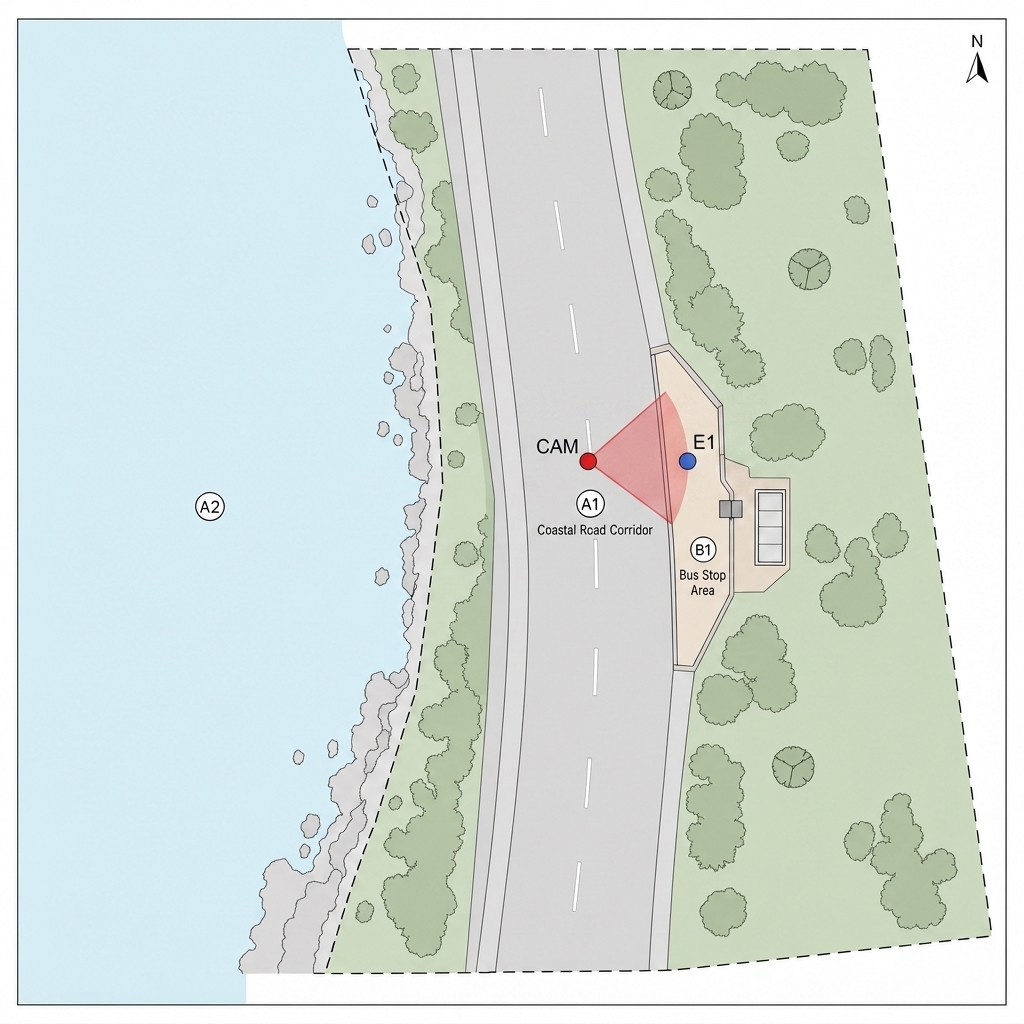
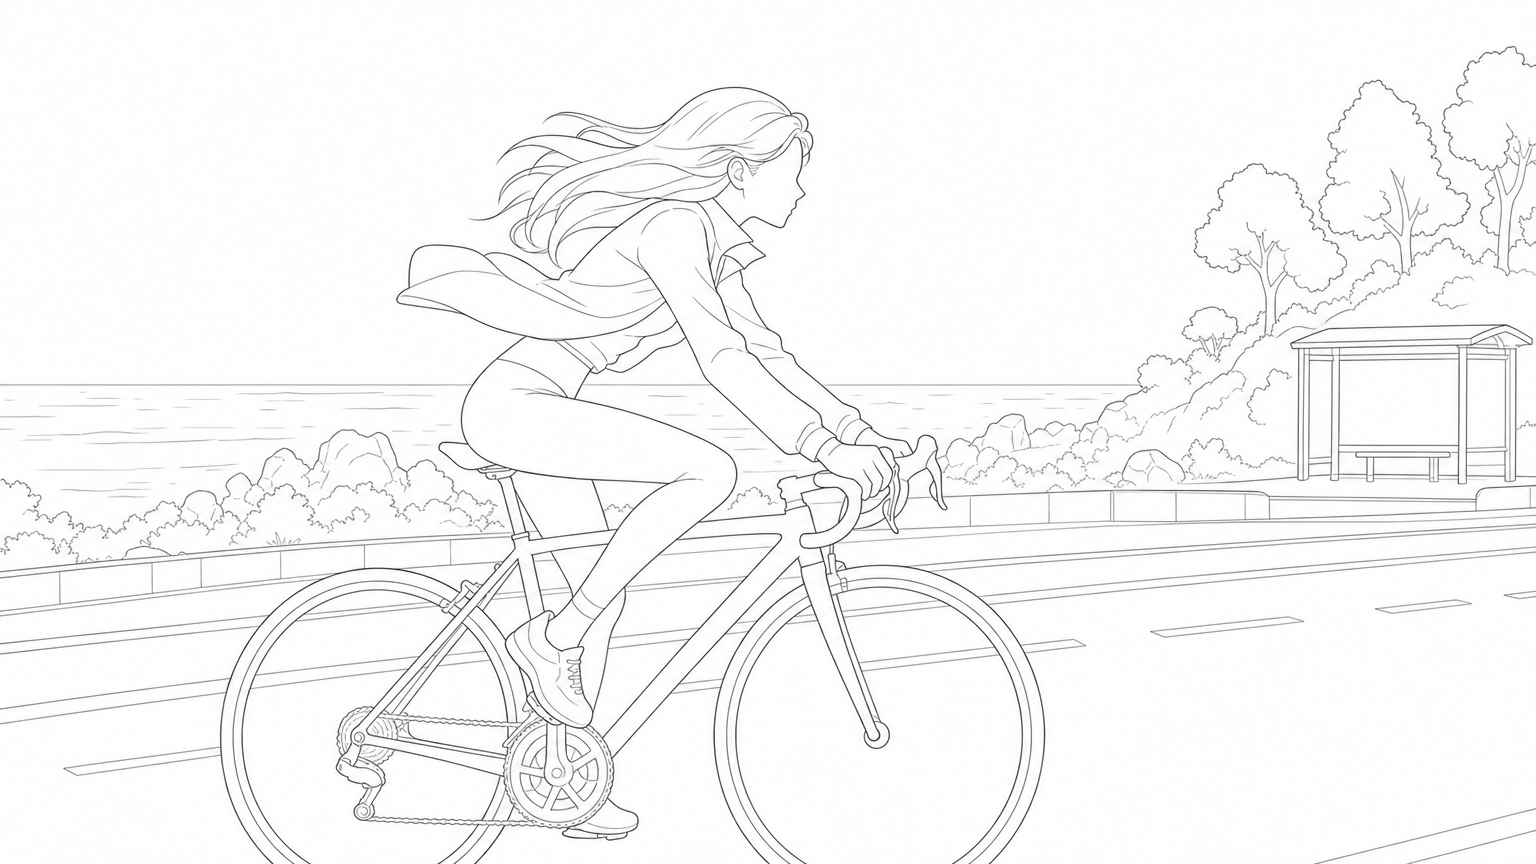
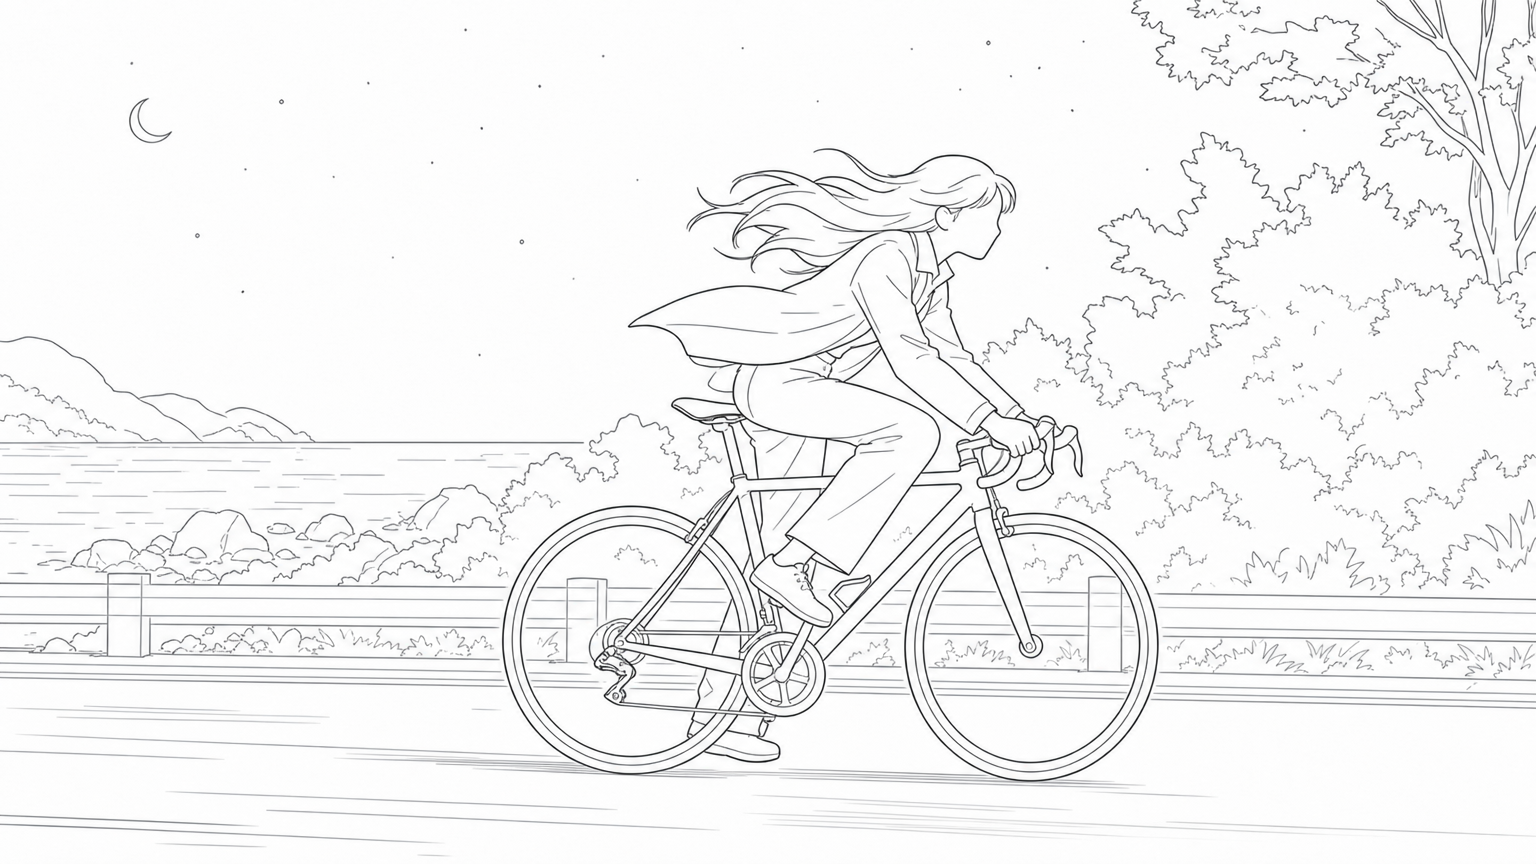
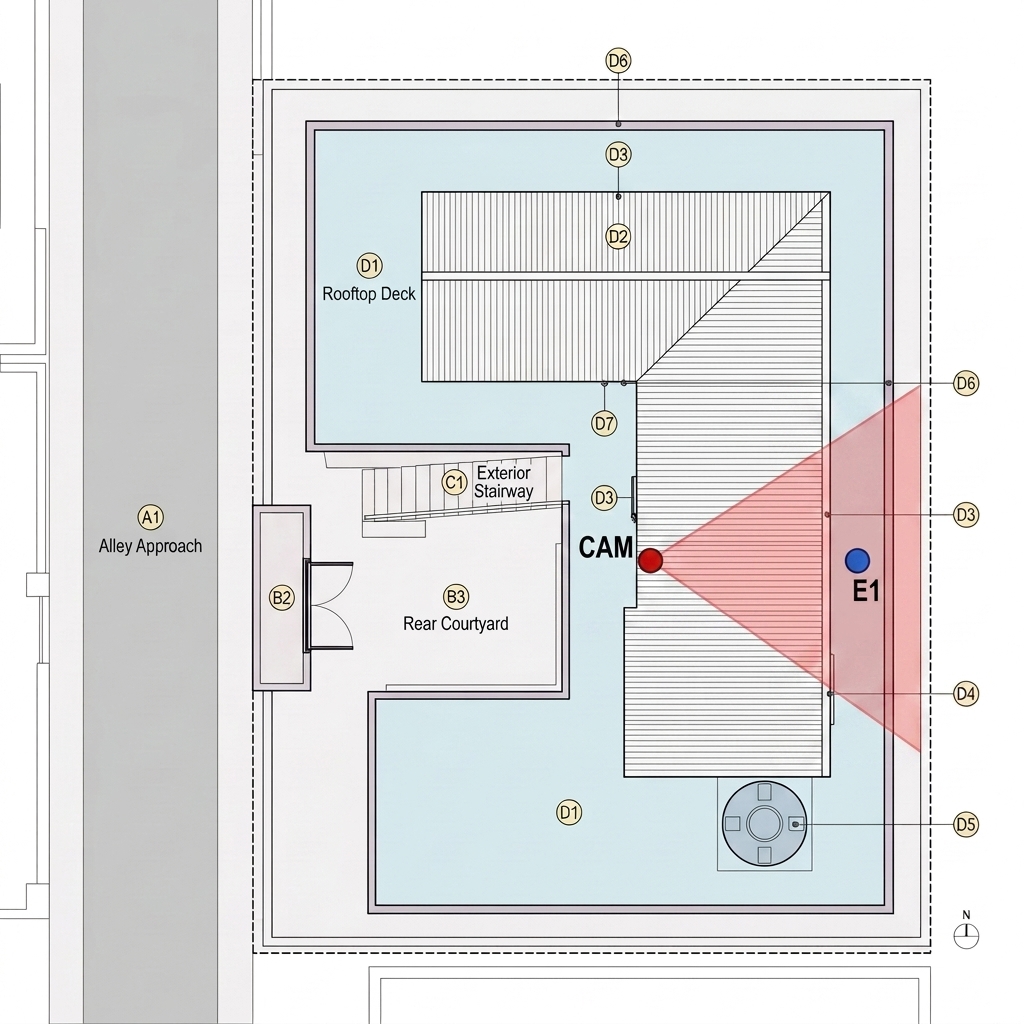
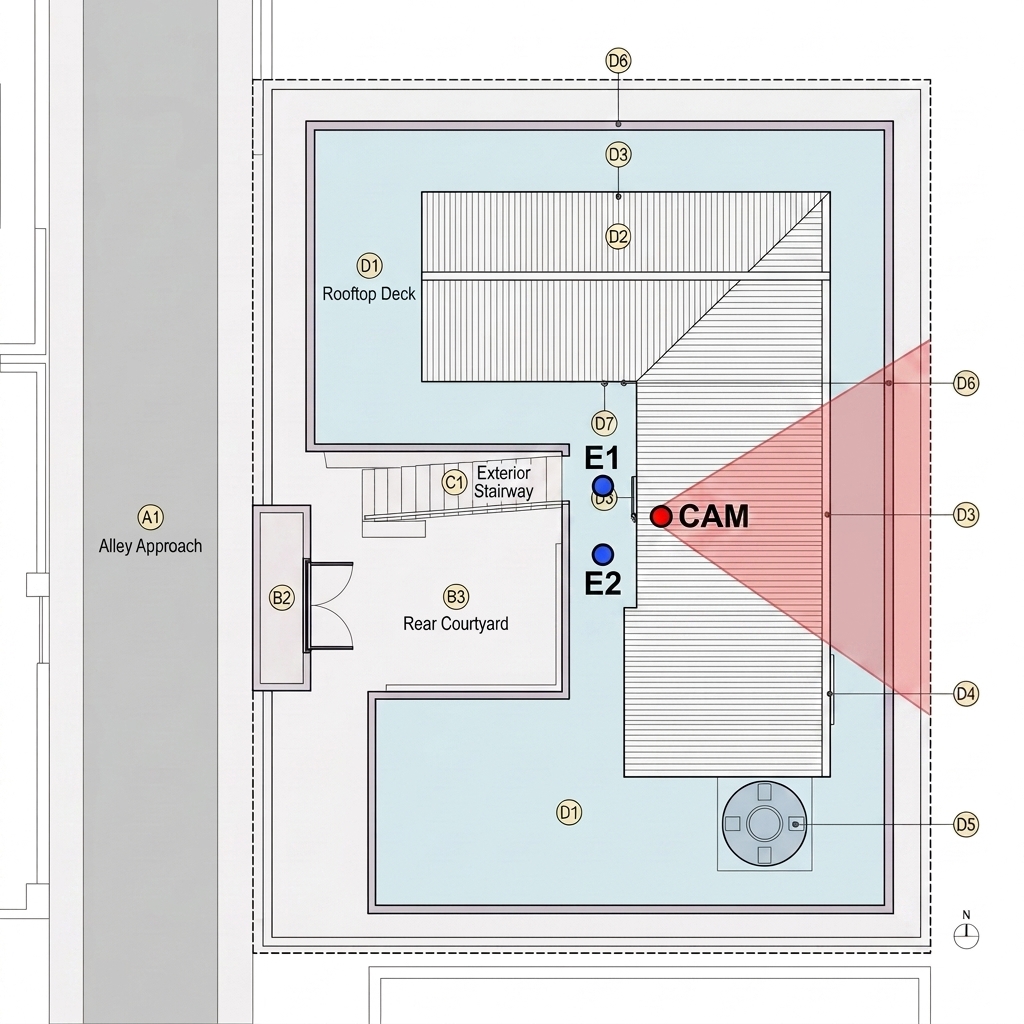
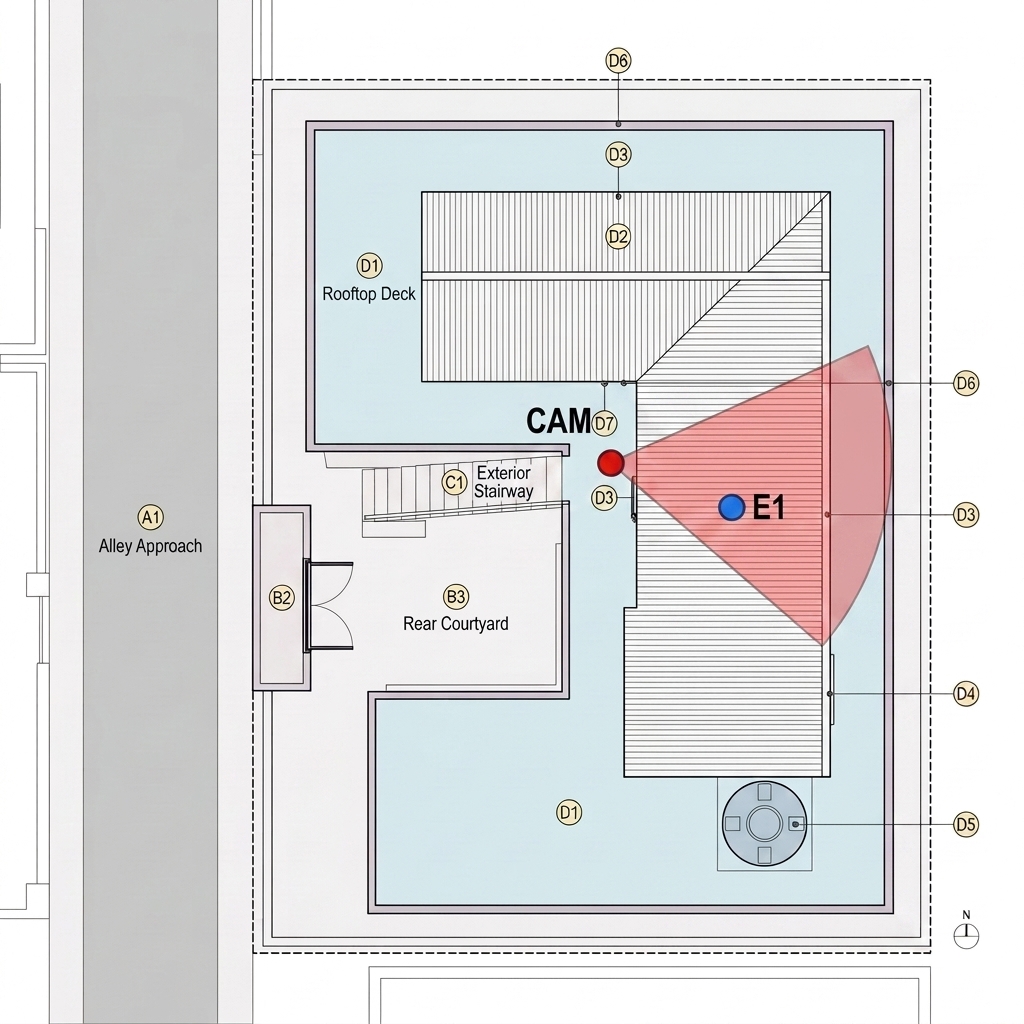
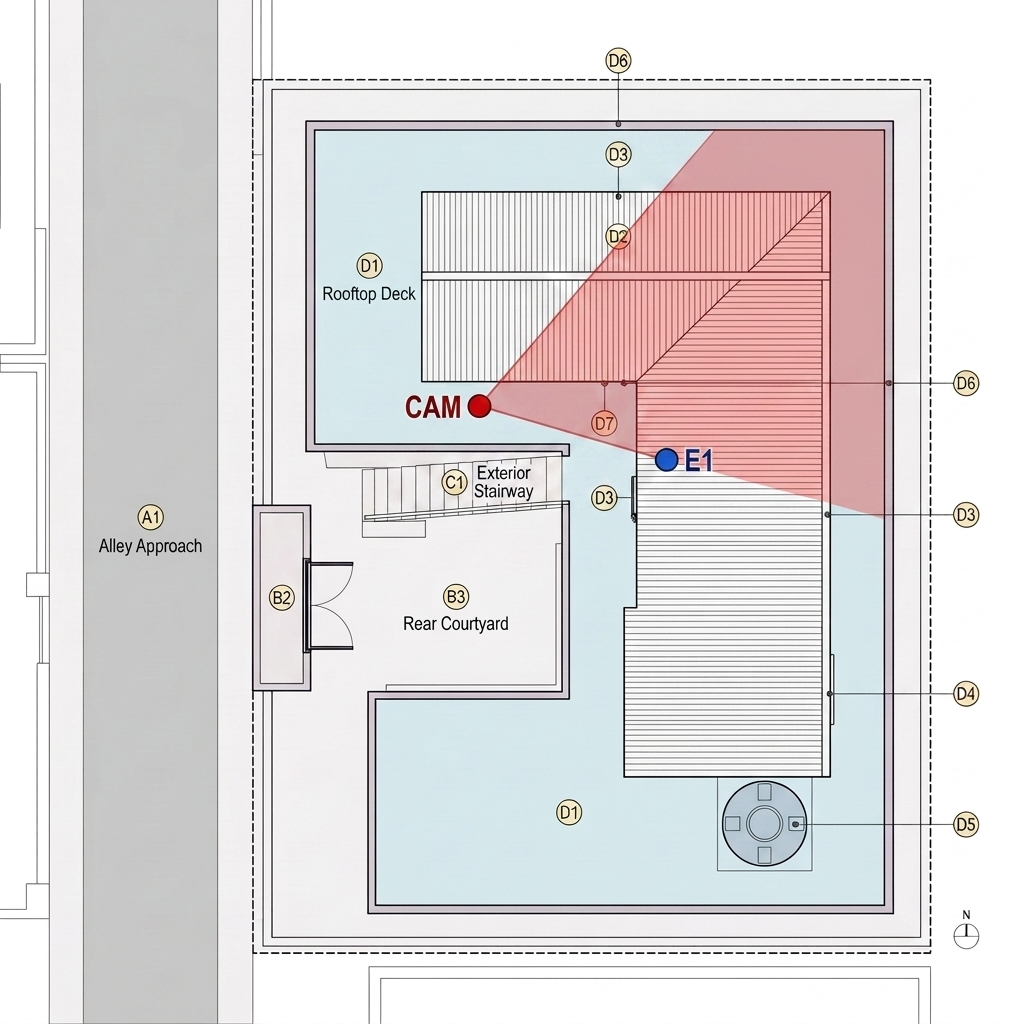
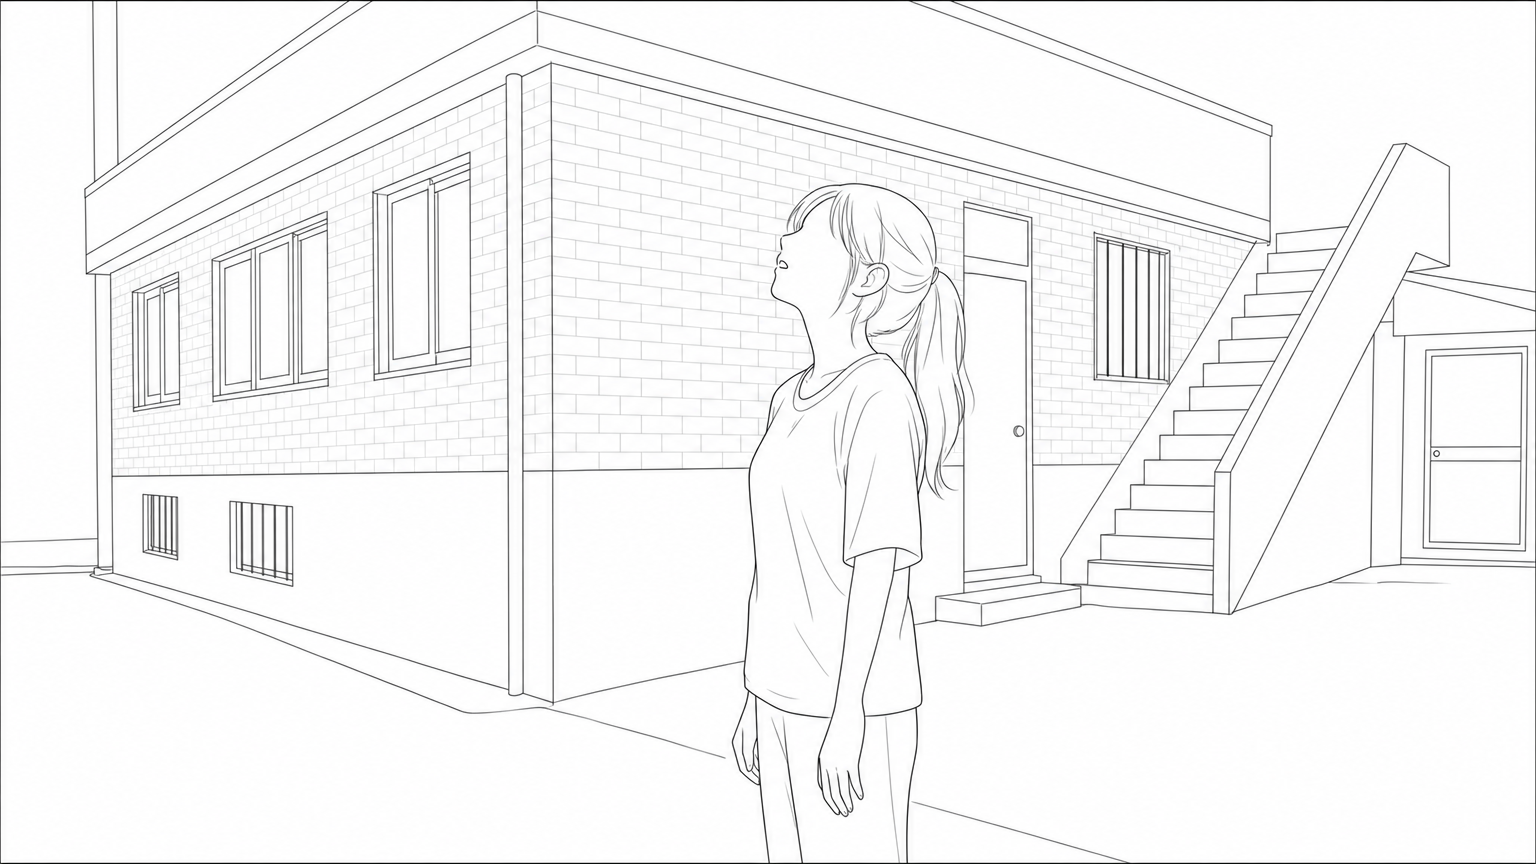
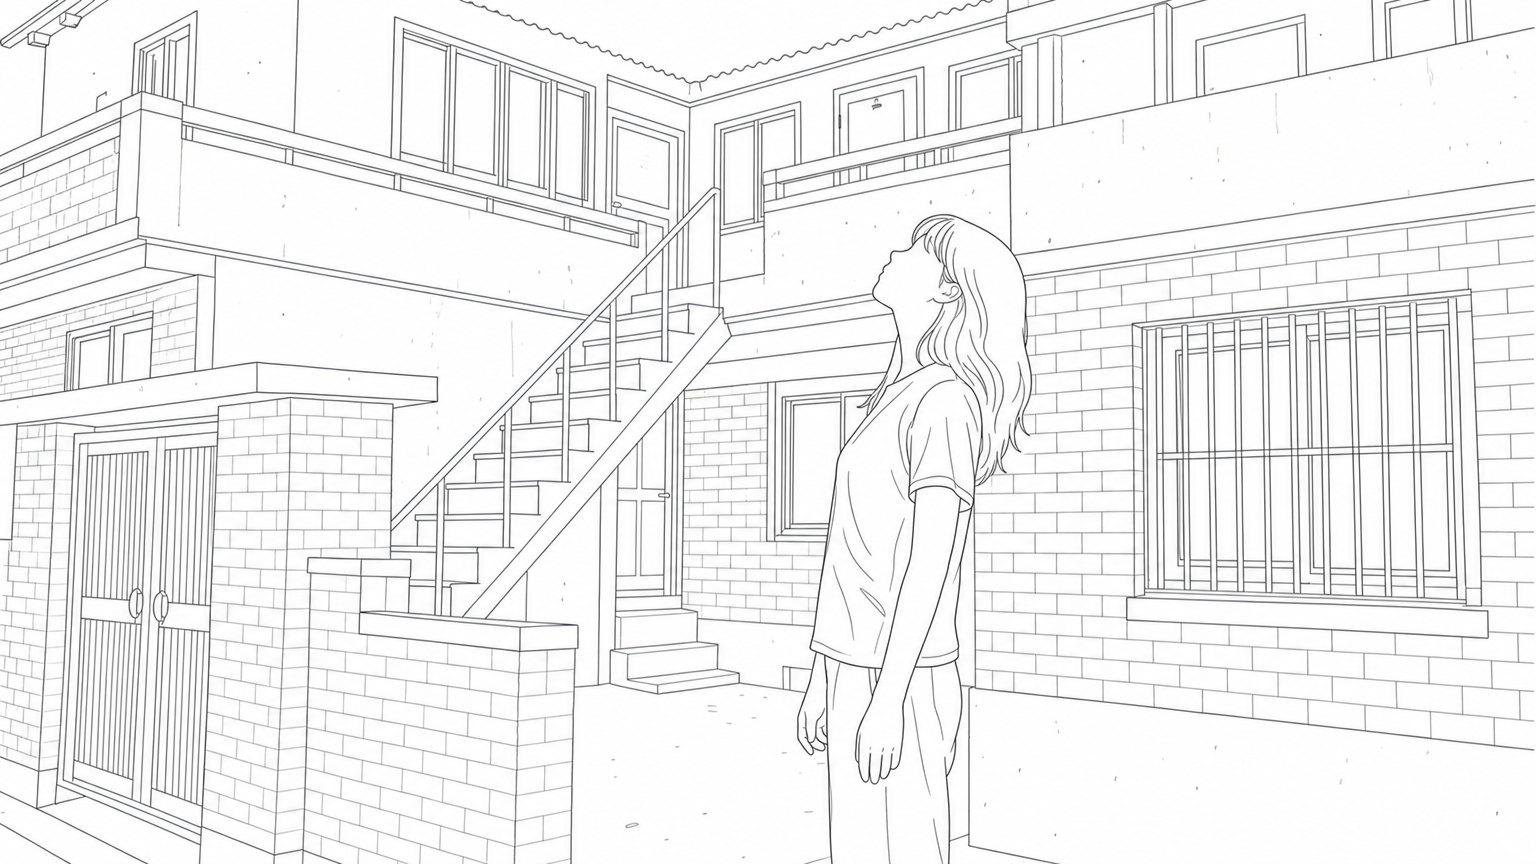
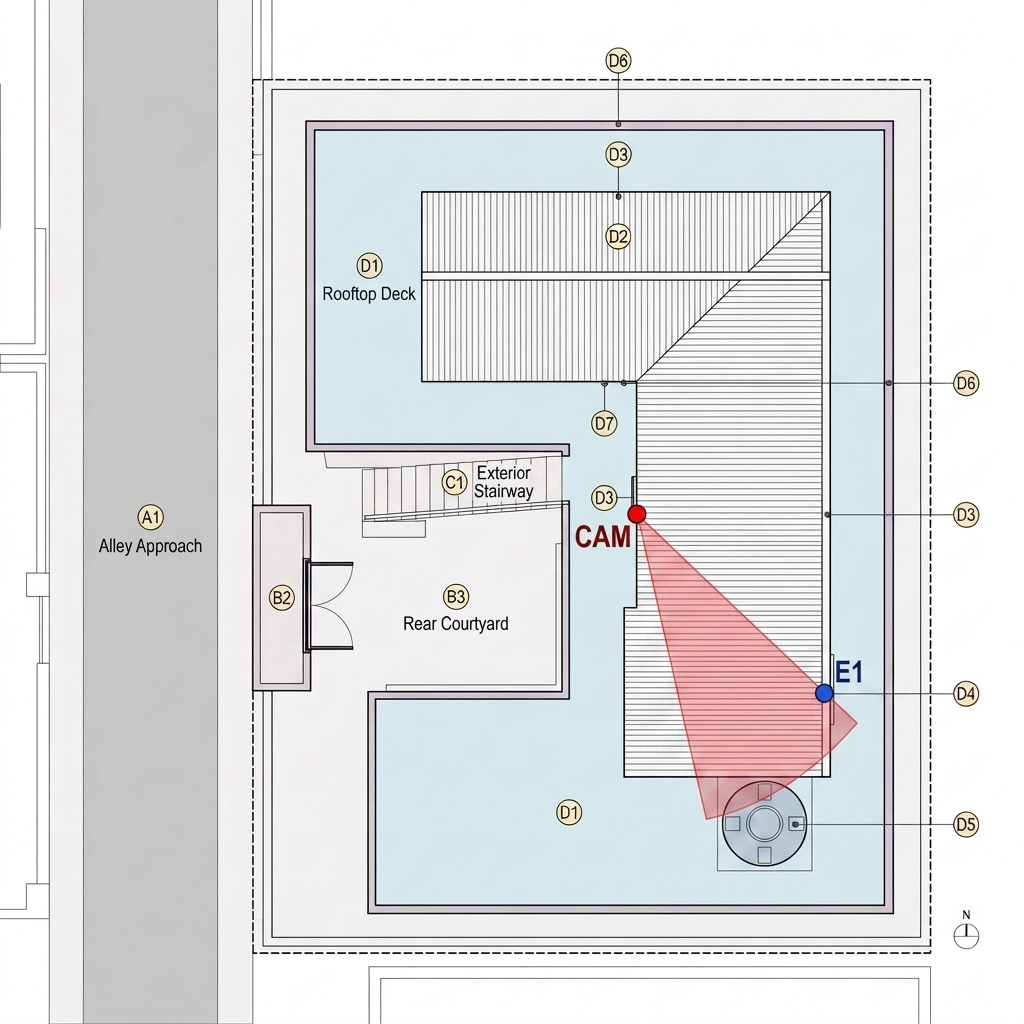
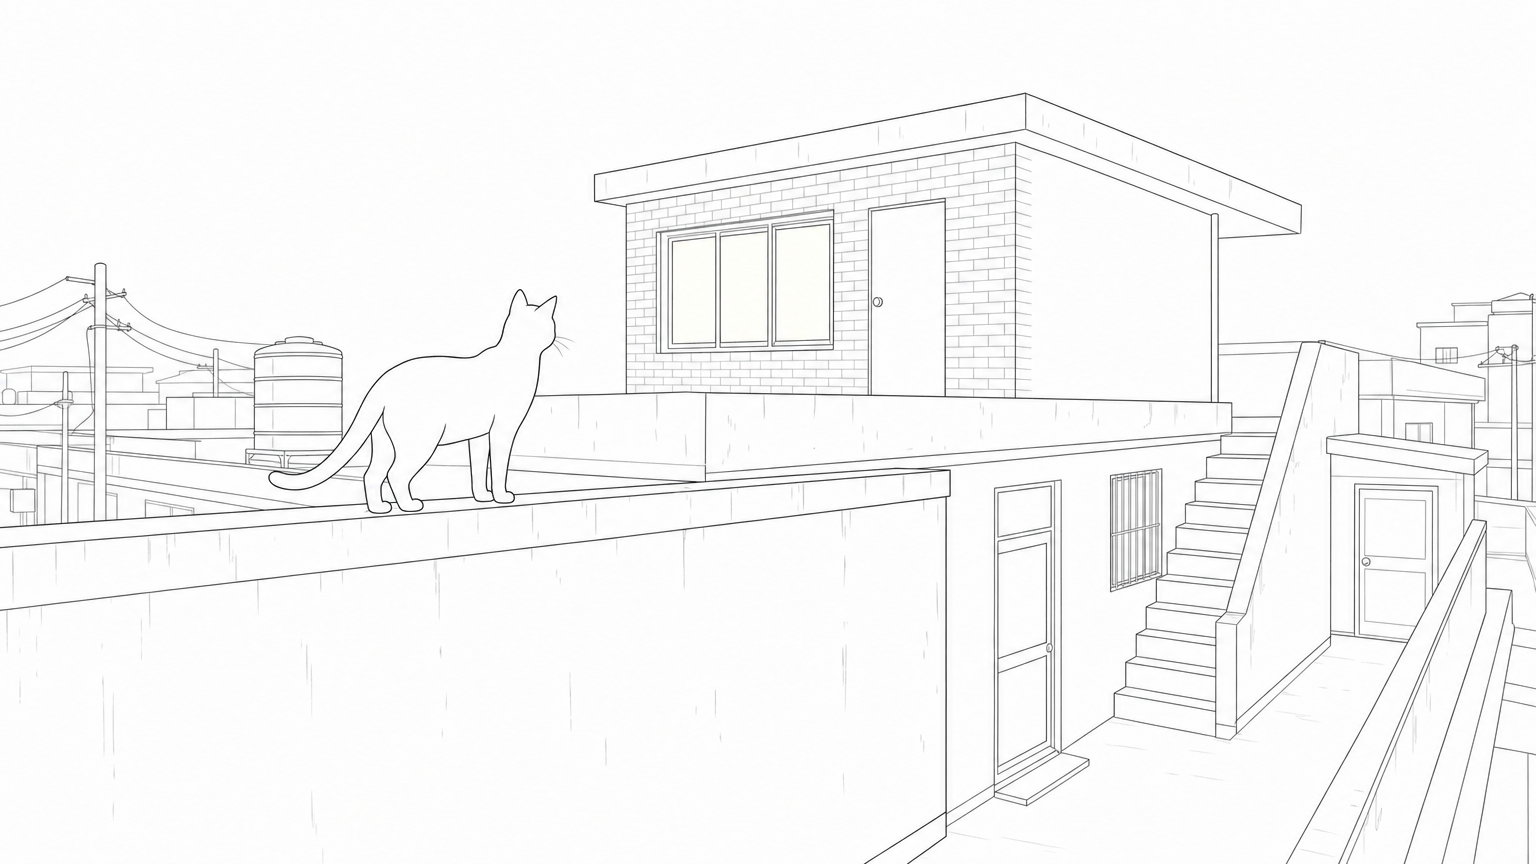
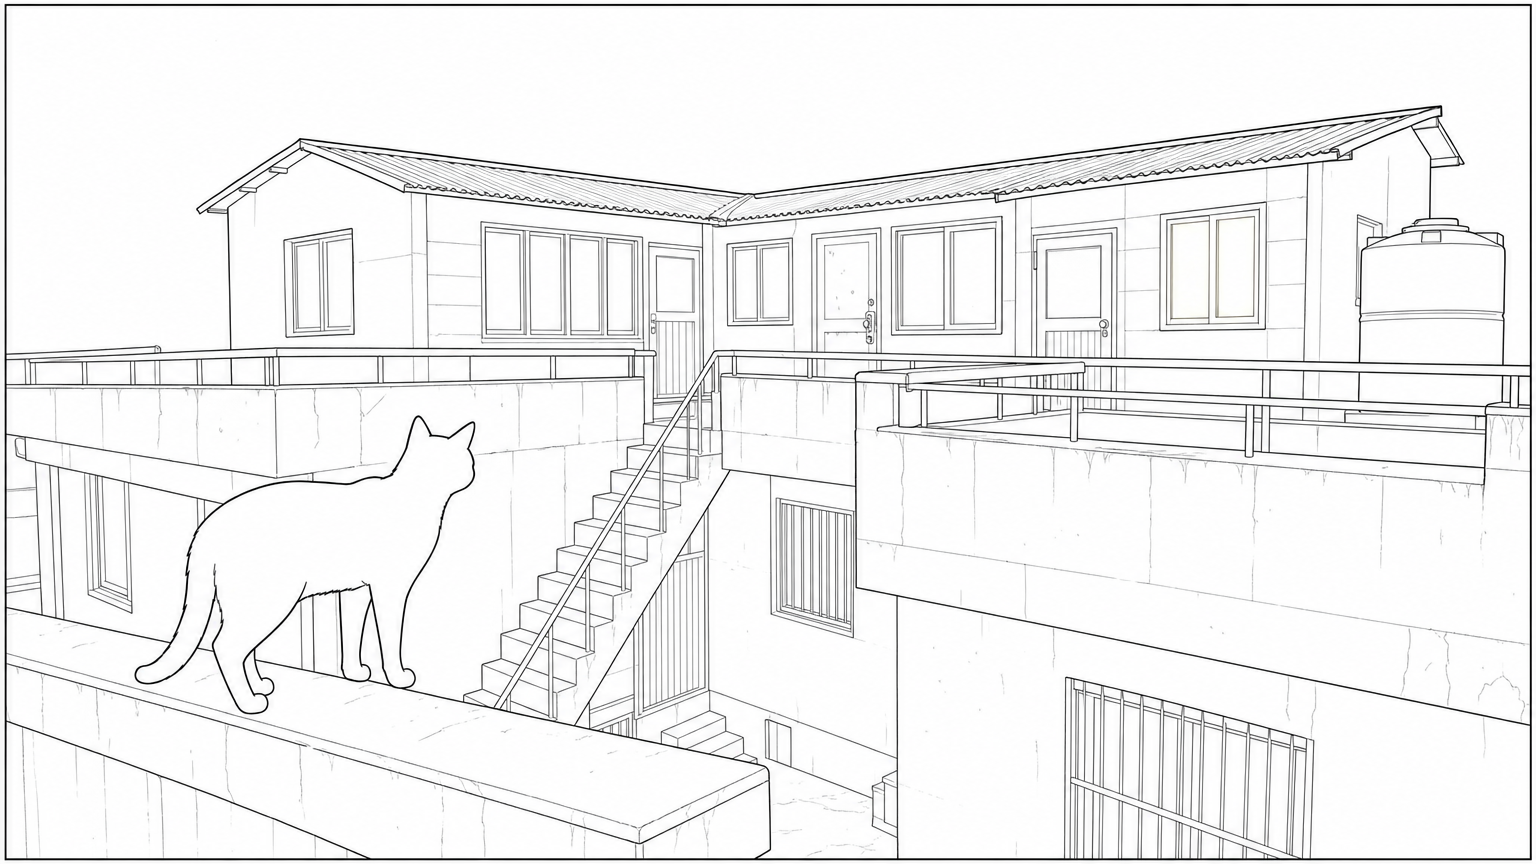
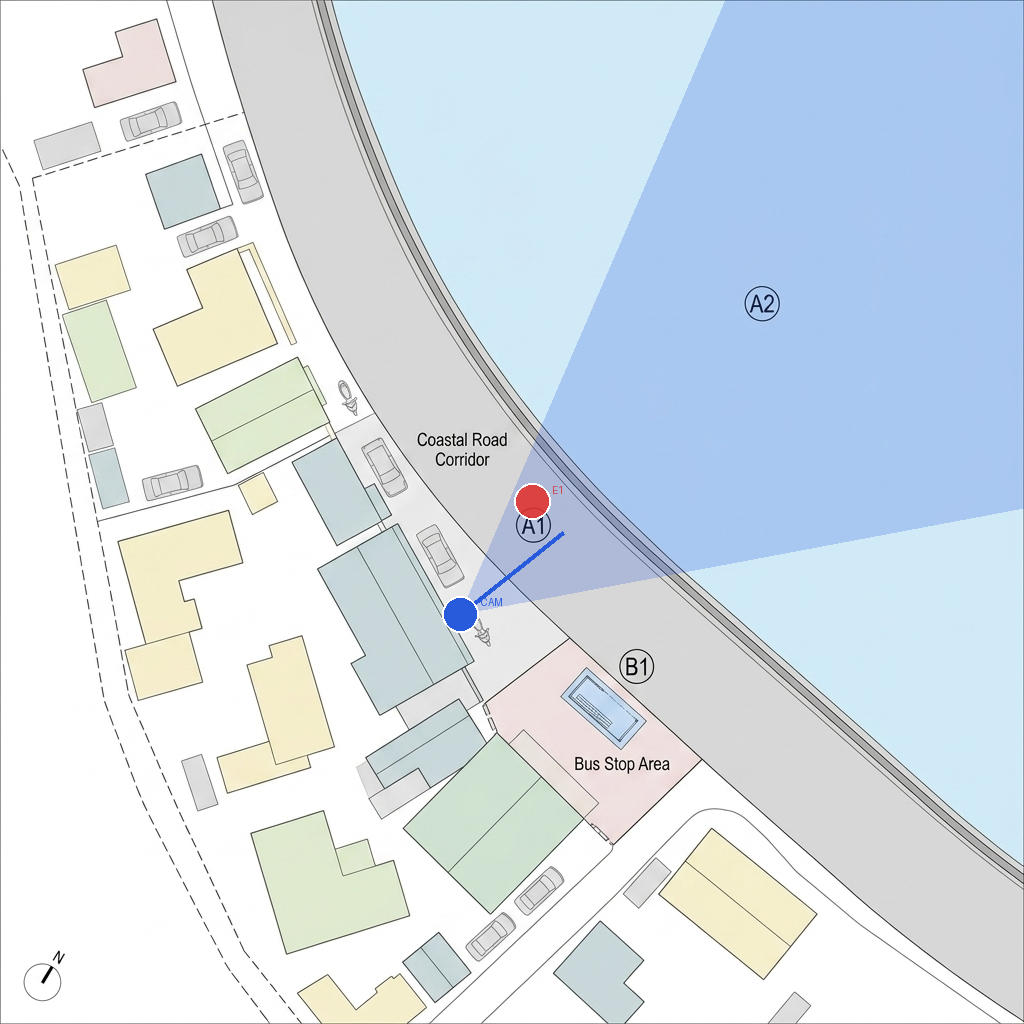
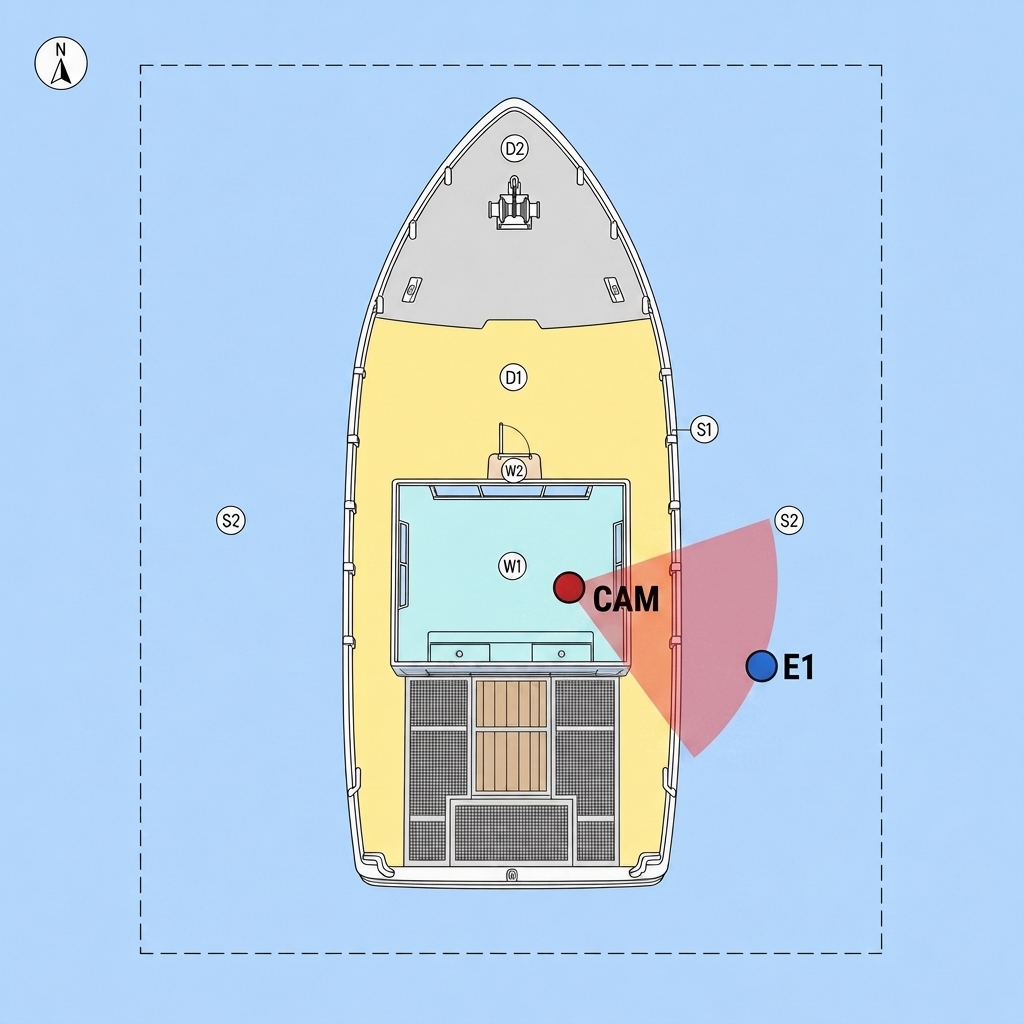
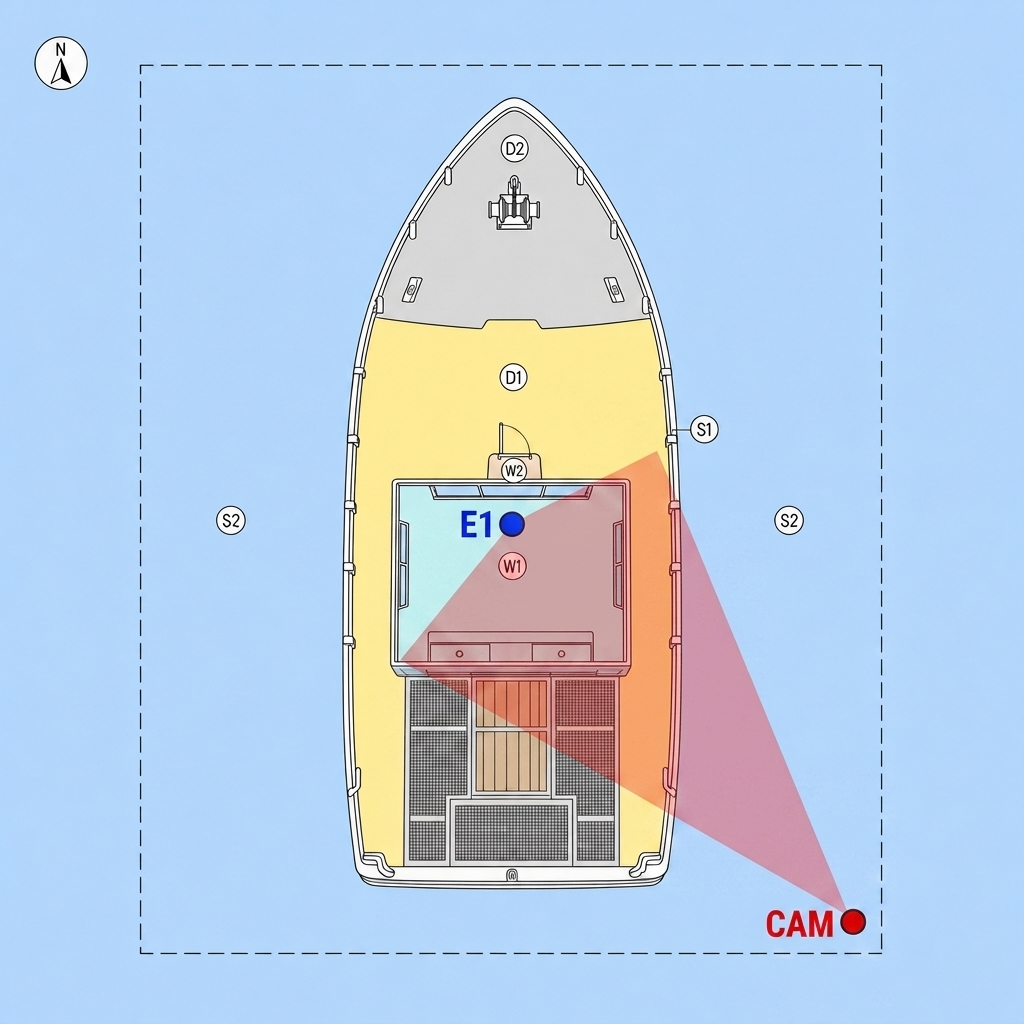
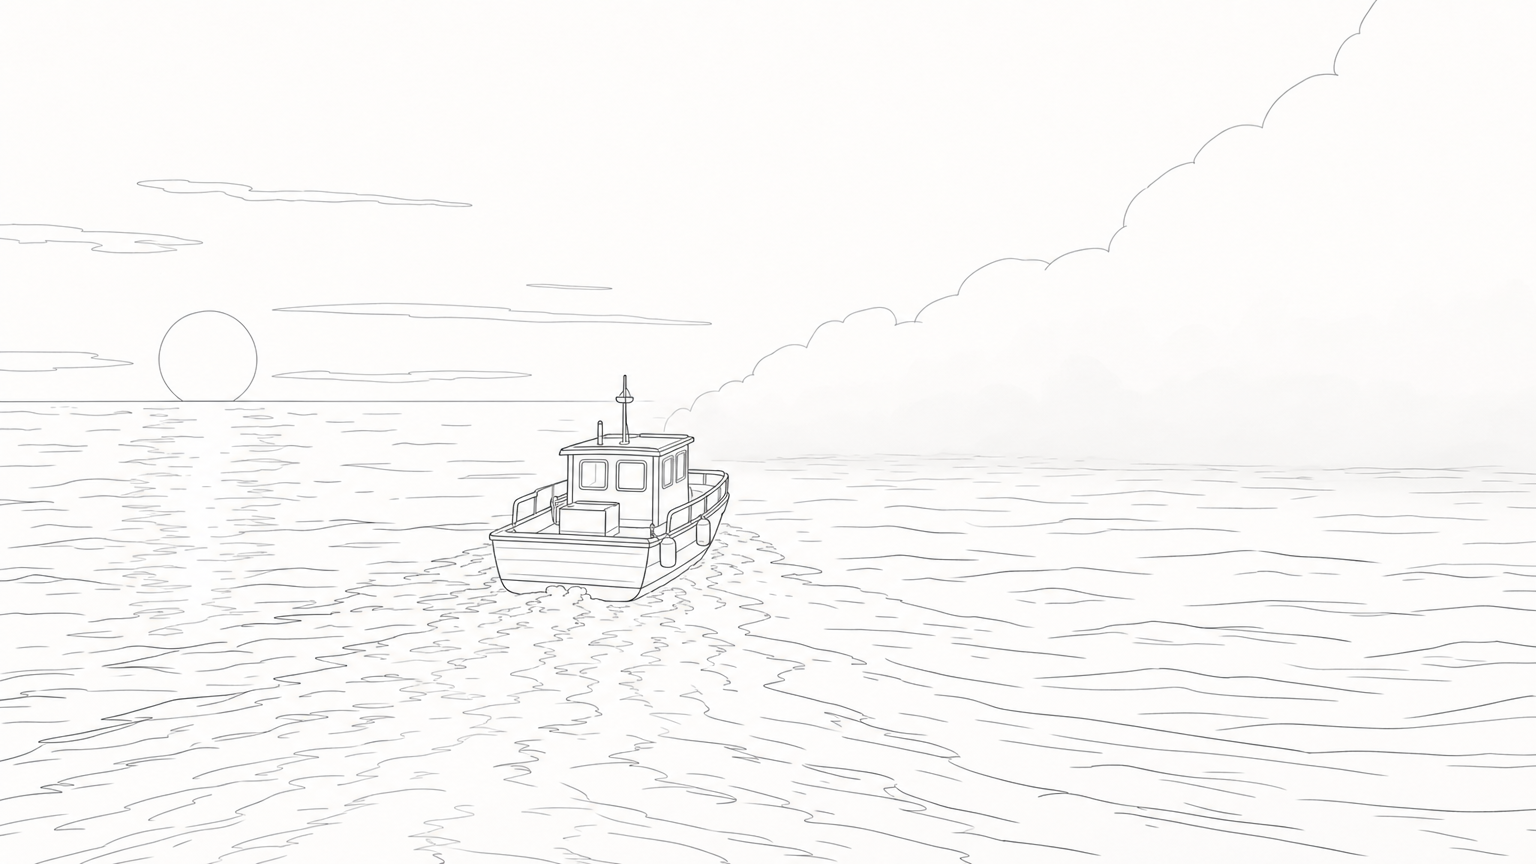
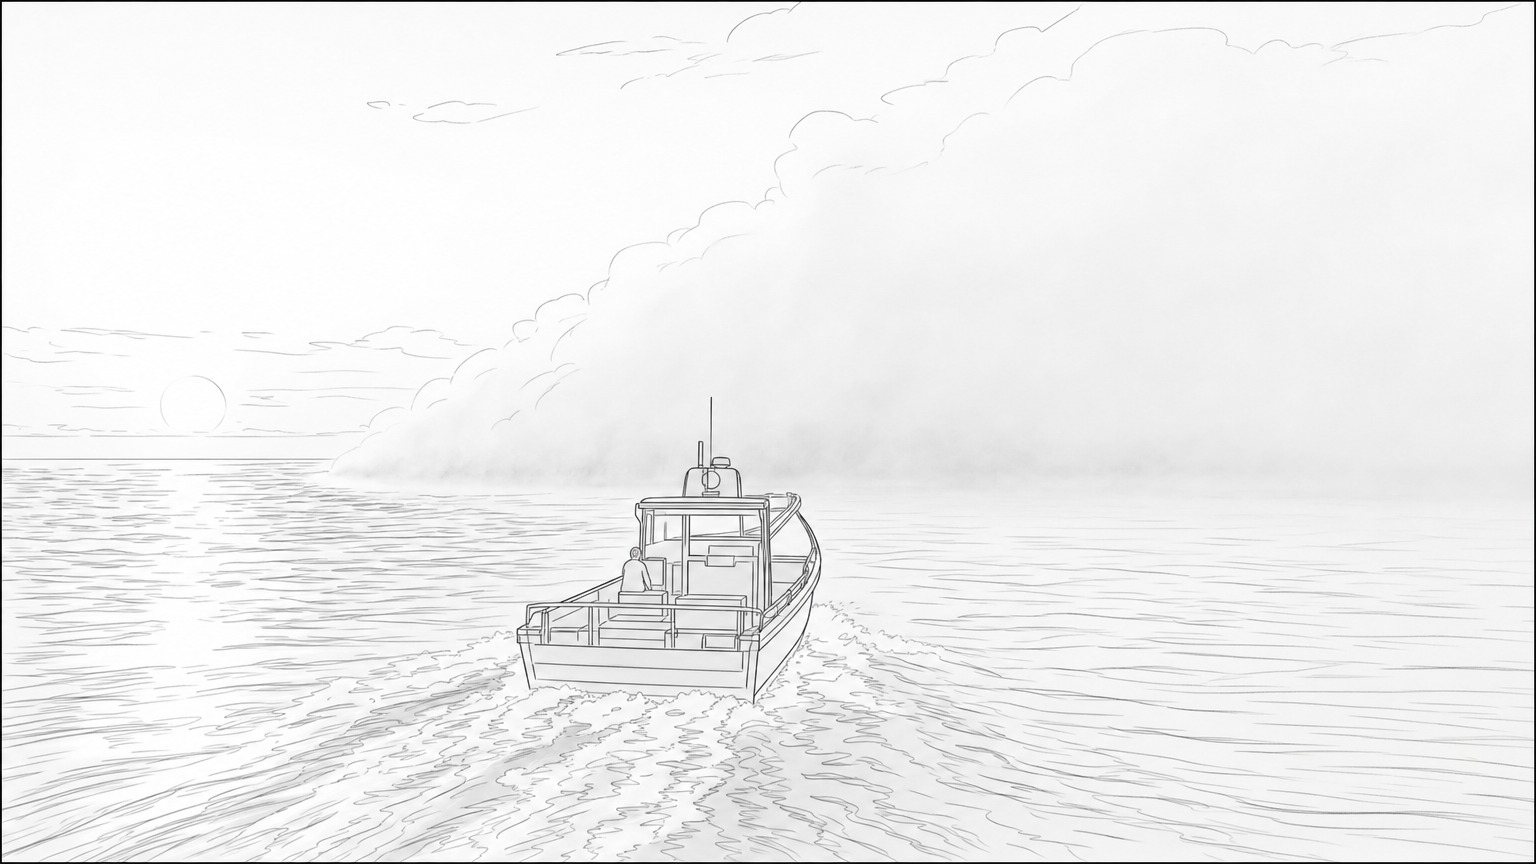
E2E6 피드백 항목2 — 샷별 마커 레이어: PIL 합성(현행) vs nb2 i2i(실험)

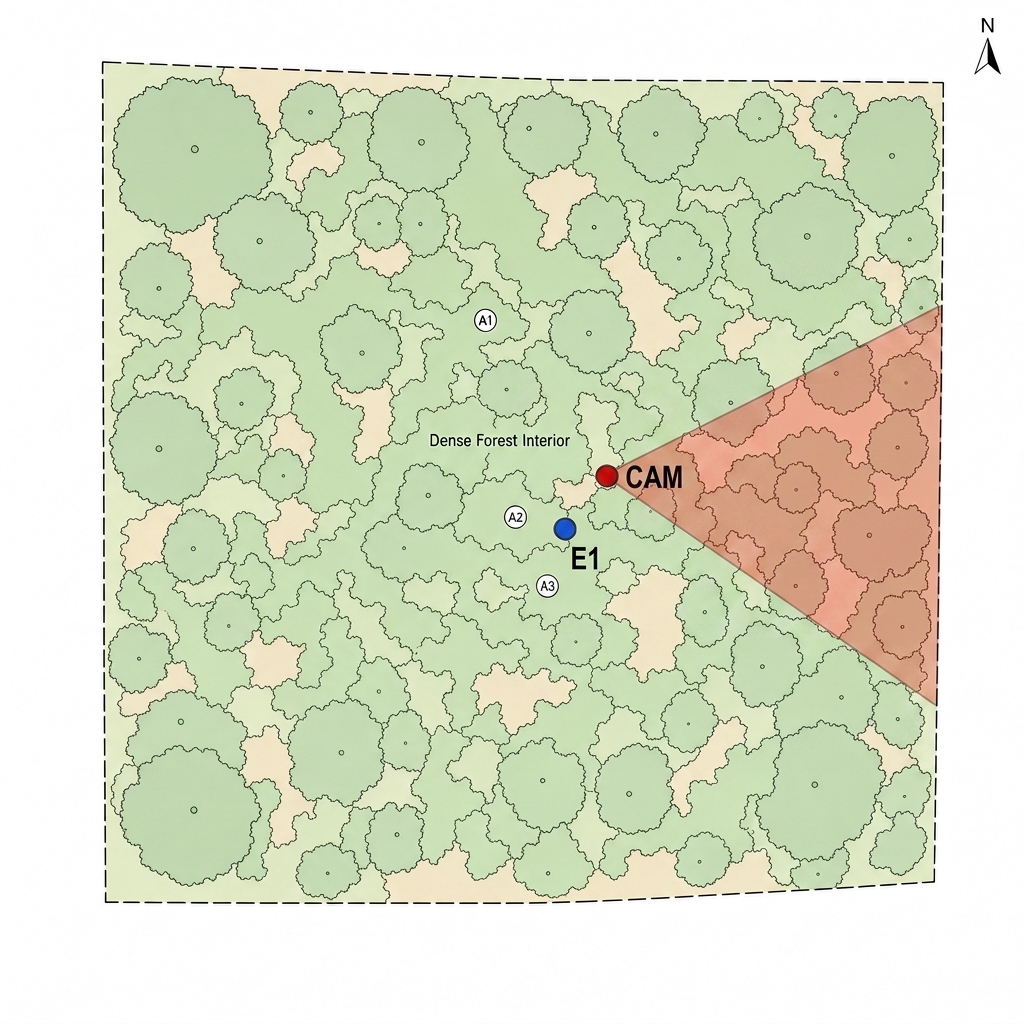
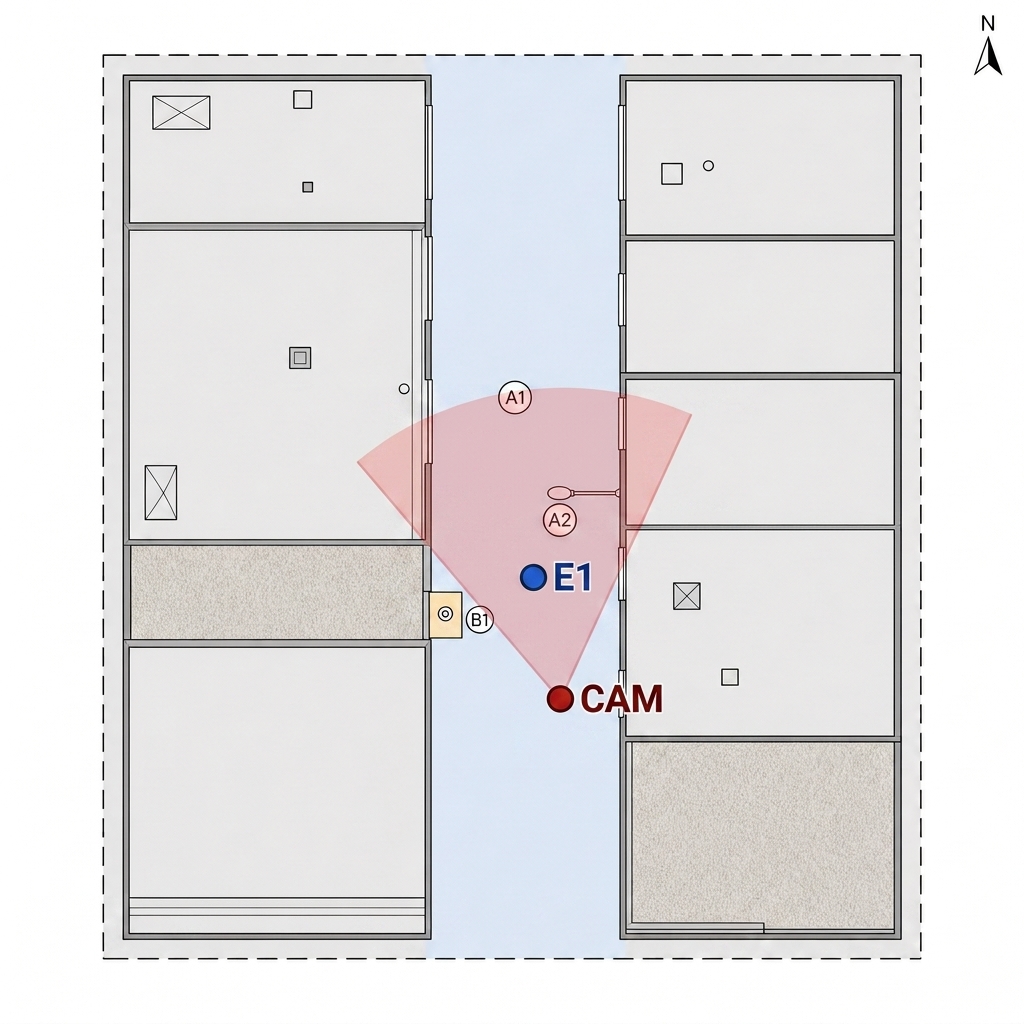
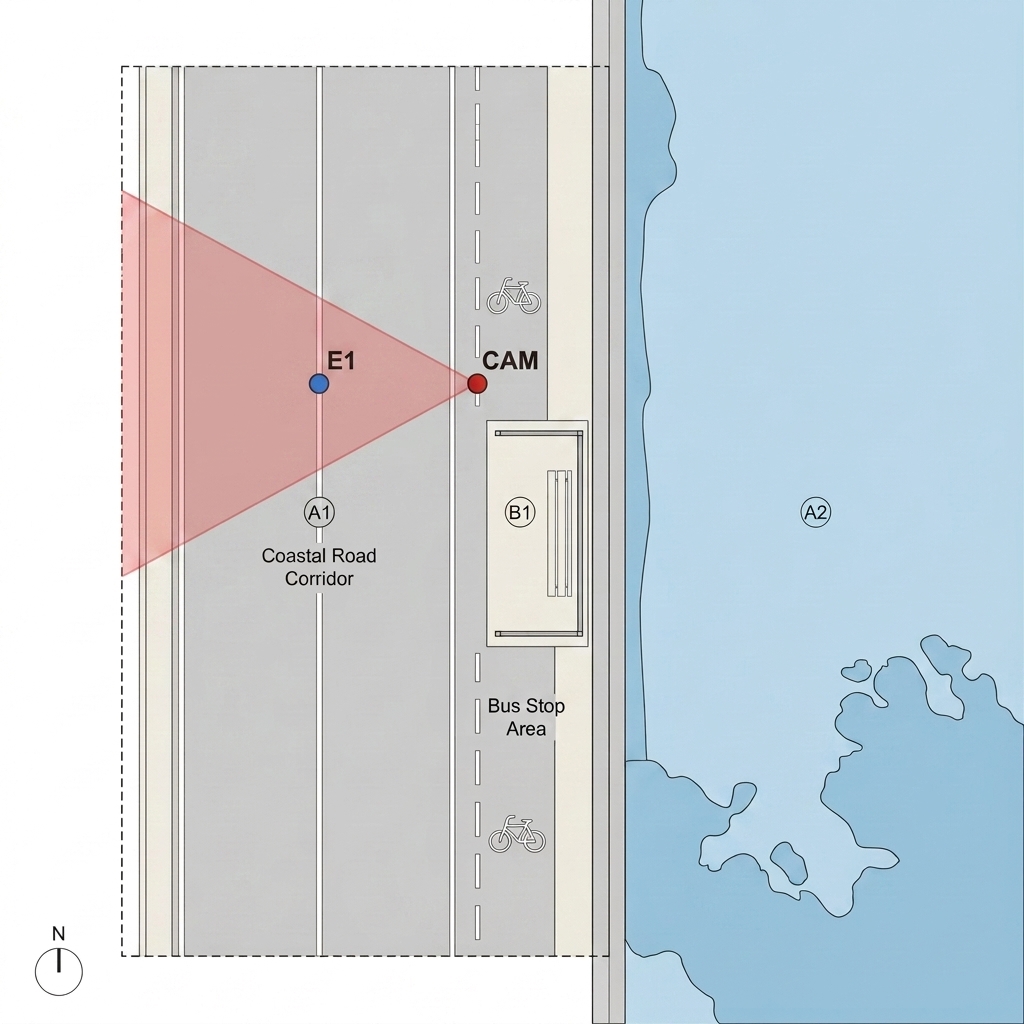
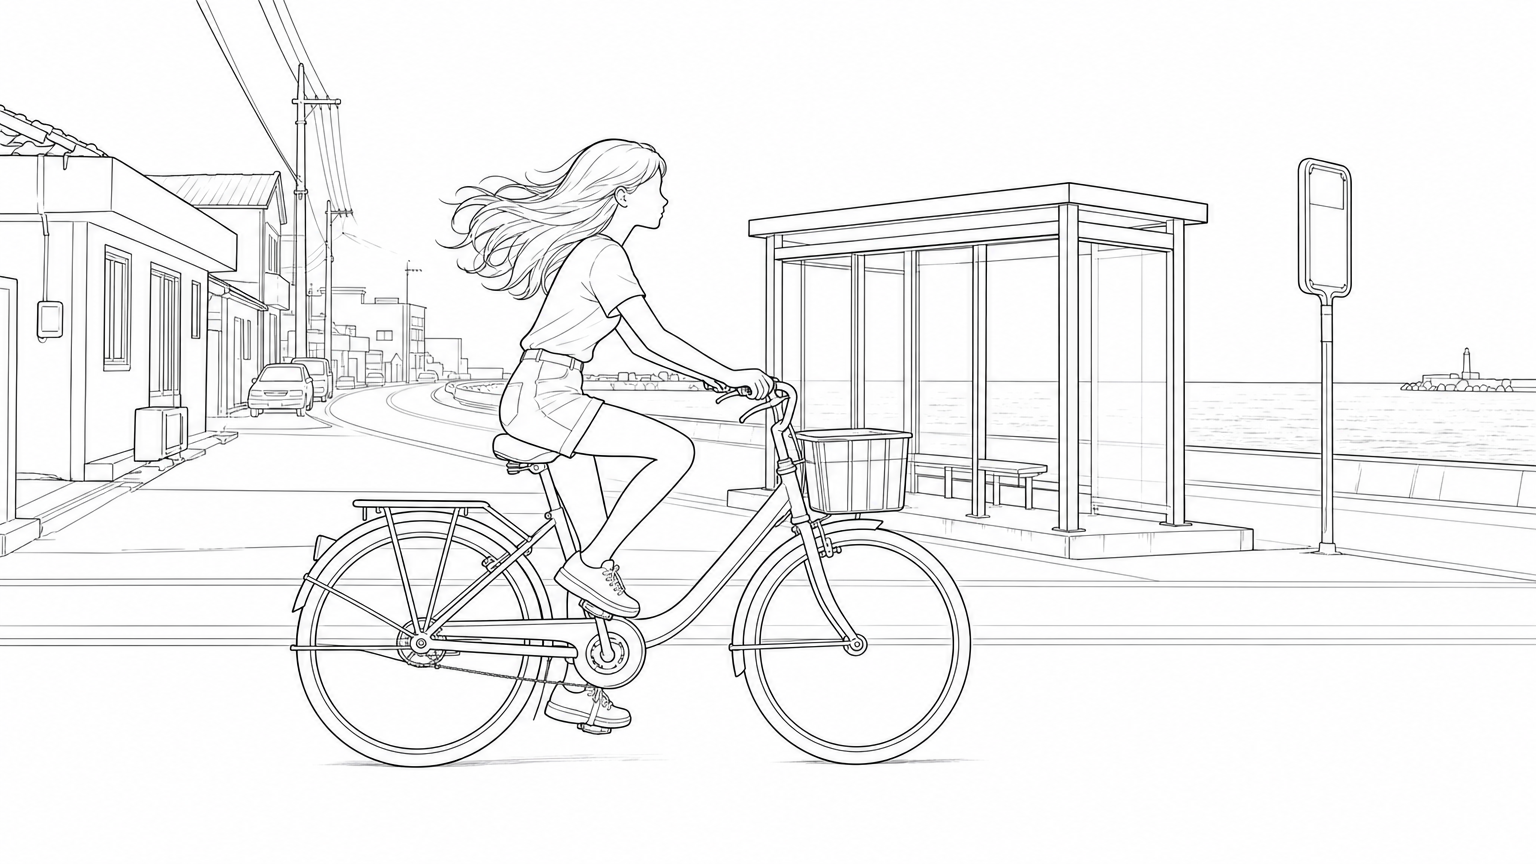
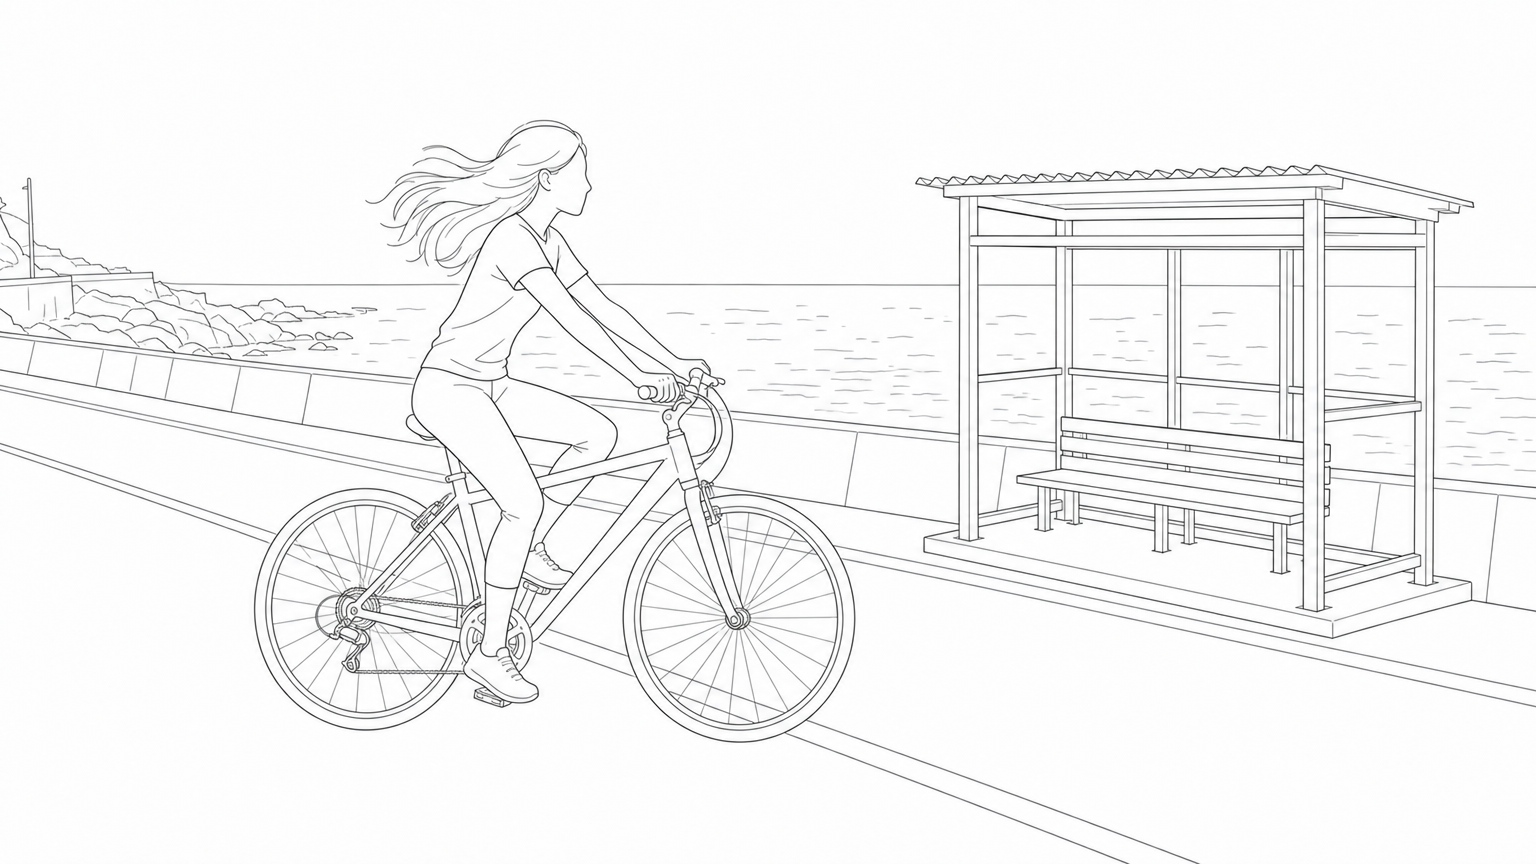
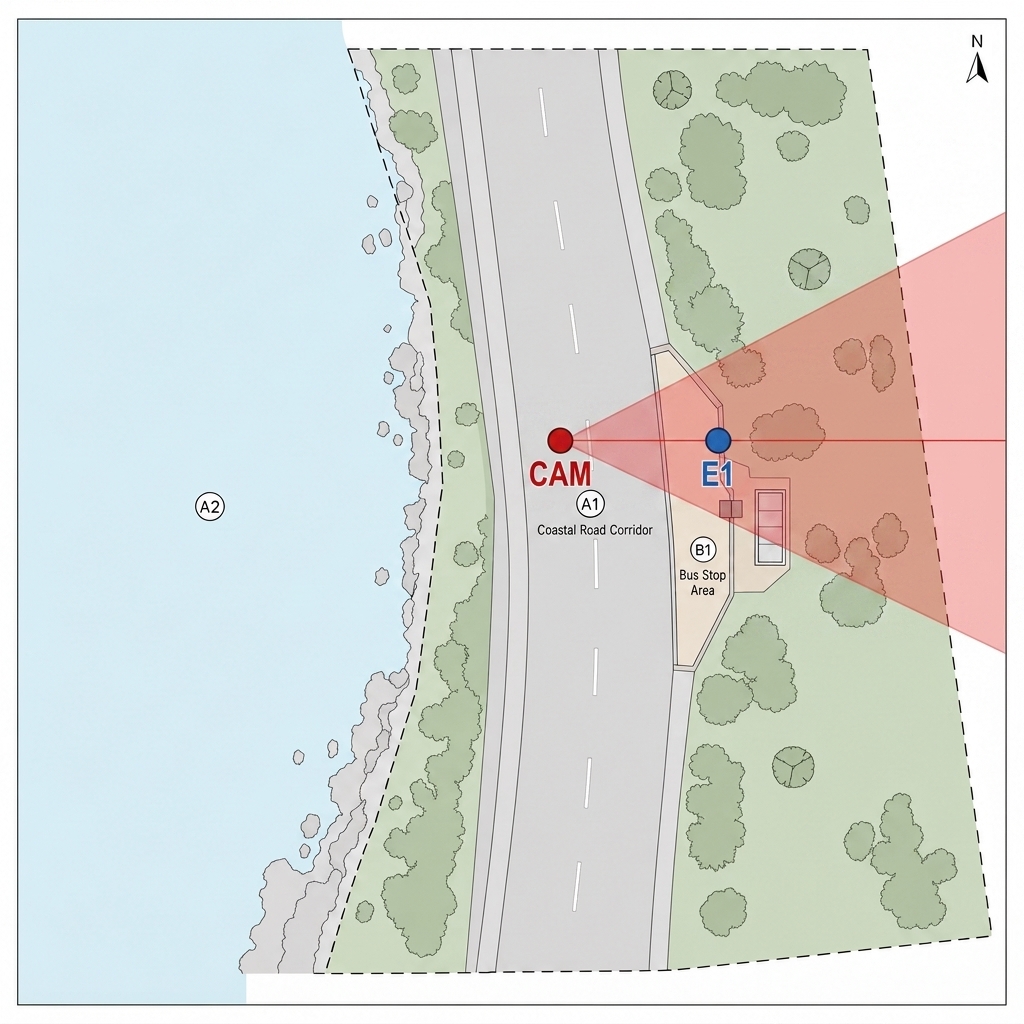
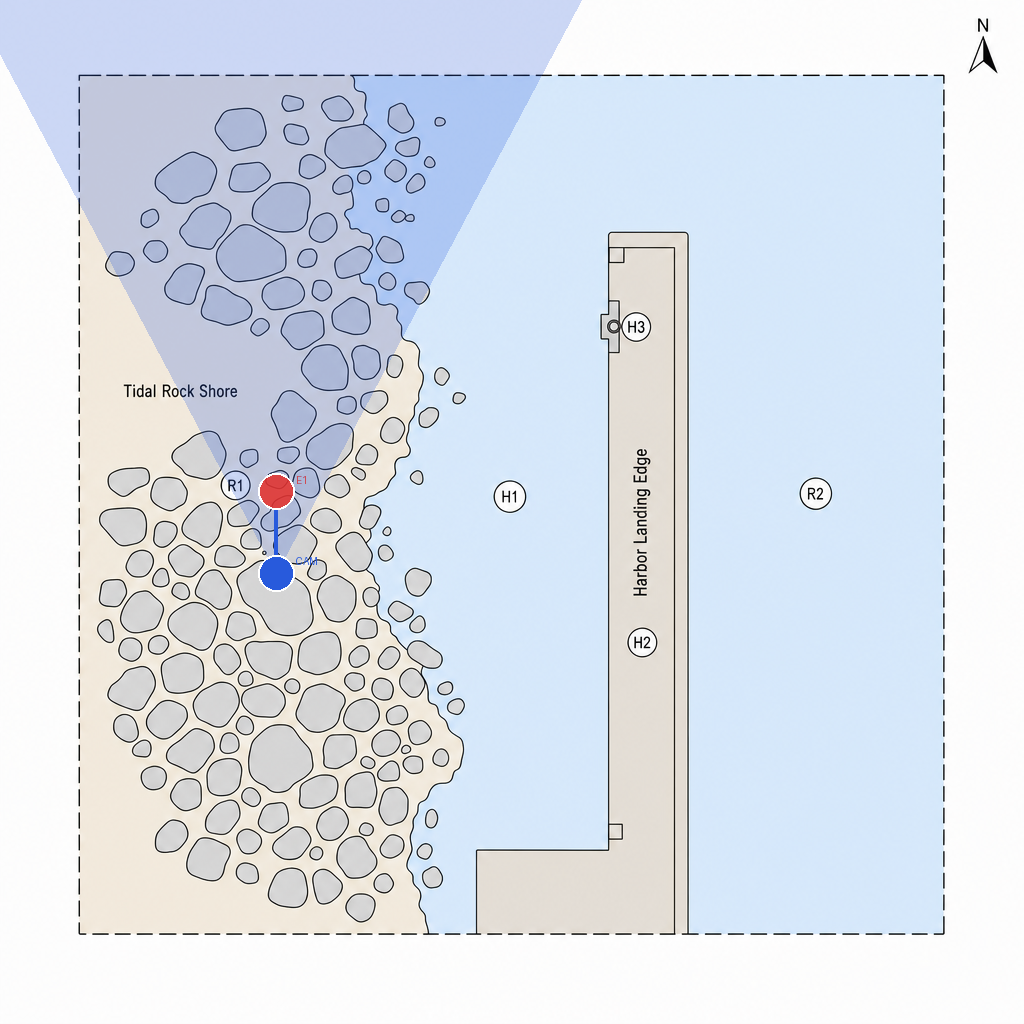
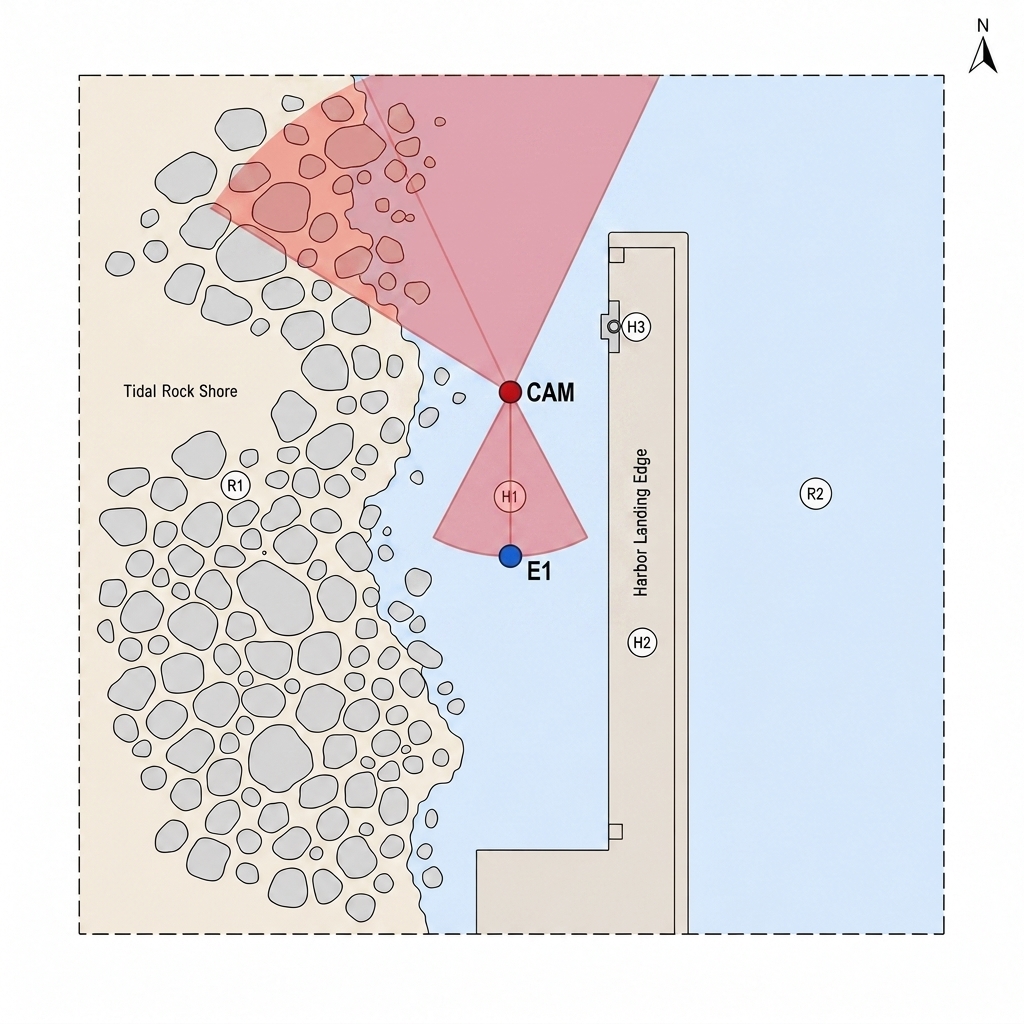
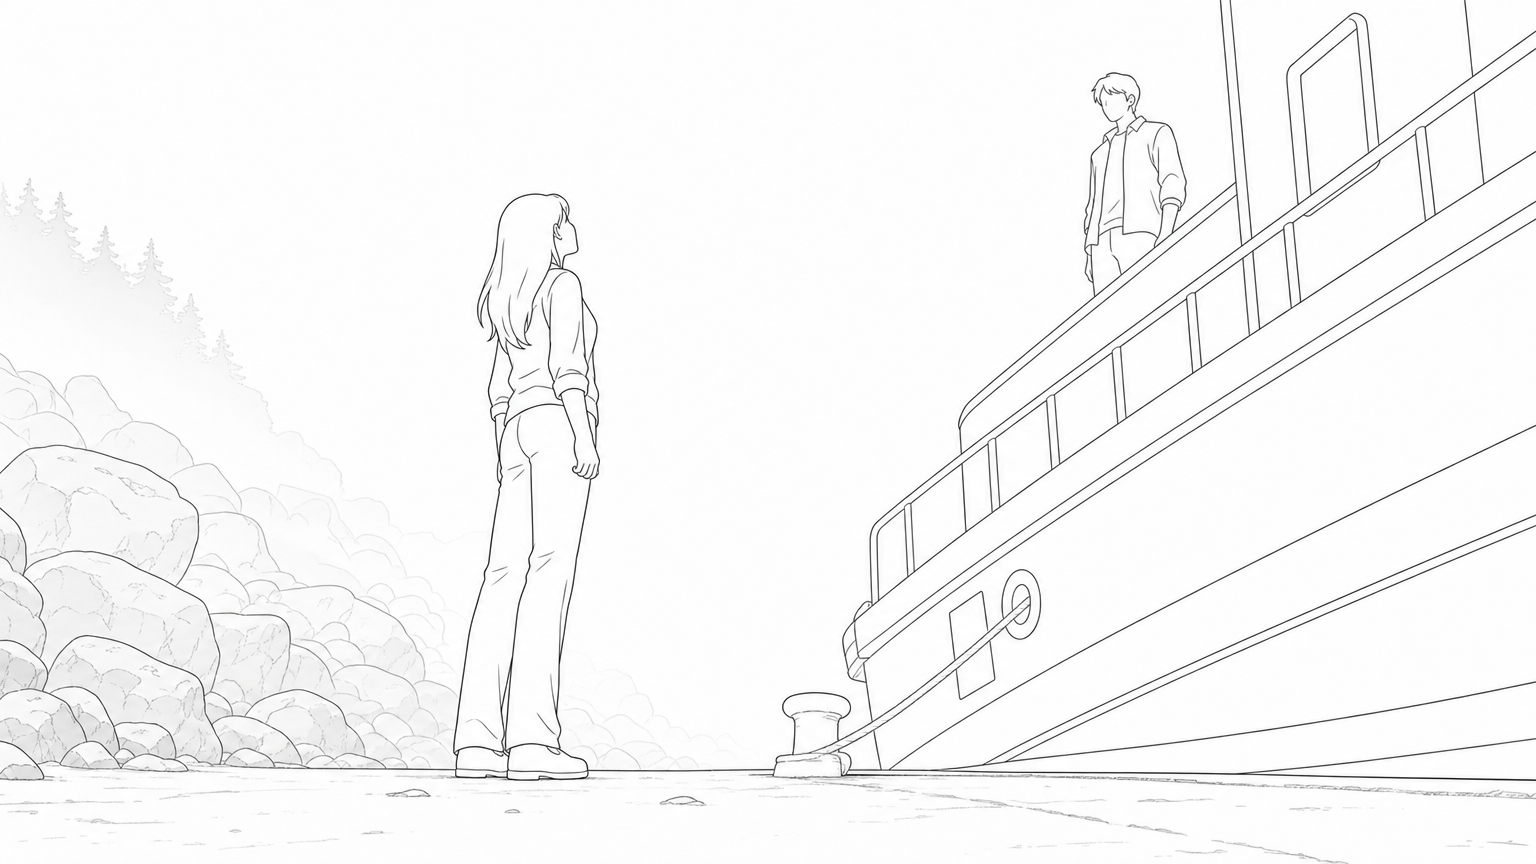
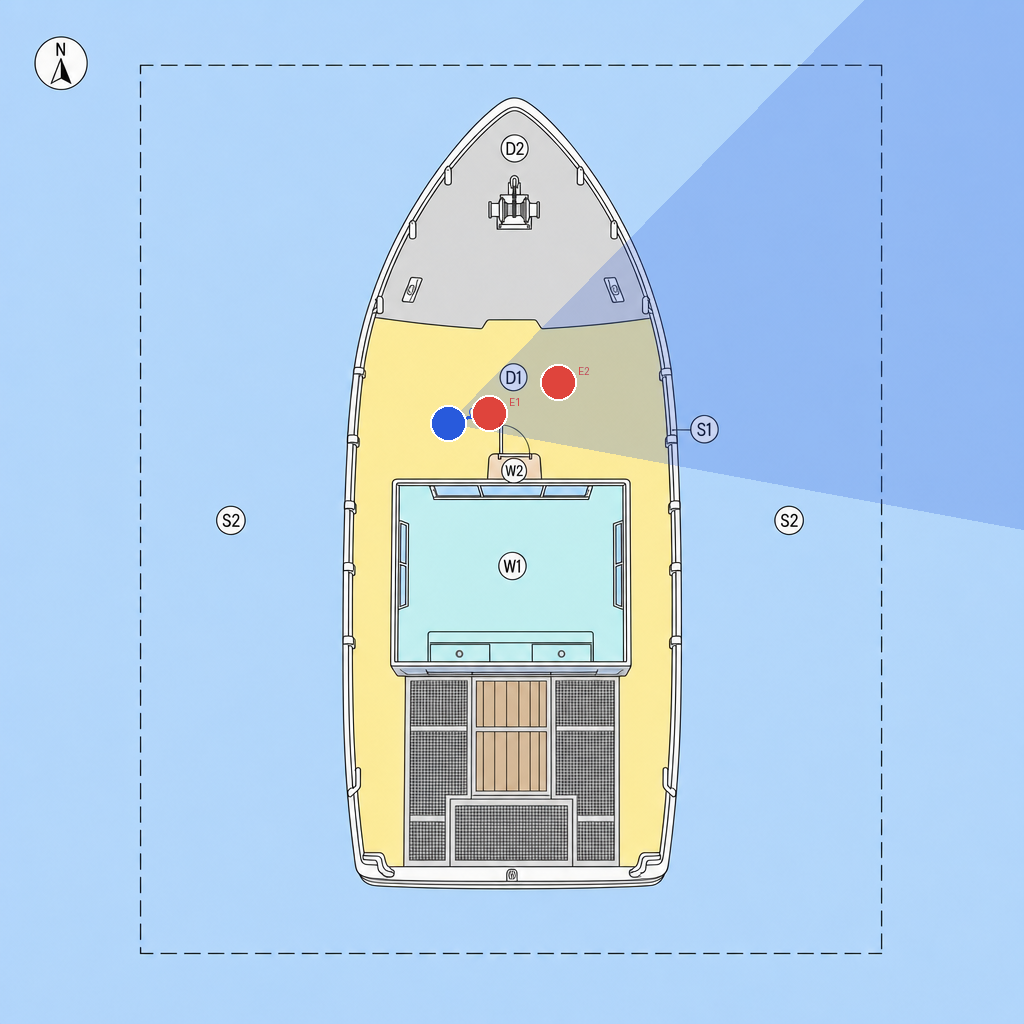
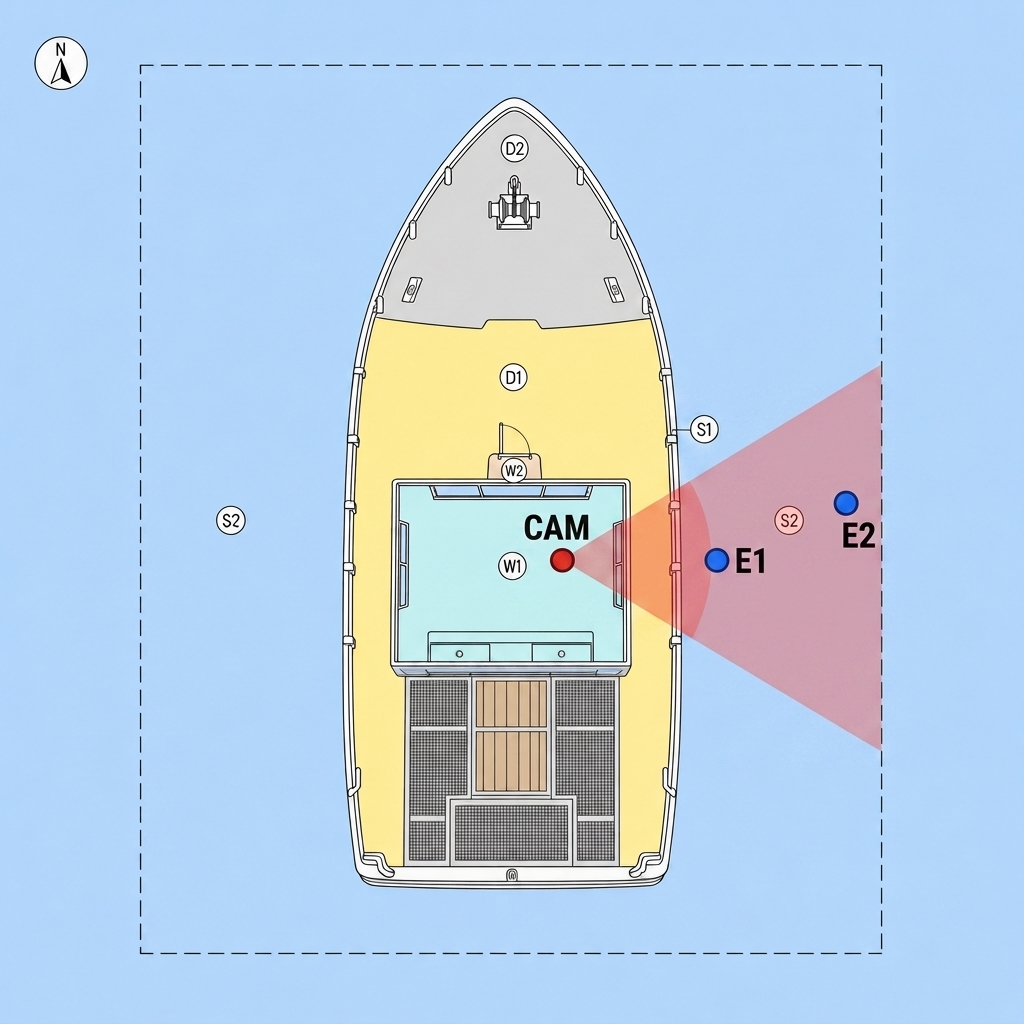
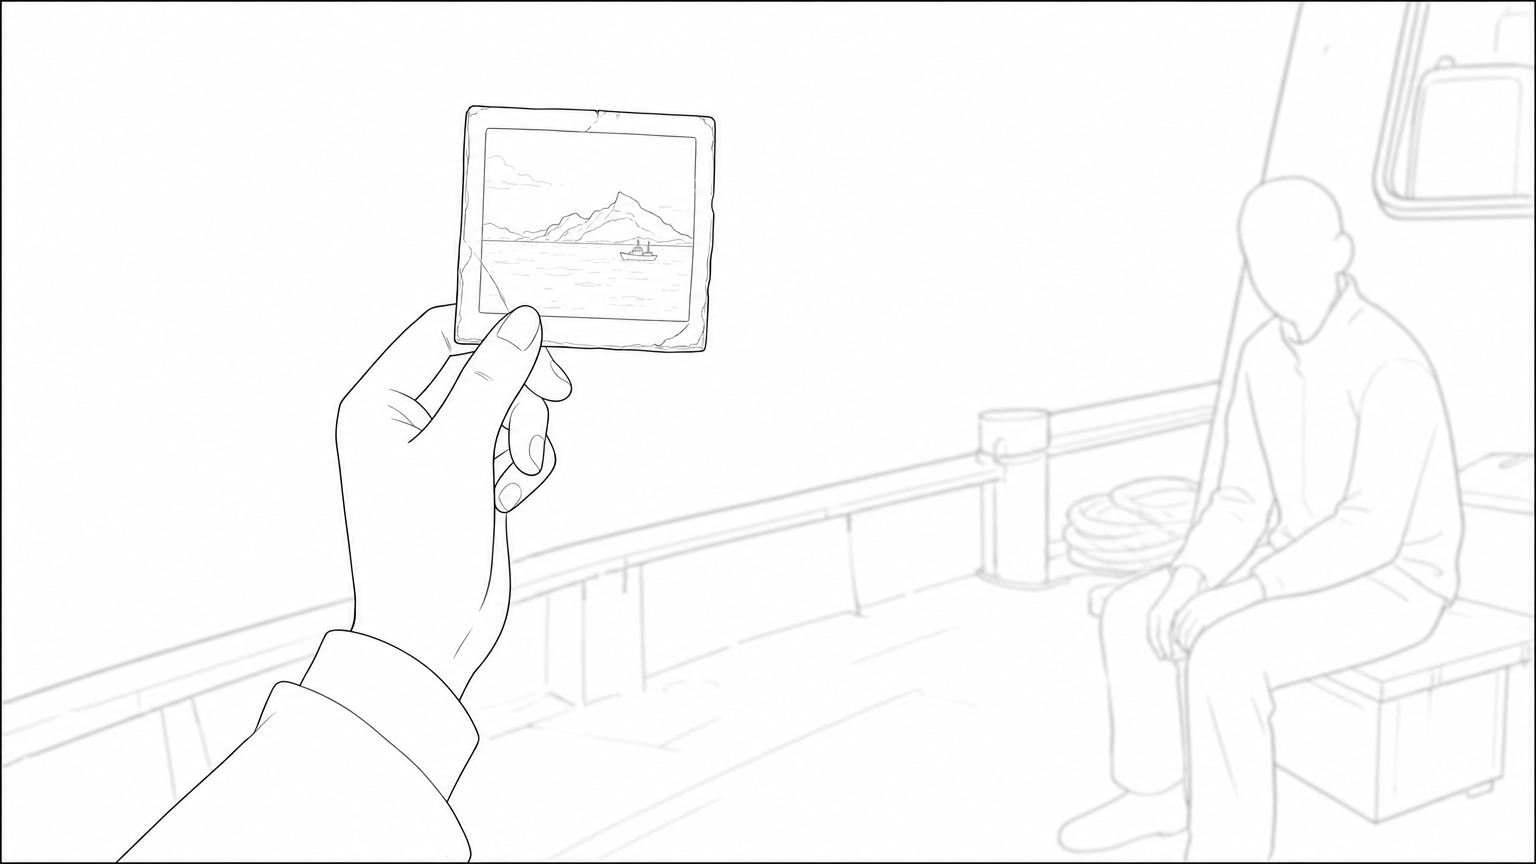
변인 격리: 스케치 프롬프트는 현행 저장본 그대로, control 이미지만 교체. geometry JSON(LLM 저작+validator)=좌표 SOT — nb2 가 이 좌표를 얼마나 충실히 그렸는지가 1차 판단 축. 조기 실측(S10sh3): nb2 가 CAM 위치·응시 방향을 좌표와 다르게 그림(위쪽 응시→오른쪽) — 전 샷 확인 필요.

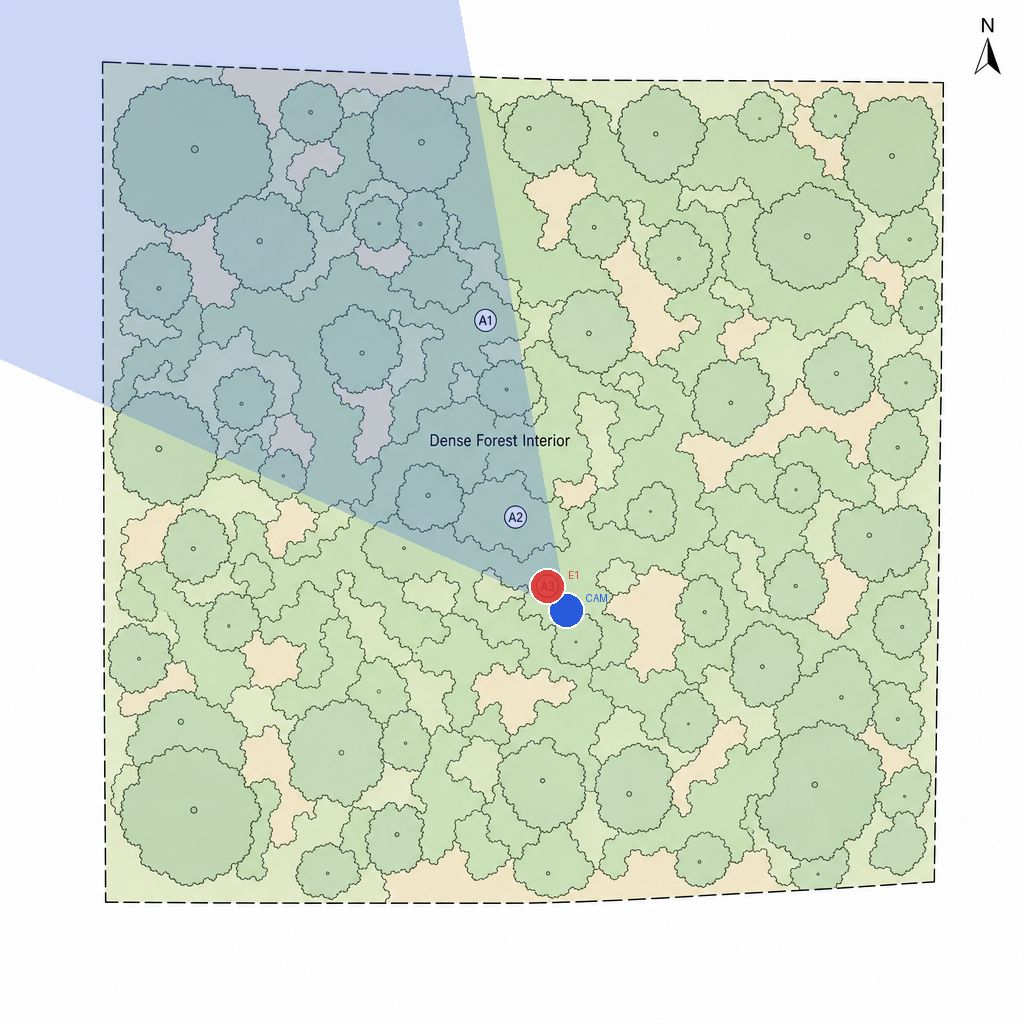
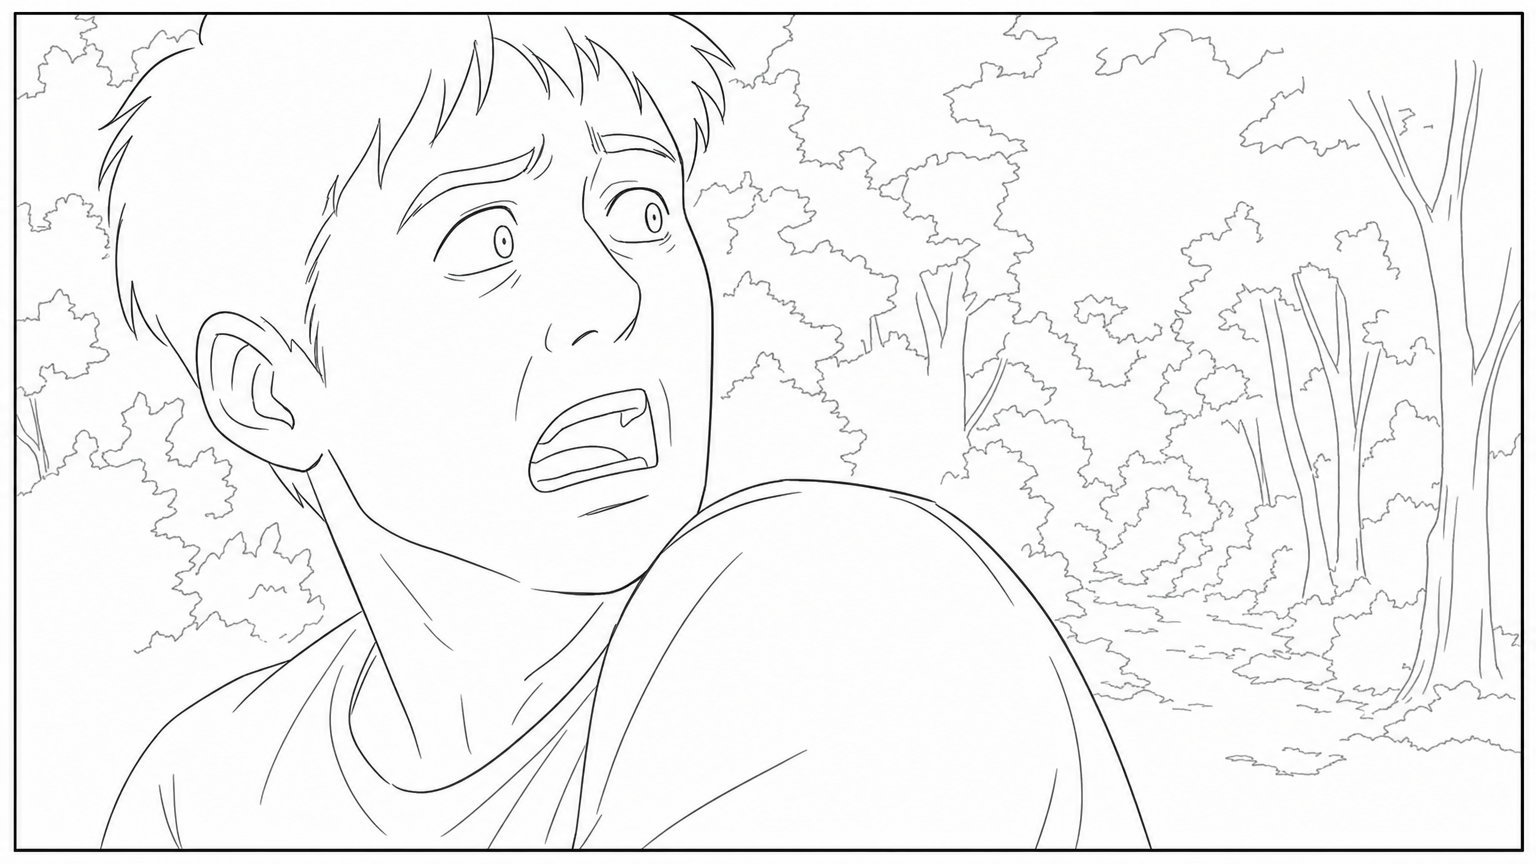
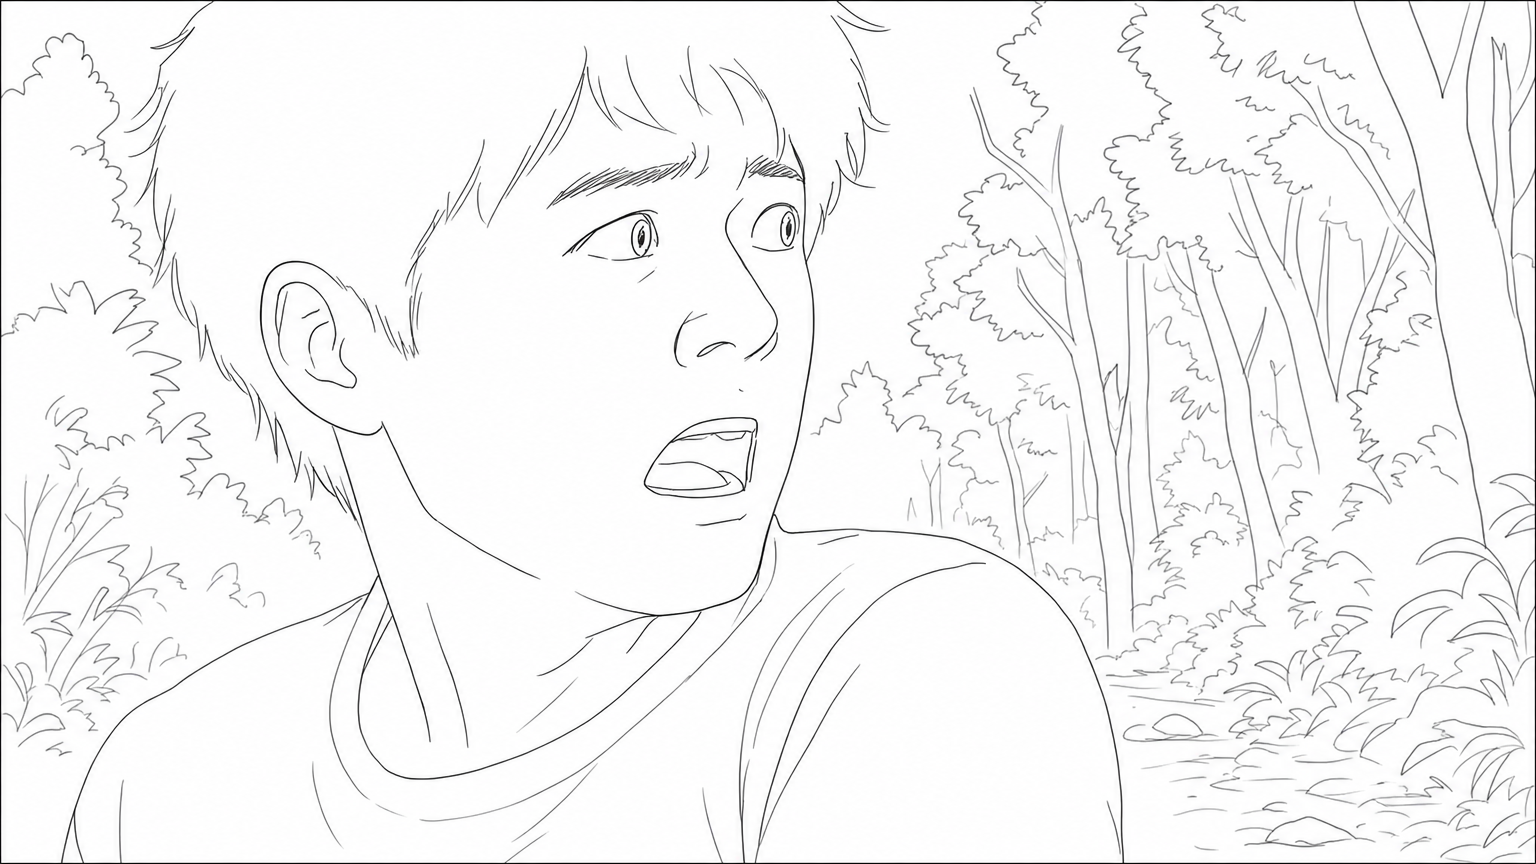
S1sh3 map_marker · bg_mountain_forest

geometry SOT: CAM=(0.55,0.60)→look(0.54,0.57) | 엔티티: E1(0.54,0.57)
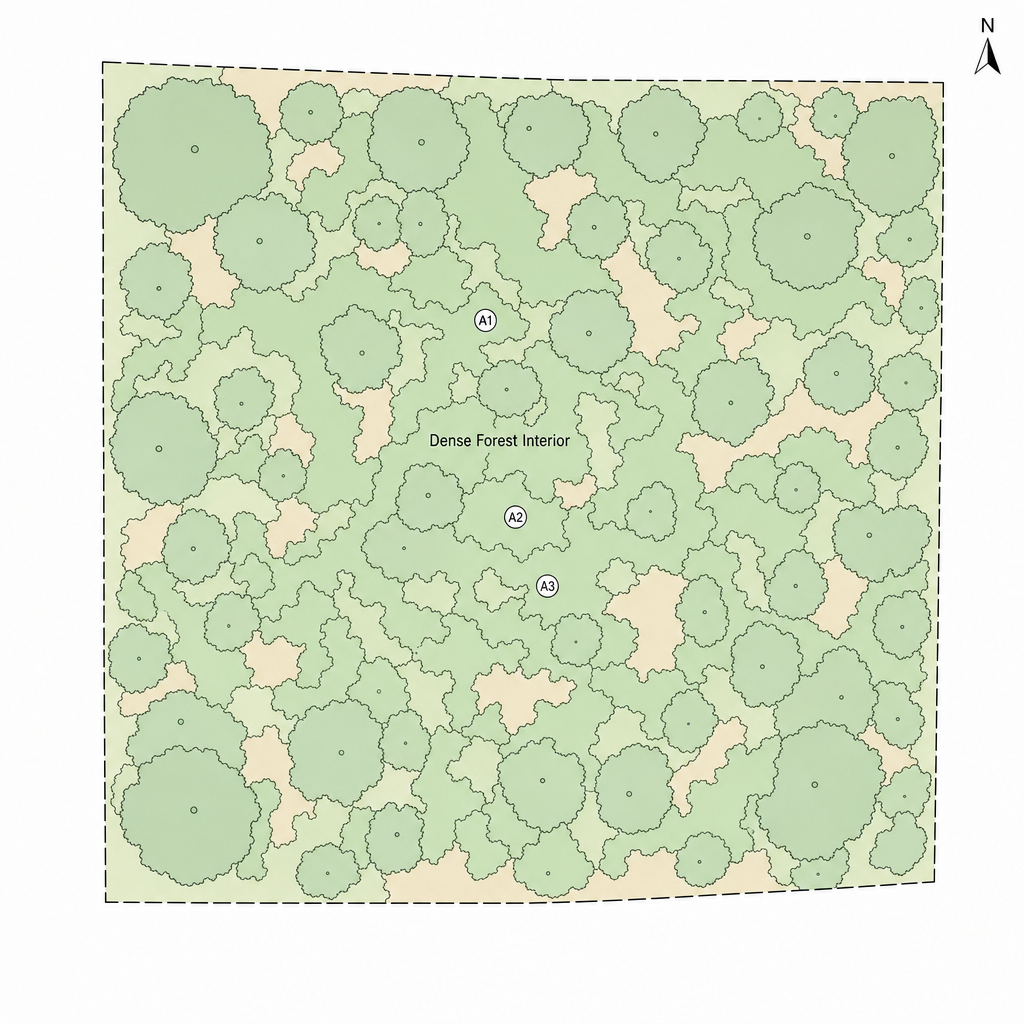
BASE 맵
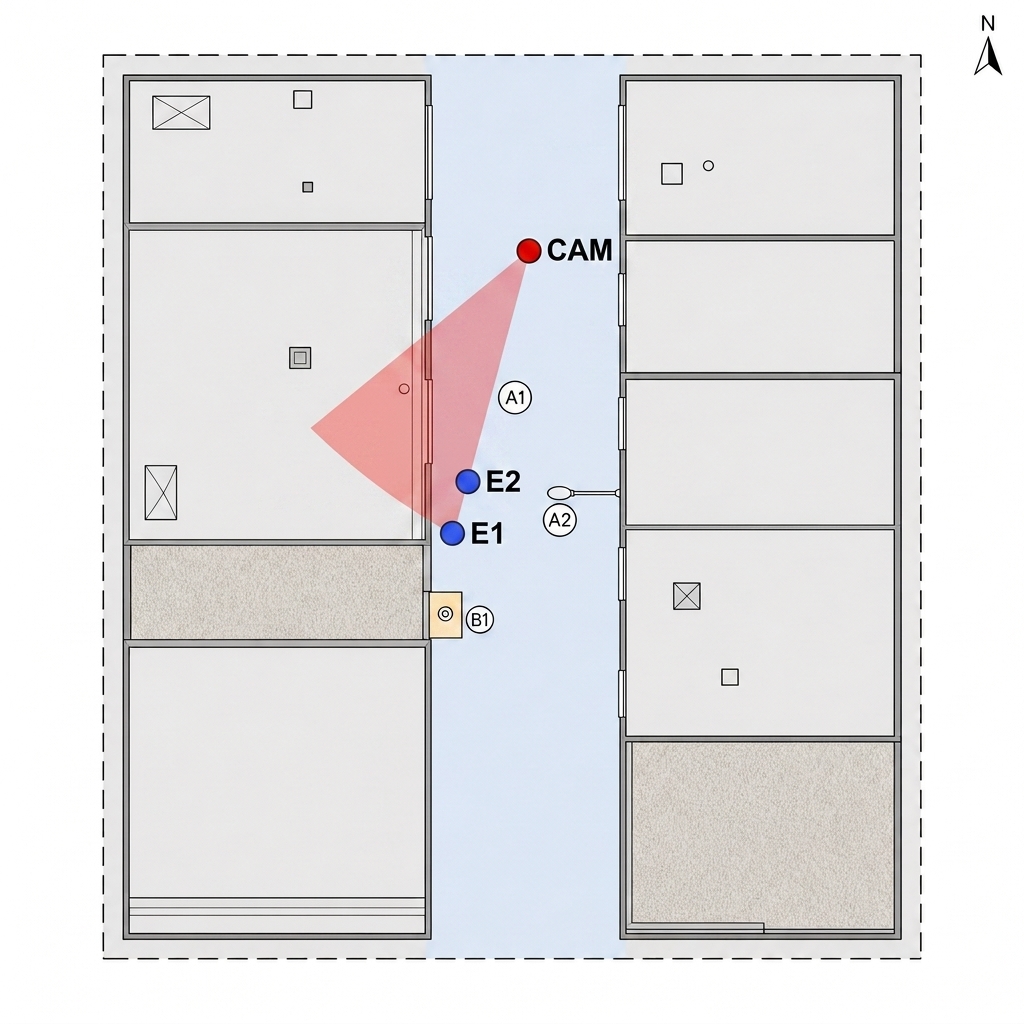
PIL control (현행)
nb2 control (실험)
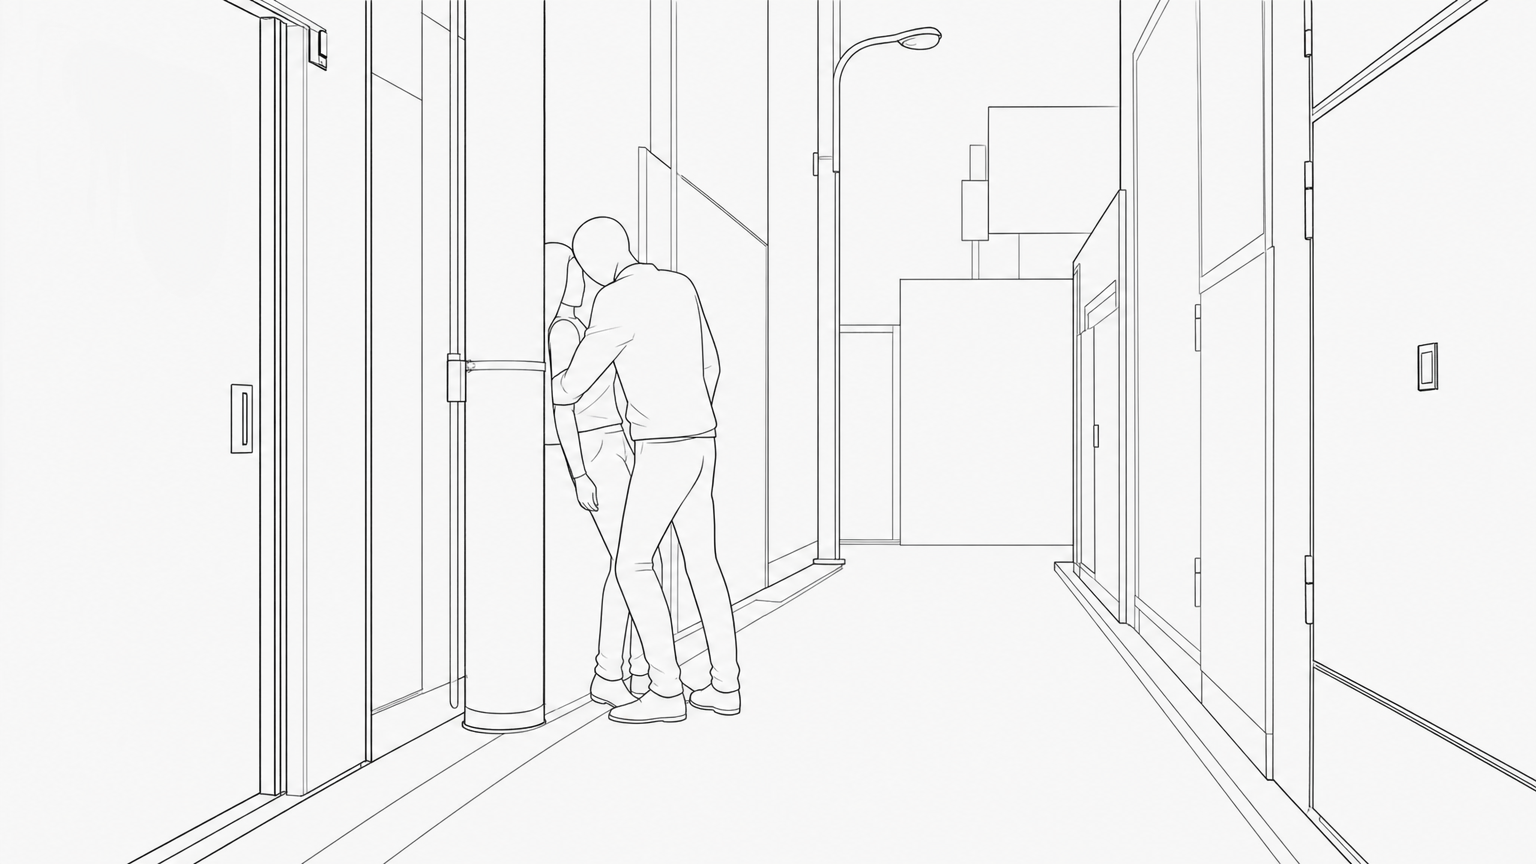
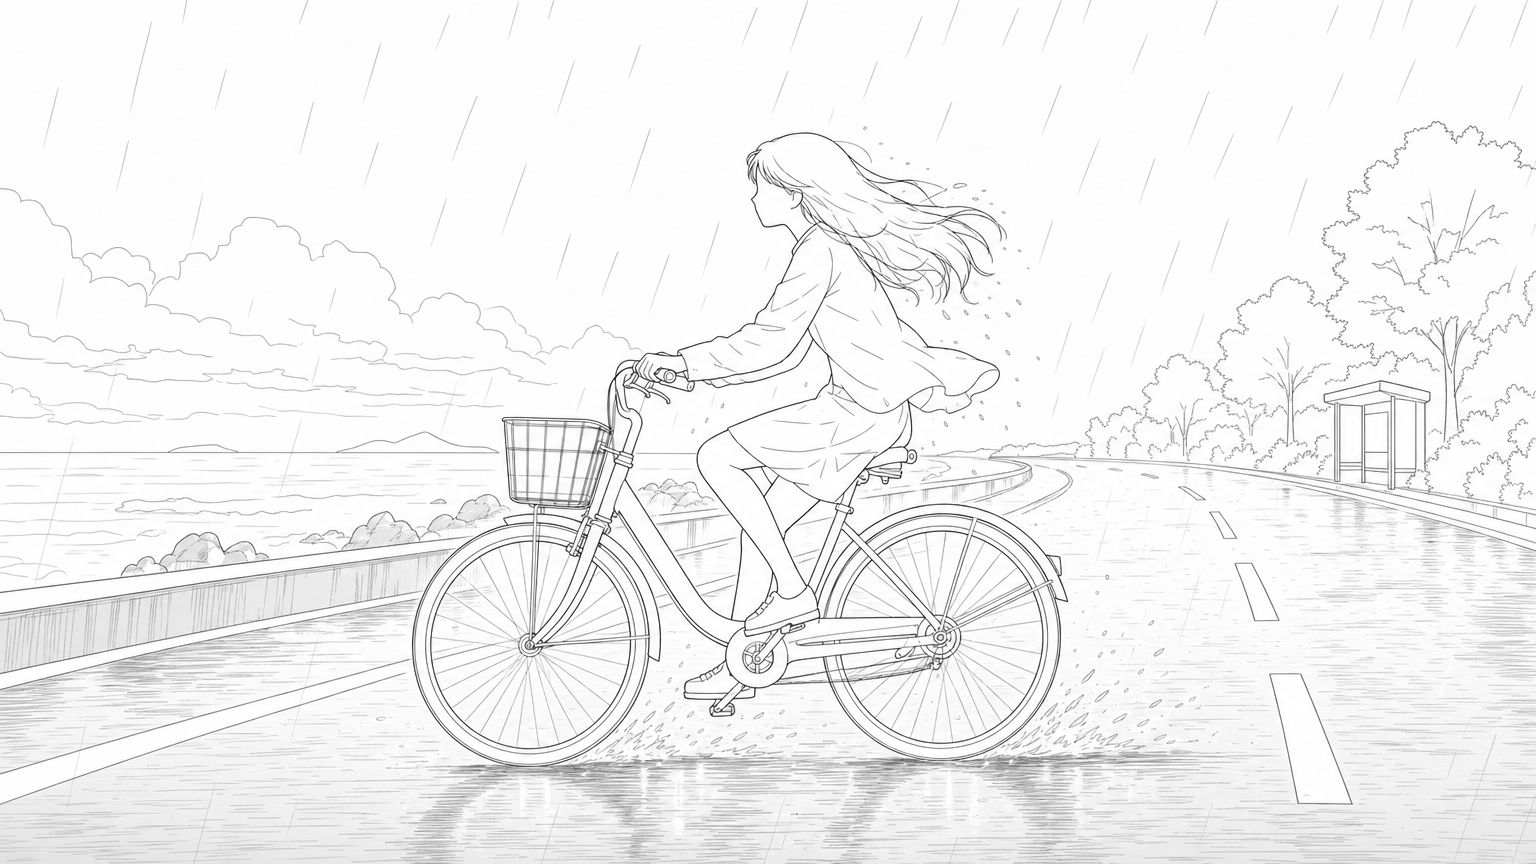
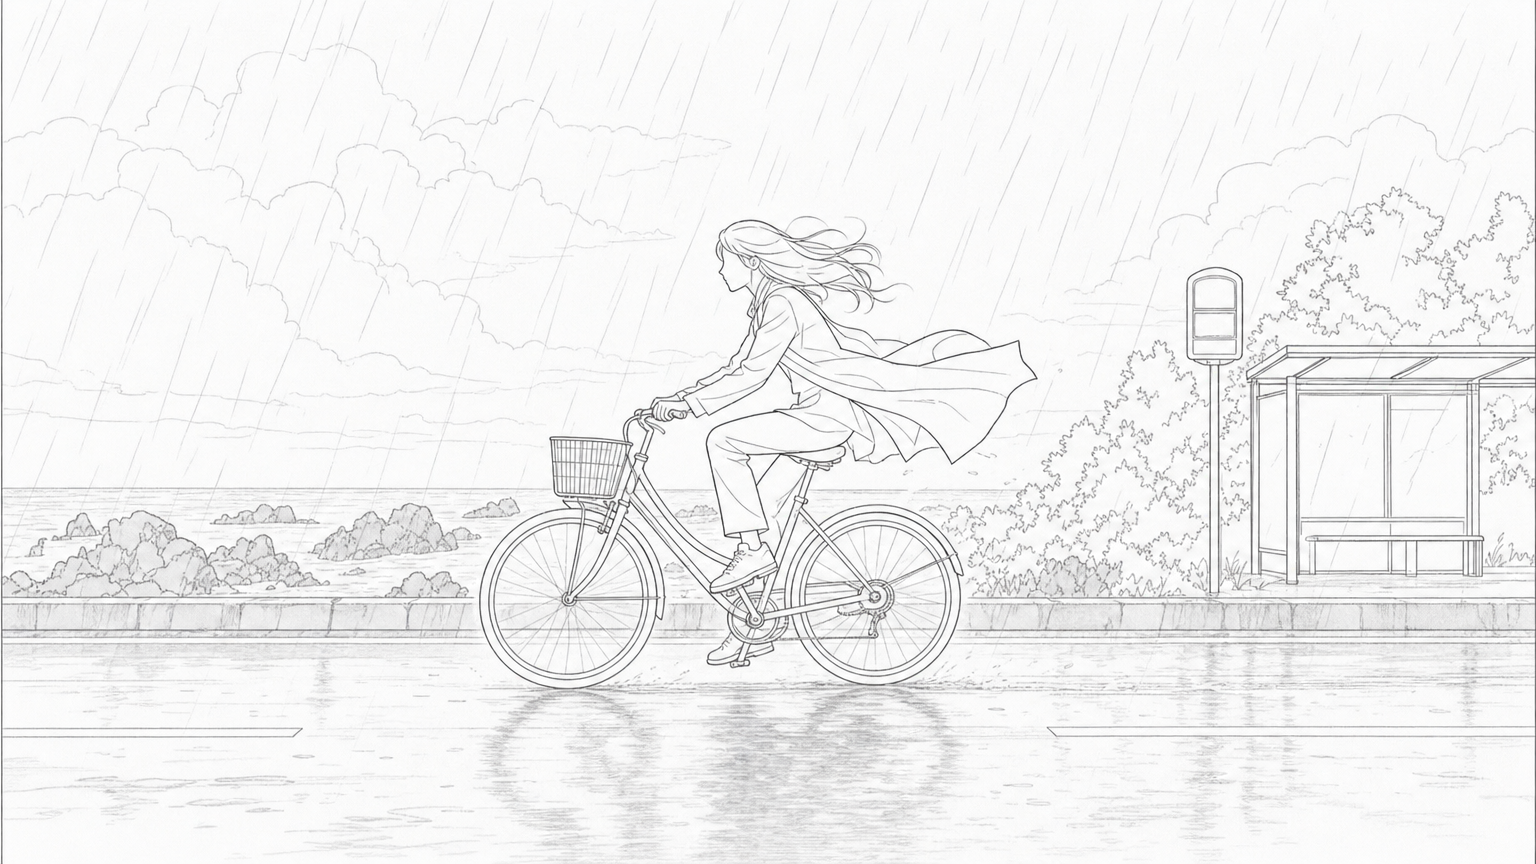
스케치 — PIL 기반 (현행)
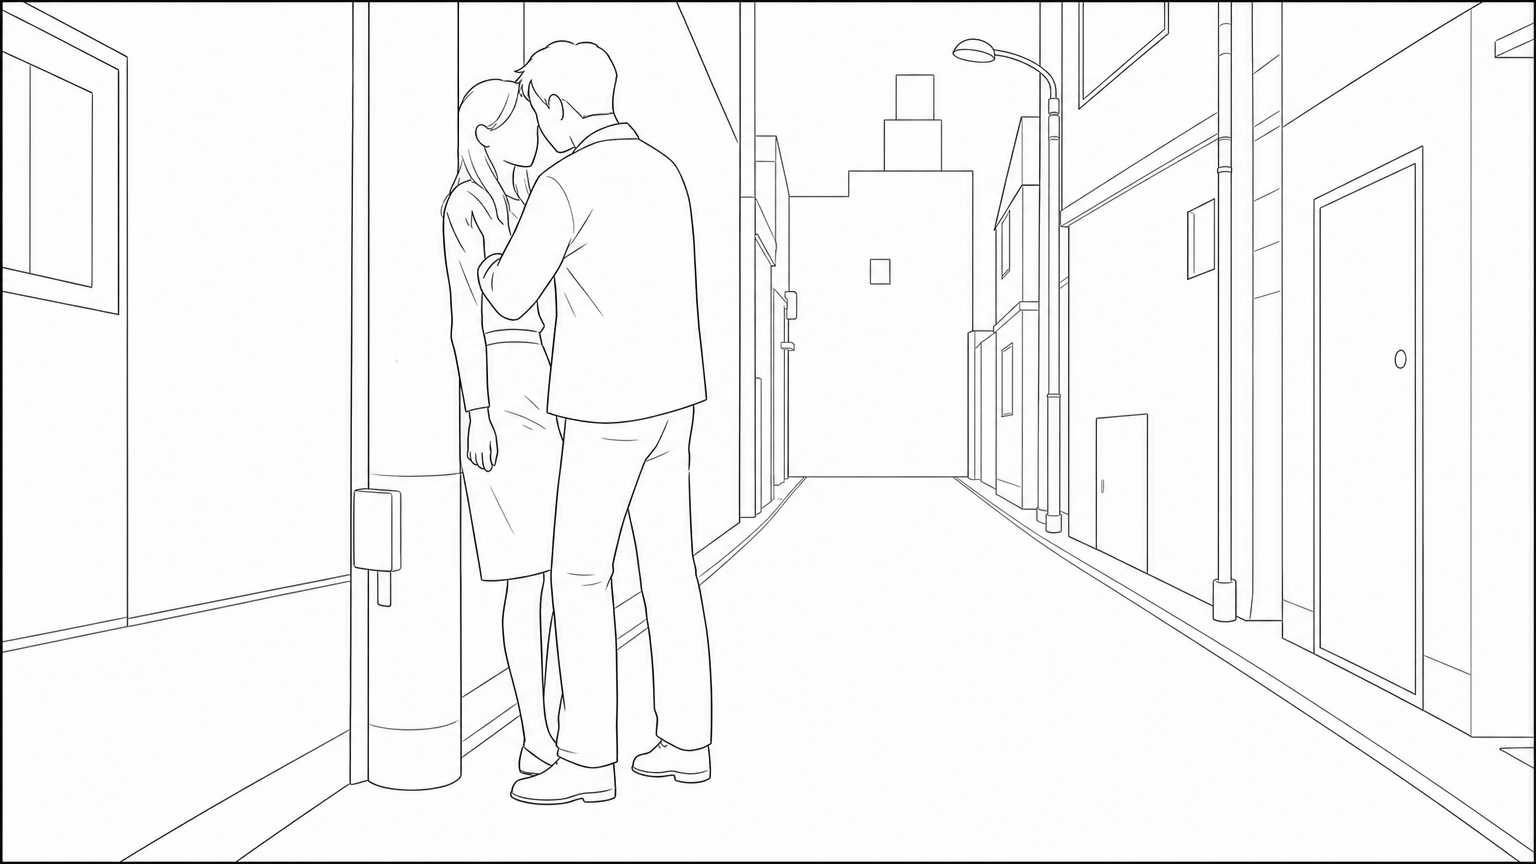
스케치 — nb2 기반 (실험)

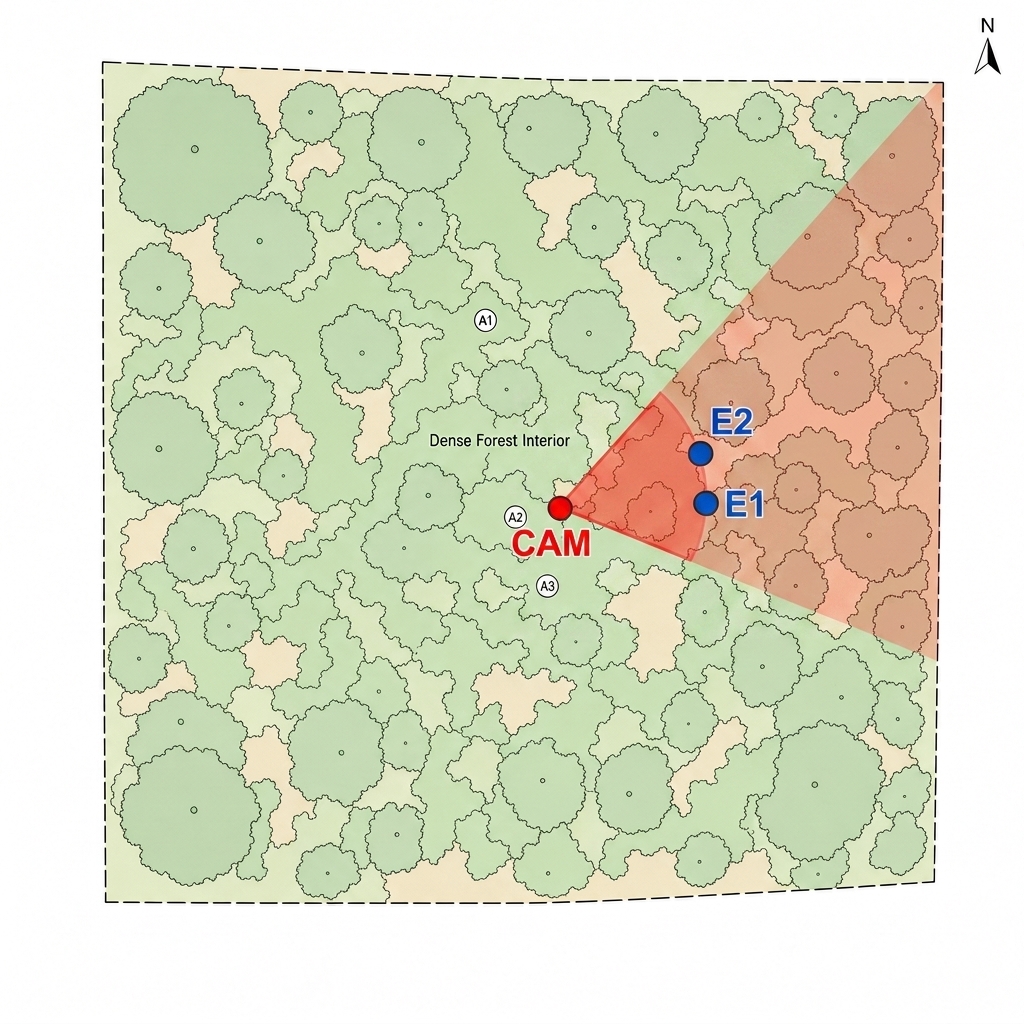
S1sh5 map_marker · bg_mountain_forest

geometry SOT: CAM=(0.49,0.62)→look(0.54,0.57) | 엔티티: E1(0.54,0.57), E2(0.53,0.58)
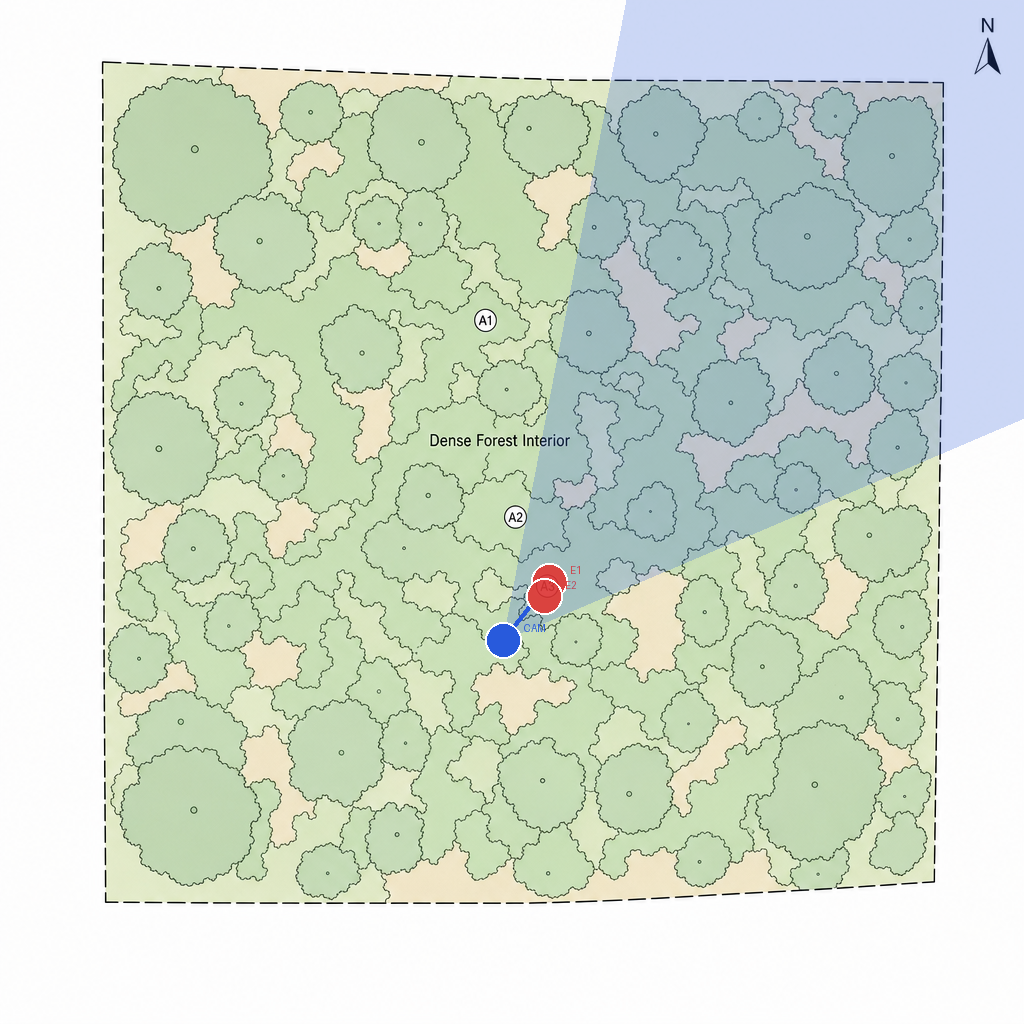
BASE 맵
PIL control (현행)
nb2 control (실험)
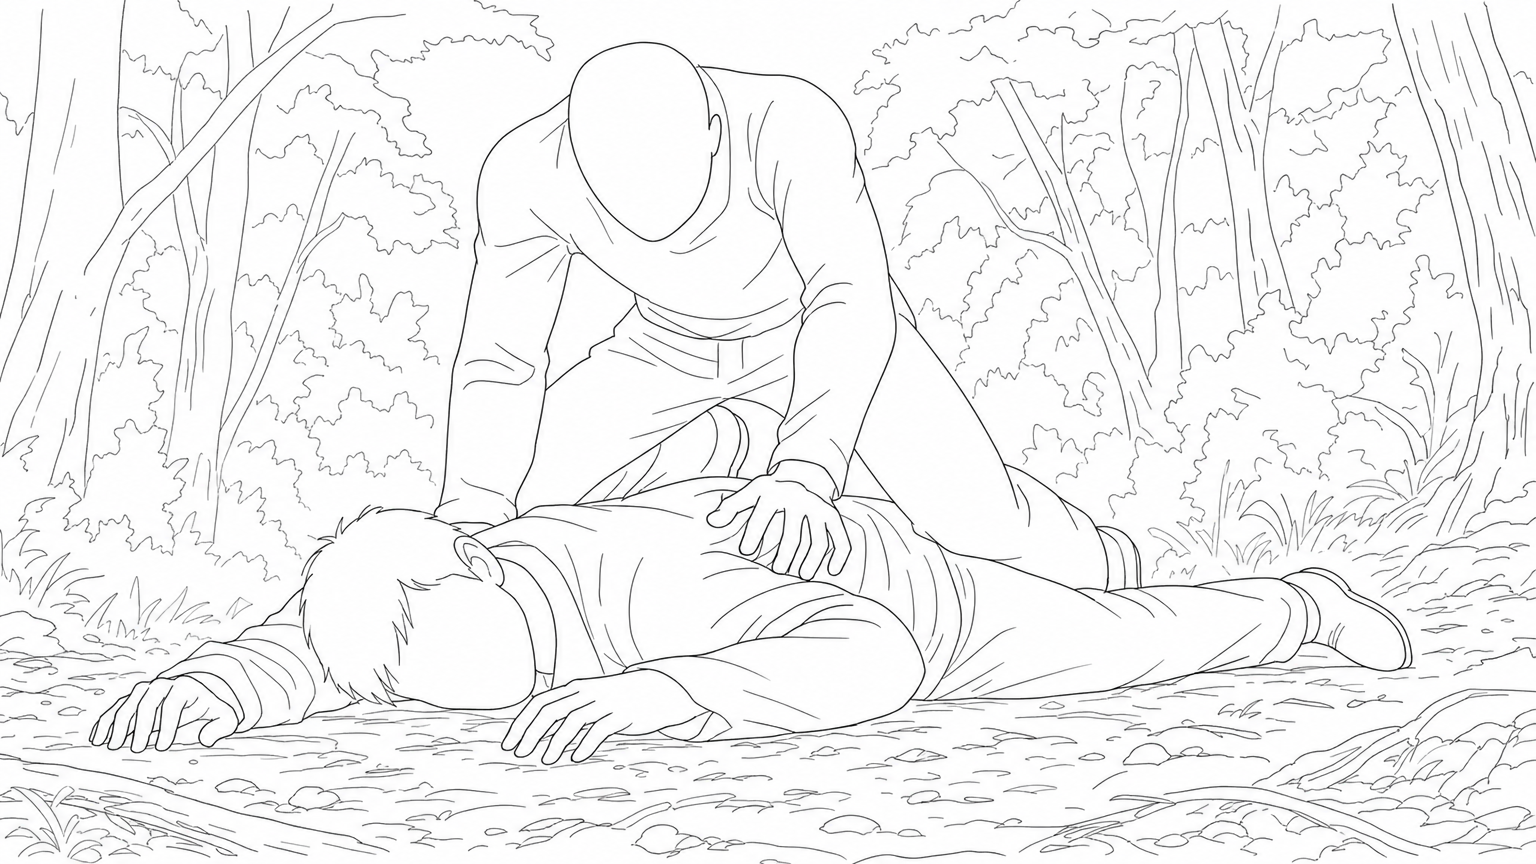
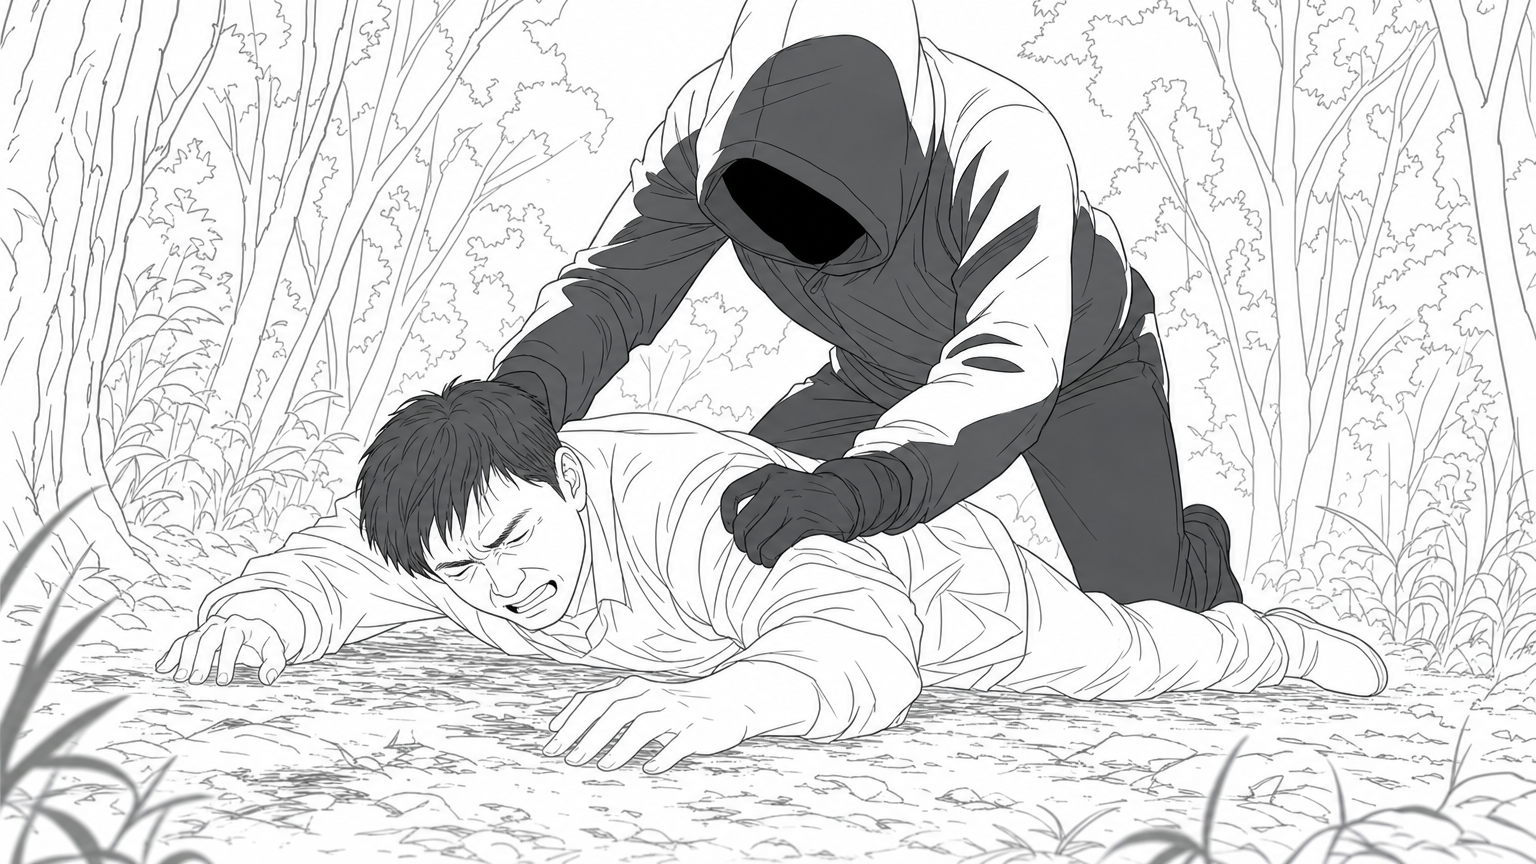
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S2sh1 map_marker · bg_urban_alley

geometry SOT: CAM=(0.55,0.78)→look(0.45,0.60) | 엔티티: E1(0.45,0.60), E2(0.47,0.64)
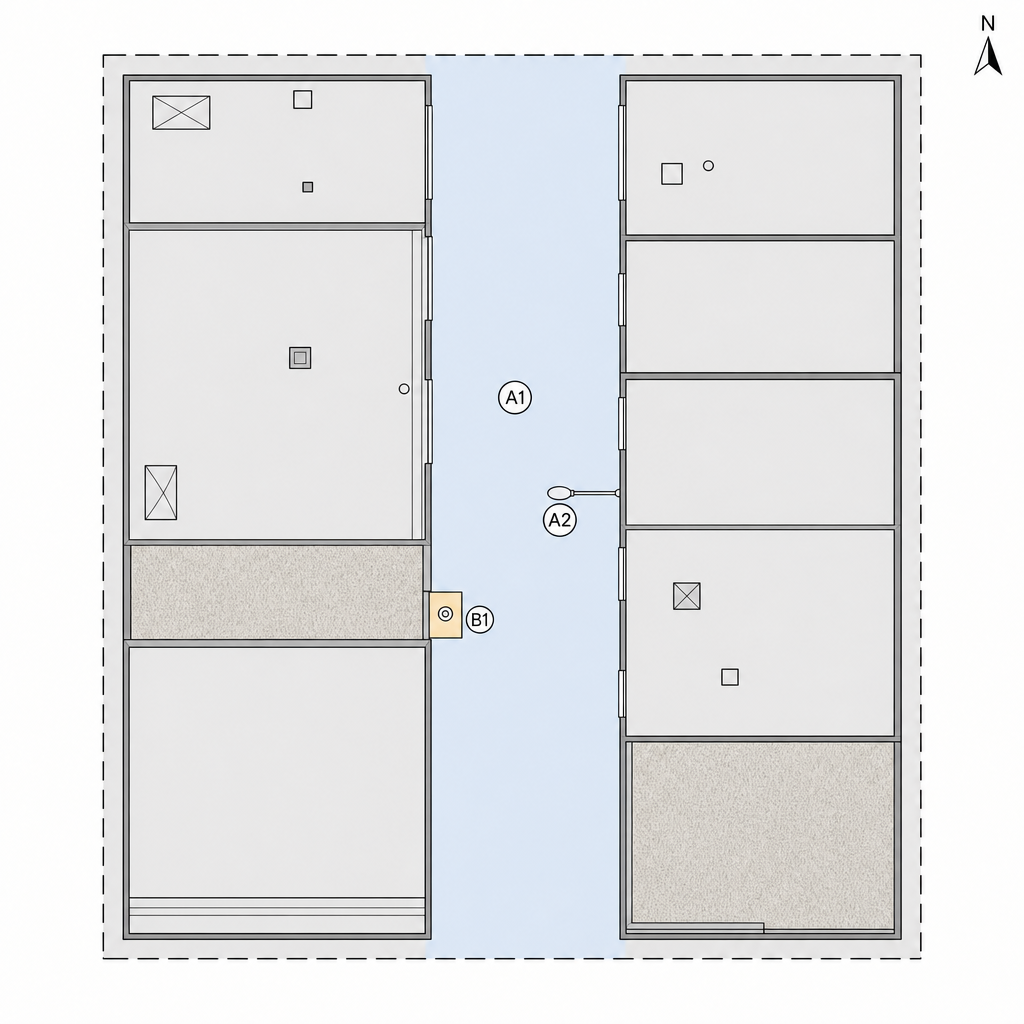
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S2sh4 map_marker · bg_urban_alley

geometry SOT: CAM=(0.48,0.63)→look(0.48,0.61) | 엔티티: E1(0.48,0.61)
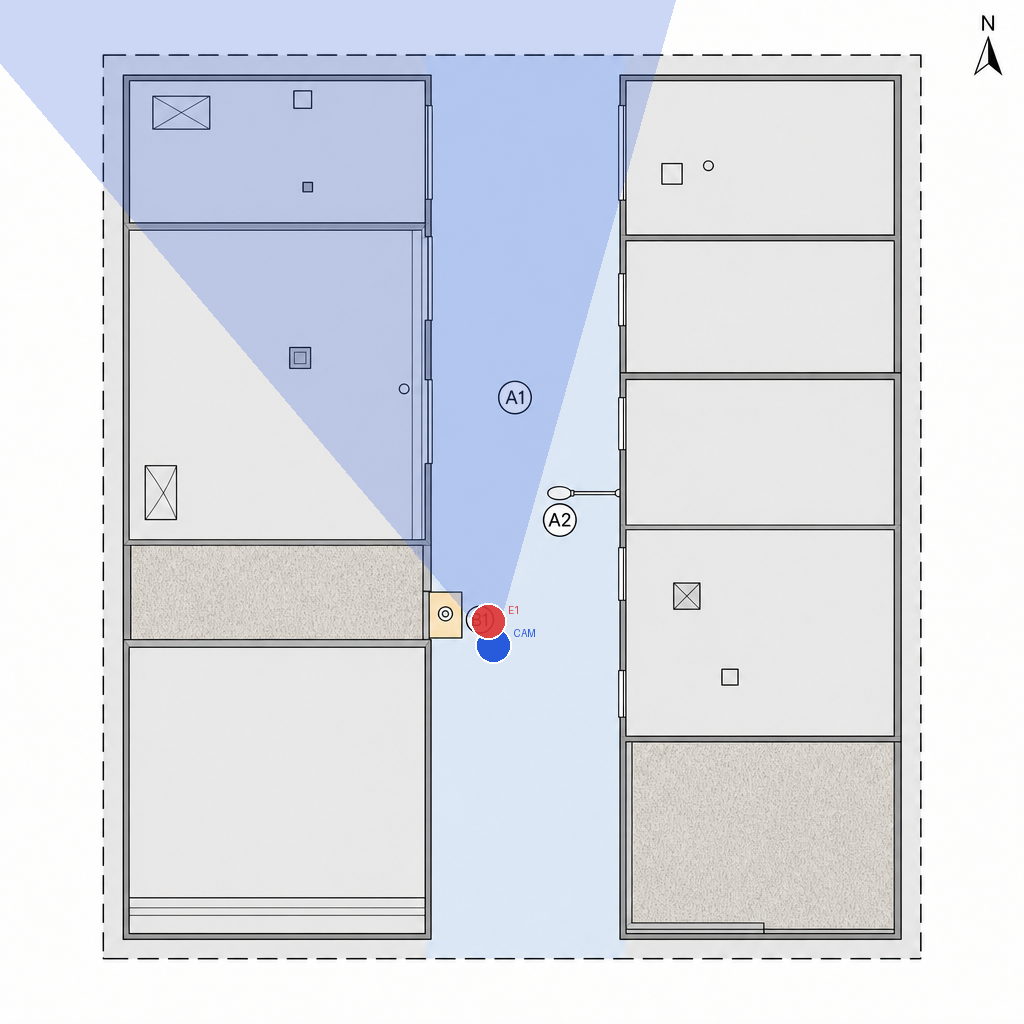
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S3sh2 map_marker · bg_urban_alley

geometry SOT: CAM=(0.52,0.72)→look(0.52,0.57) | 엔티티: E1(0.52,0.57), E2(0.47,0.55), E3(0.58,0.55), E4(0.46,0.59), E5(0.59,0.59), E6(0.49,0.64)
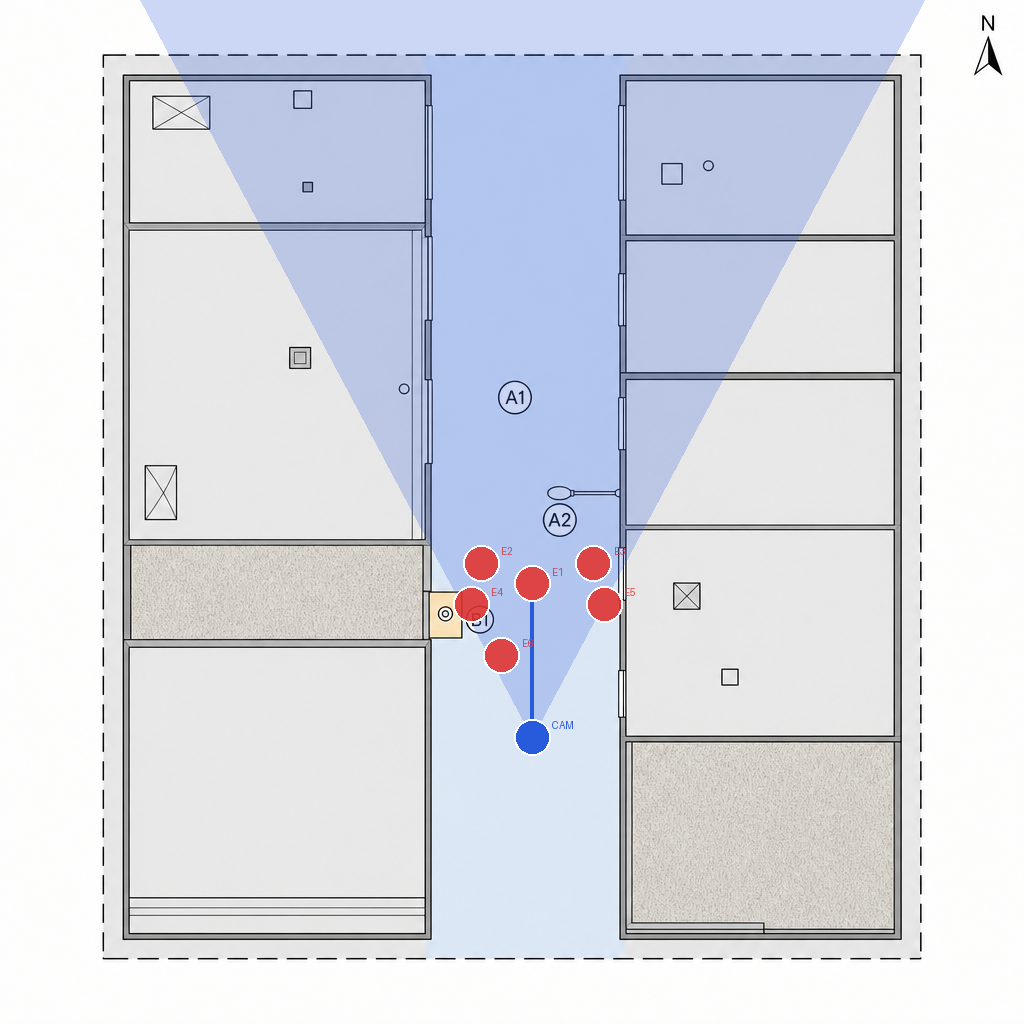
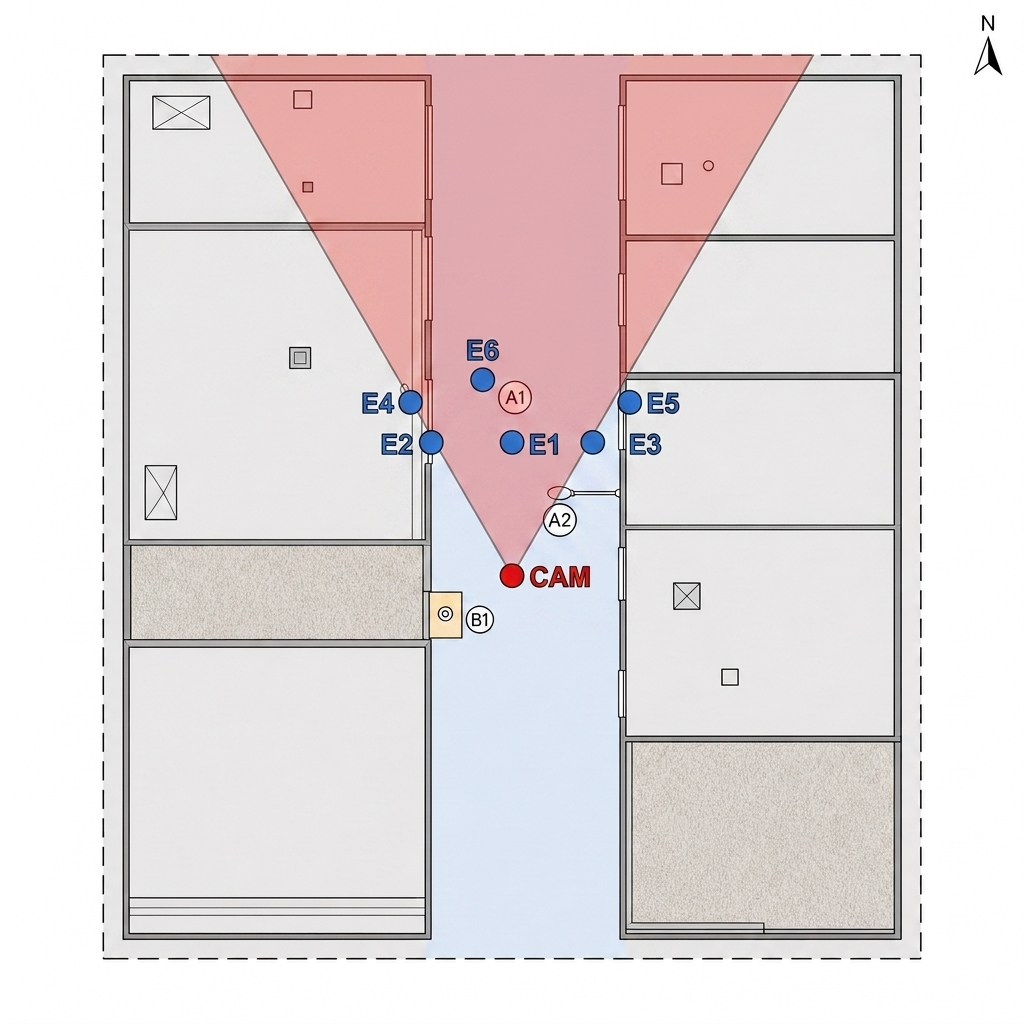
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

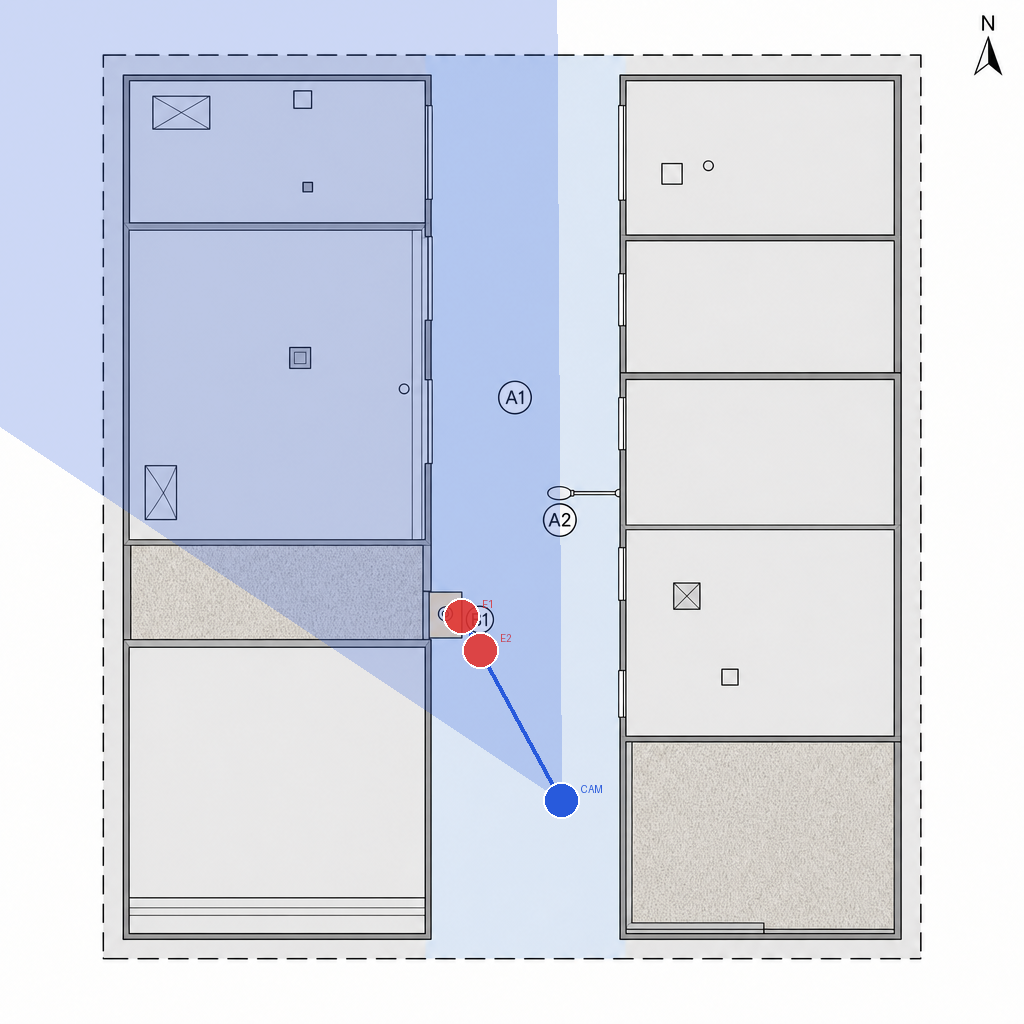
S4sh1 structure_plate · bg_rooftop_residence

geometry SOT: CAM=(0.61,0.93)→look(0.61,0.47) | 엔티티: E1(0.61,0.44)
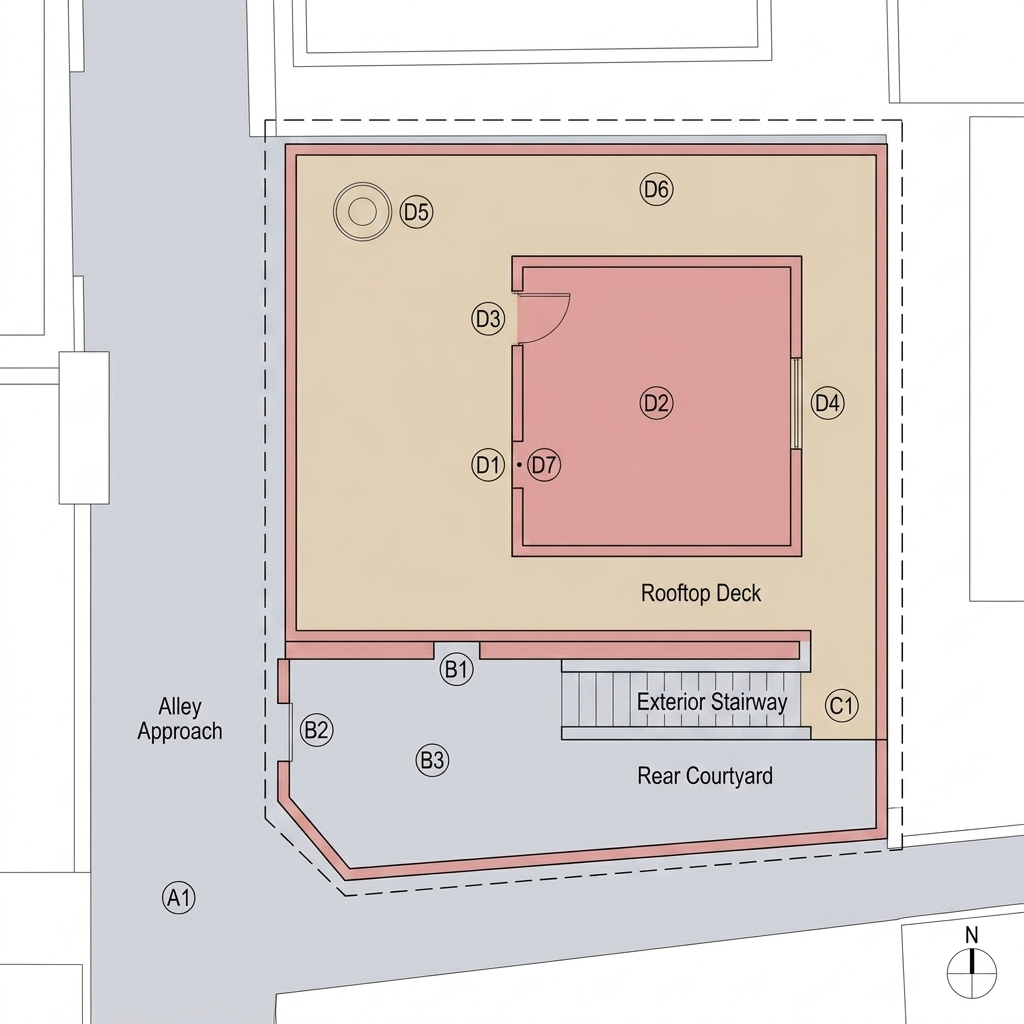
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

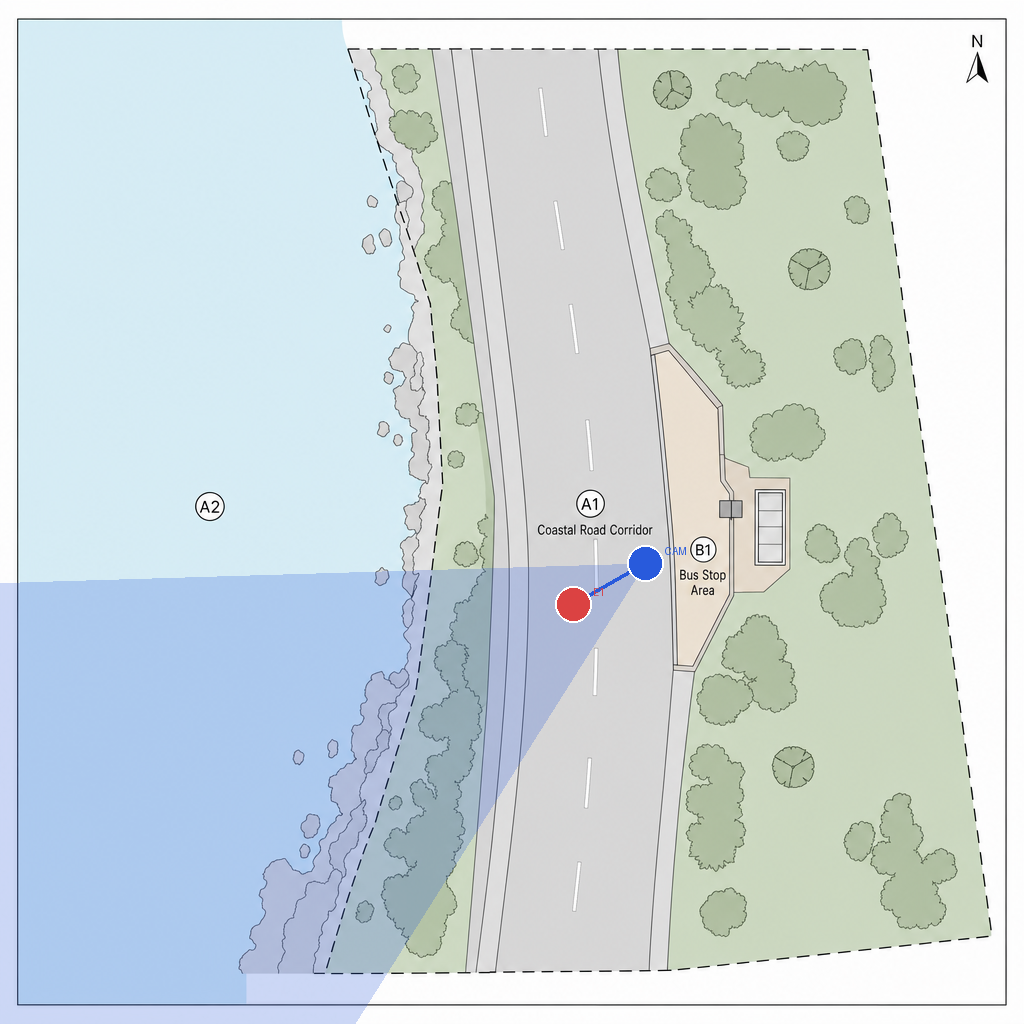
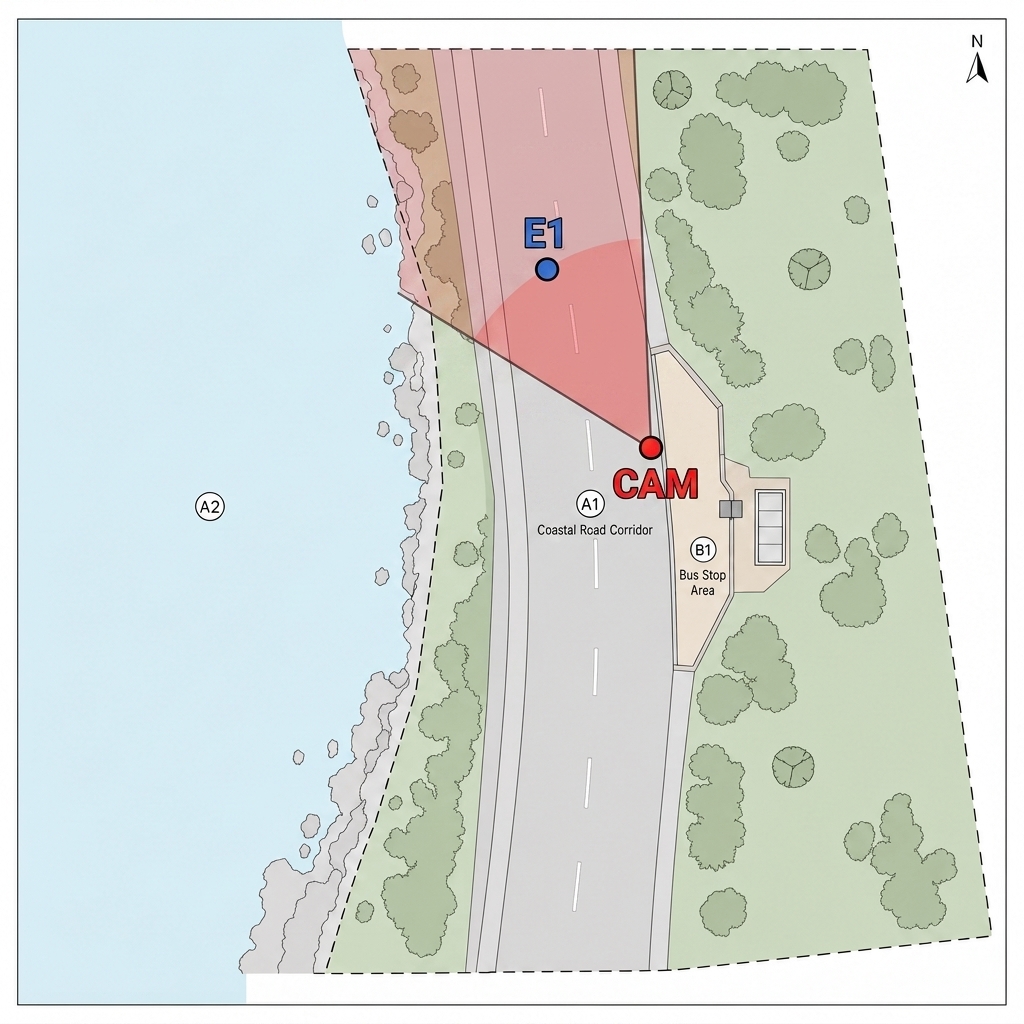
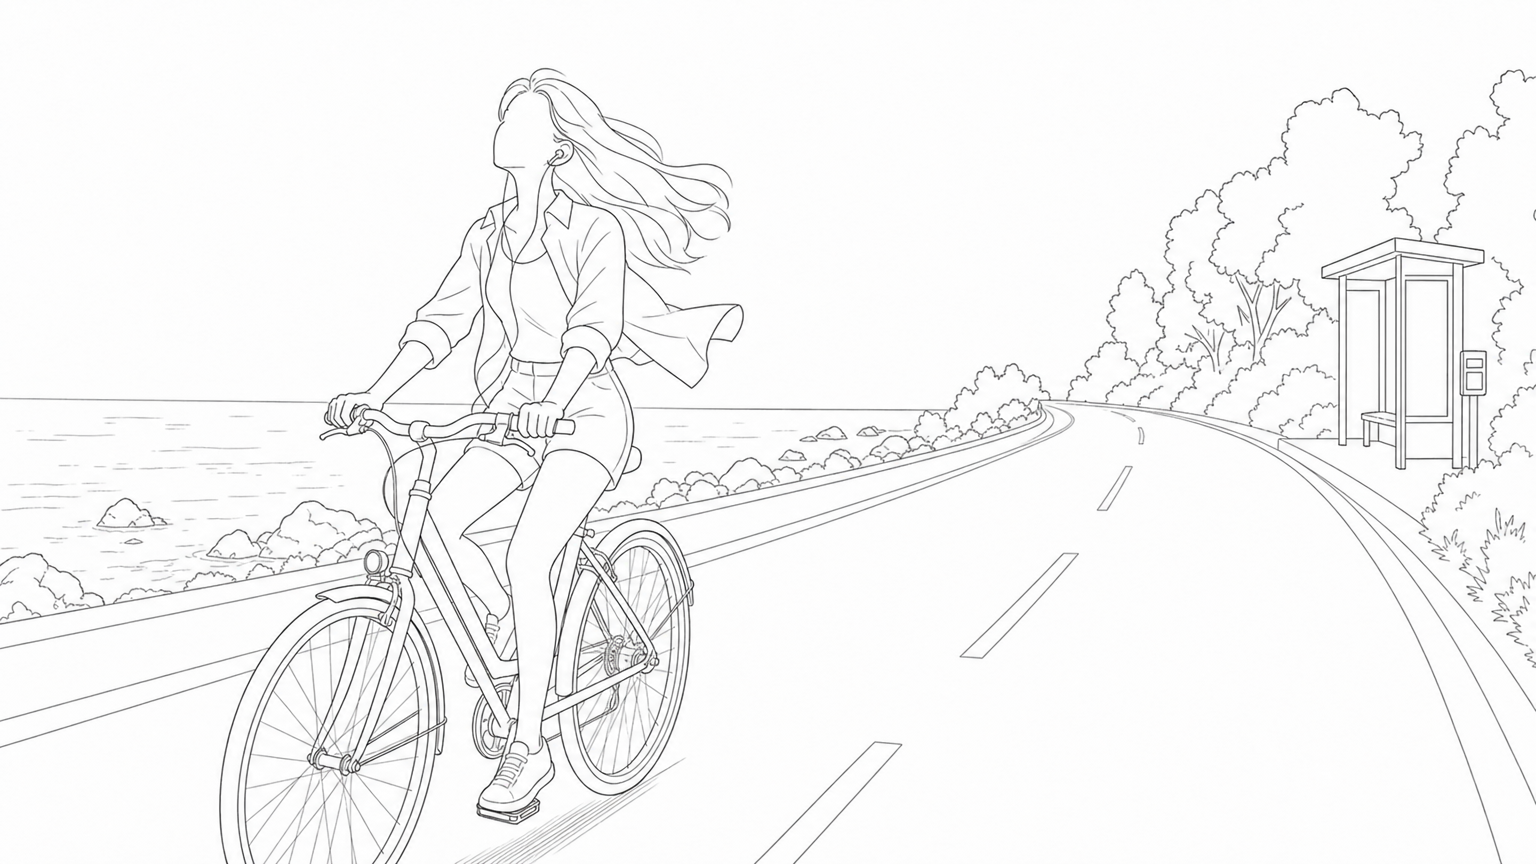
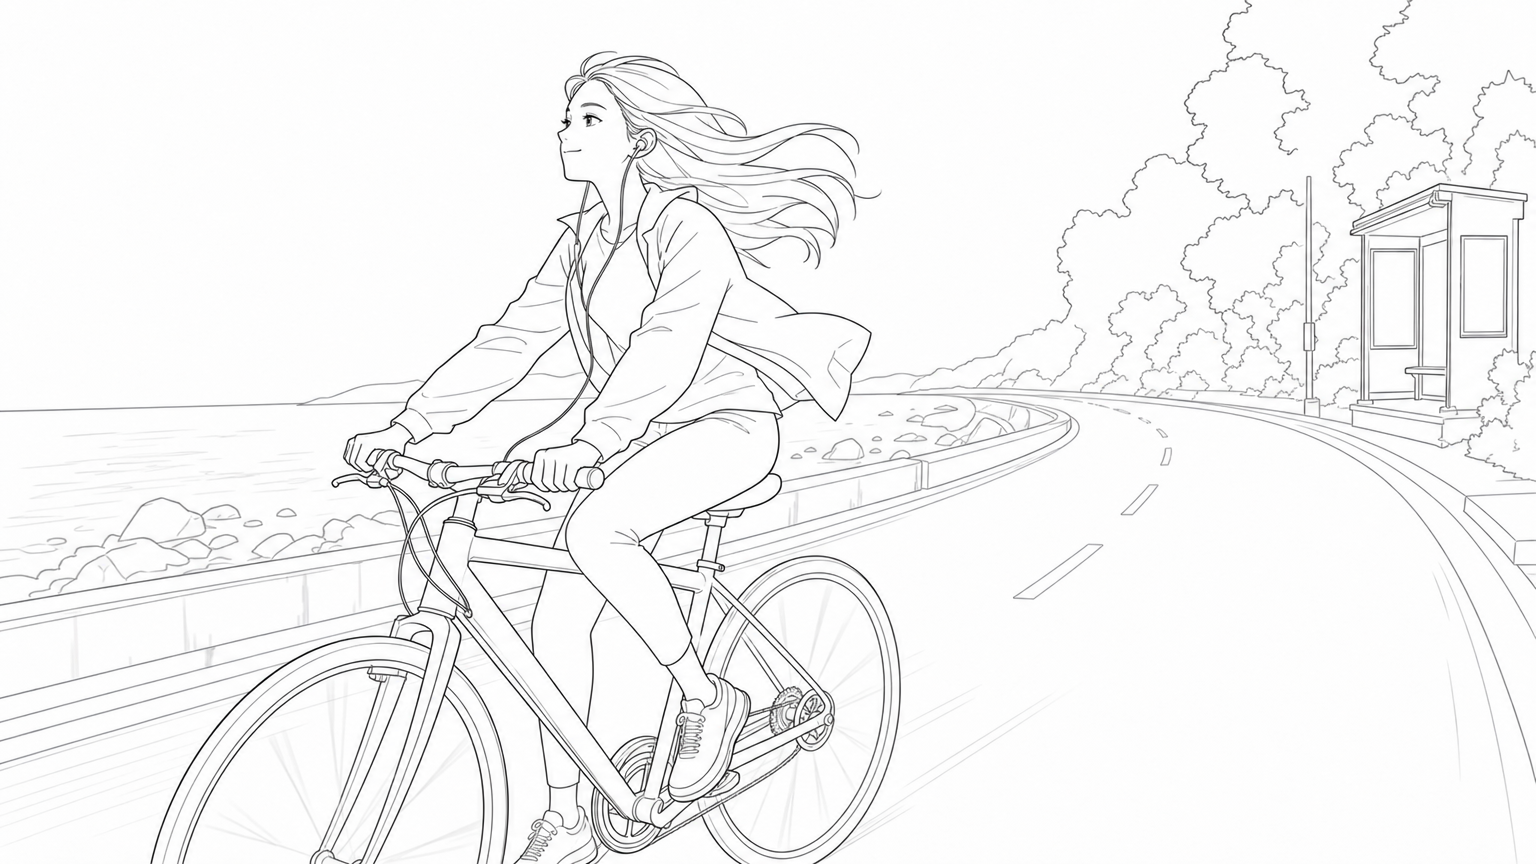
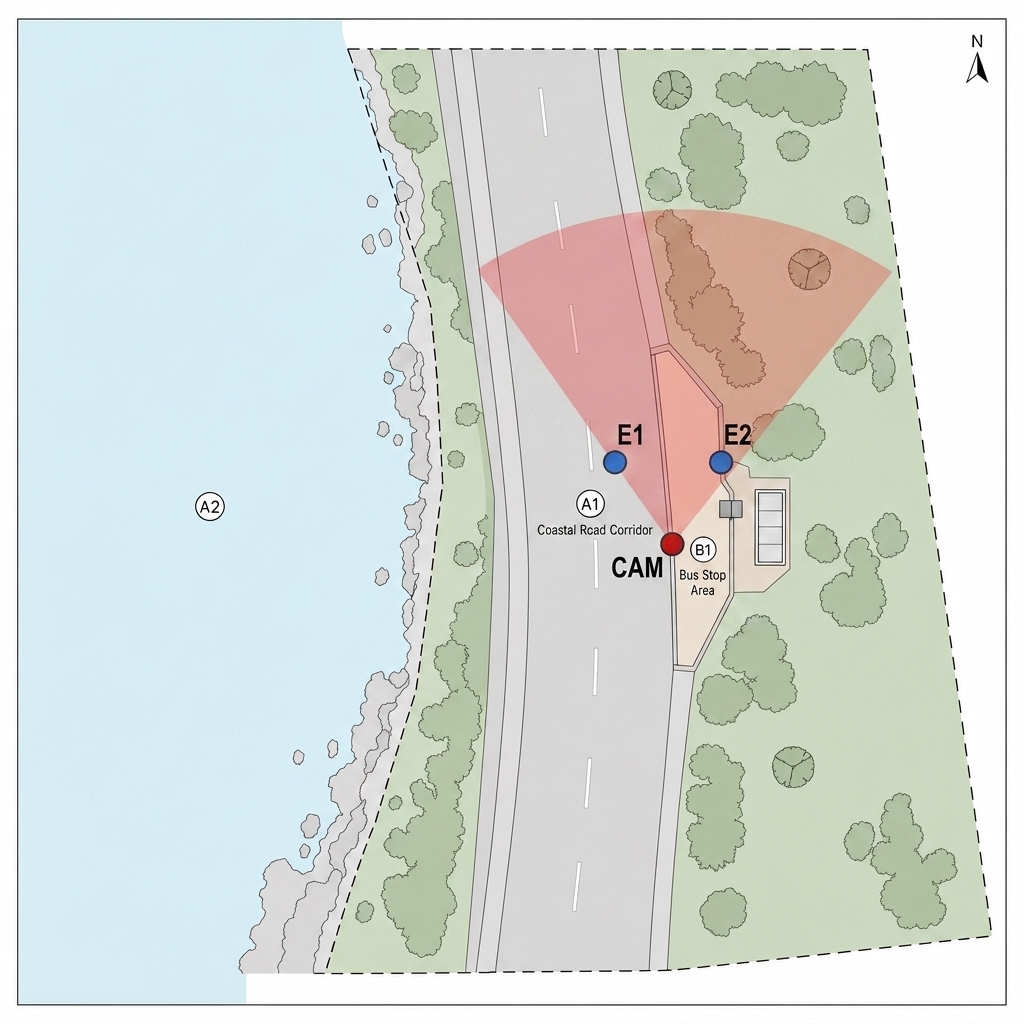
S6sh1 map_marker · bg_coastal_road

geometry SOT: CAM=(0.63,0.55)→look(0.56,0.59) | 엔티티: E1(0.56,0.59)
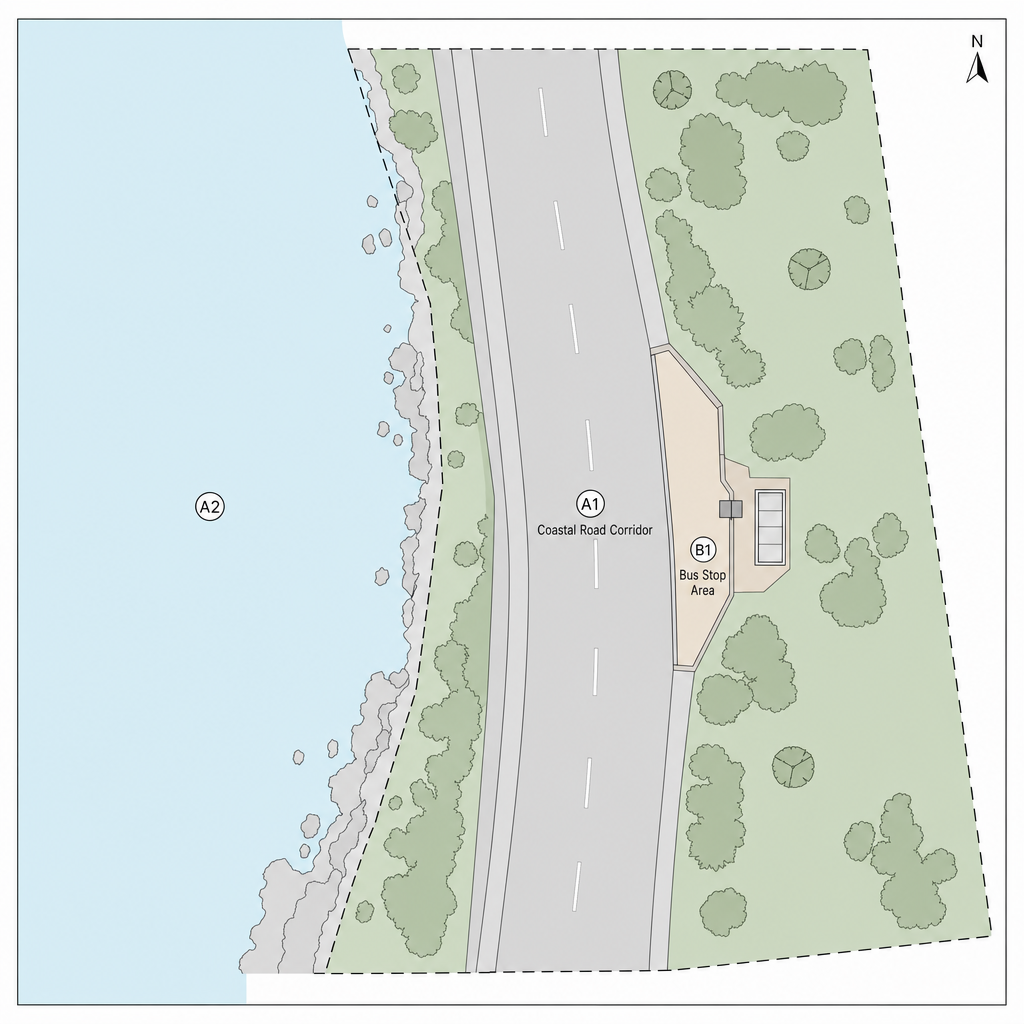
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

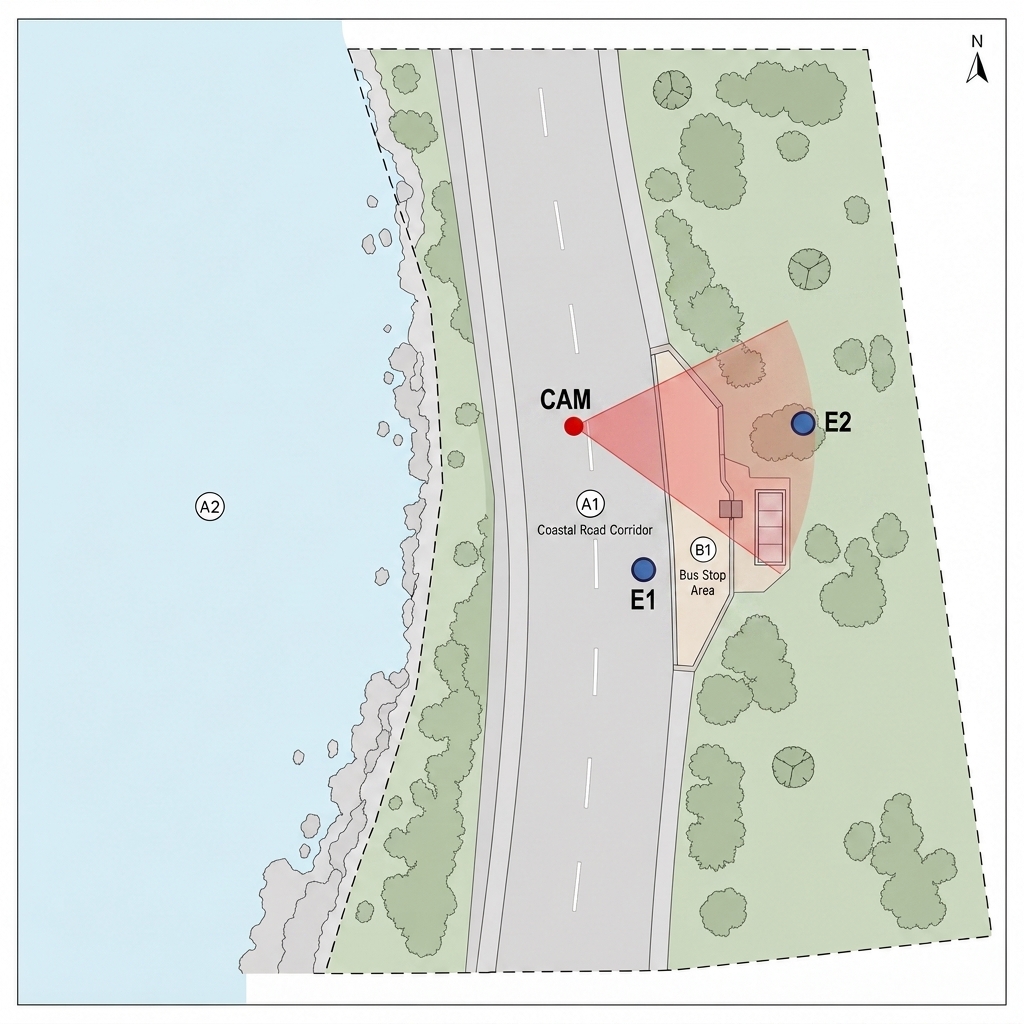
S9sh1 map_marker · bg_coastal_road

geometry SOT: CAM=(0.49,0.61)→look(0.56,0.61) | 엔티티: E1(0.56,0.61)
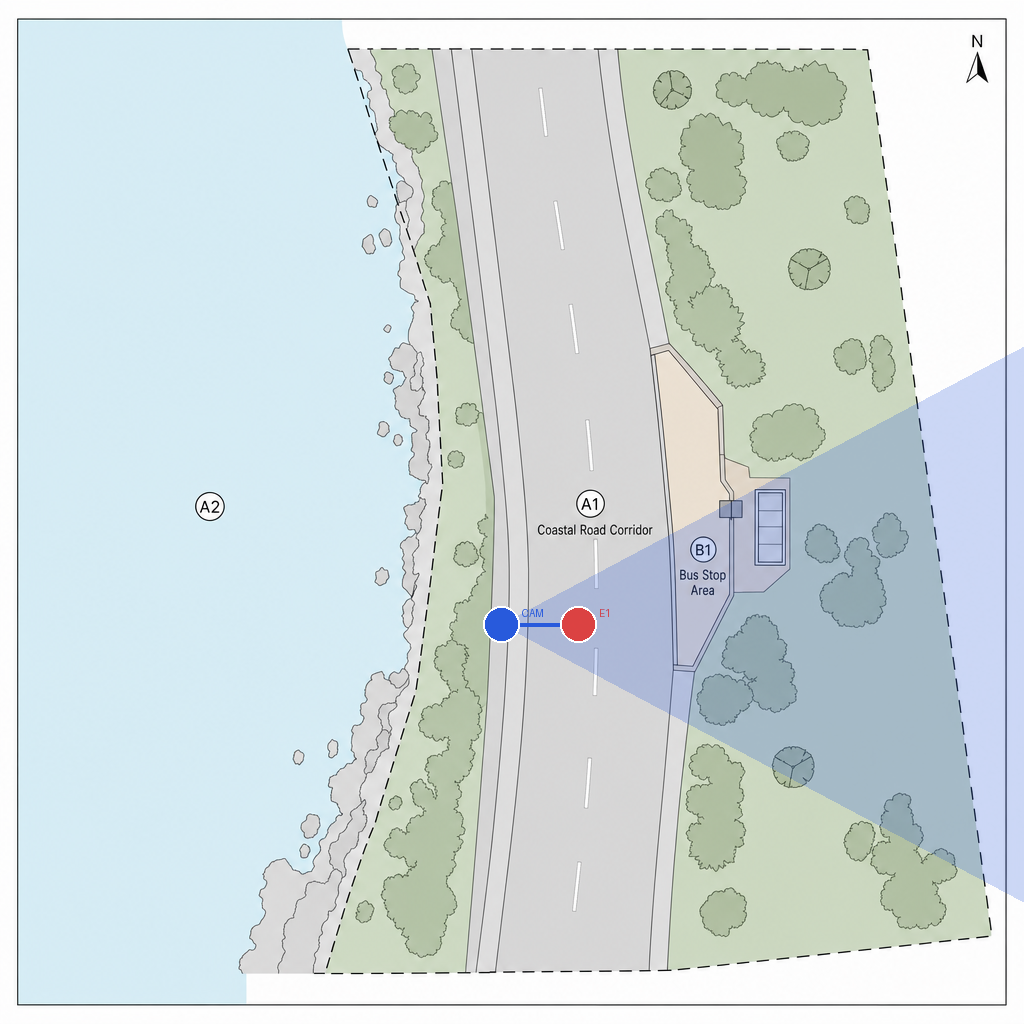
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S10sh3 structure_plate · bg_rooftop_residence

geometry SOT: CAM=(0.61,0.44)→look(0.61,0.38) | 엔티티: E1(0.61,0.38)
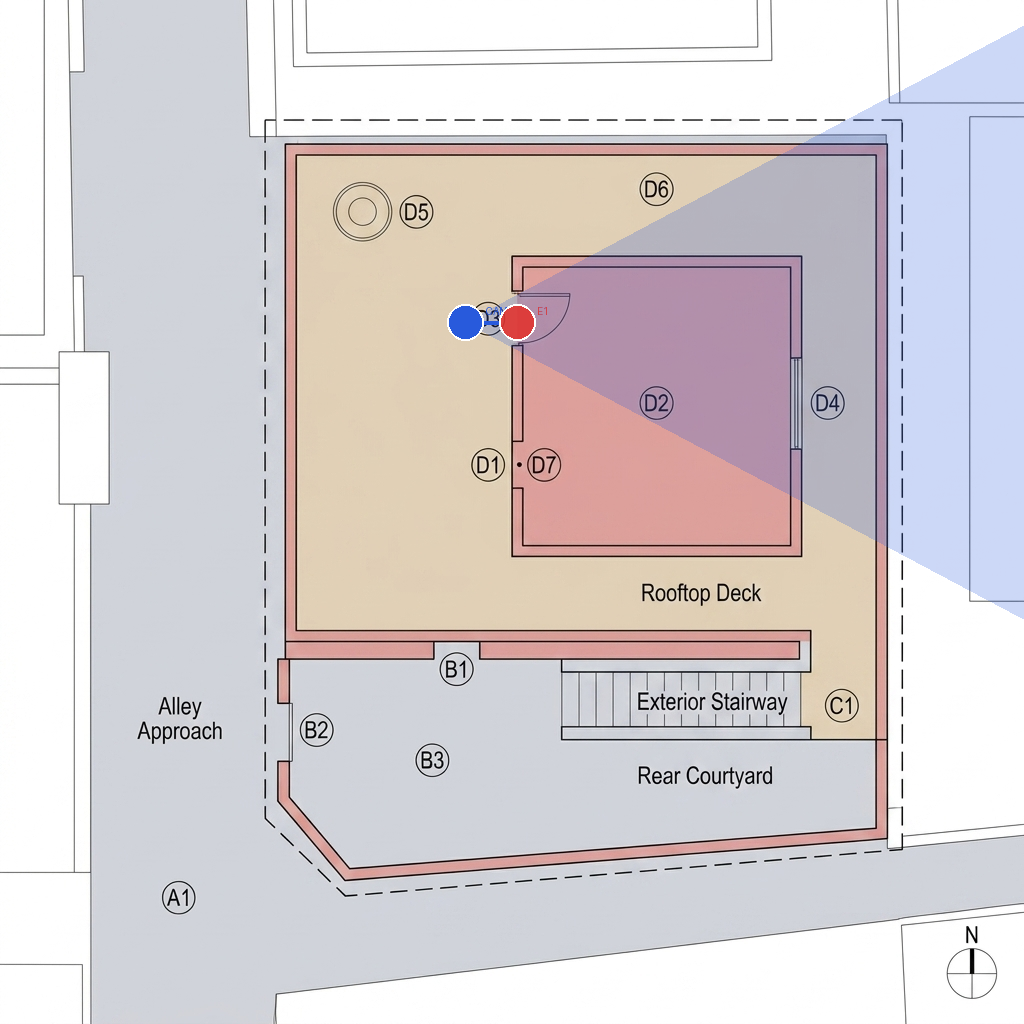
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S10sh4 structure_plate · bg_rooftop_residence

geometry SOT: CAM=(0.88,0.69)→look(0.81,0.69) | 엔티티: E1(0.77,0.71), E2(0.78,0.68)
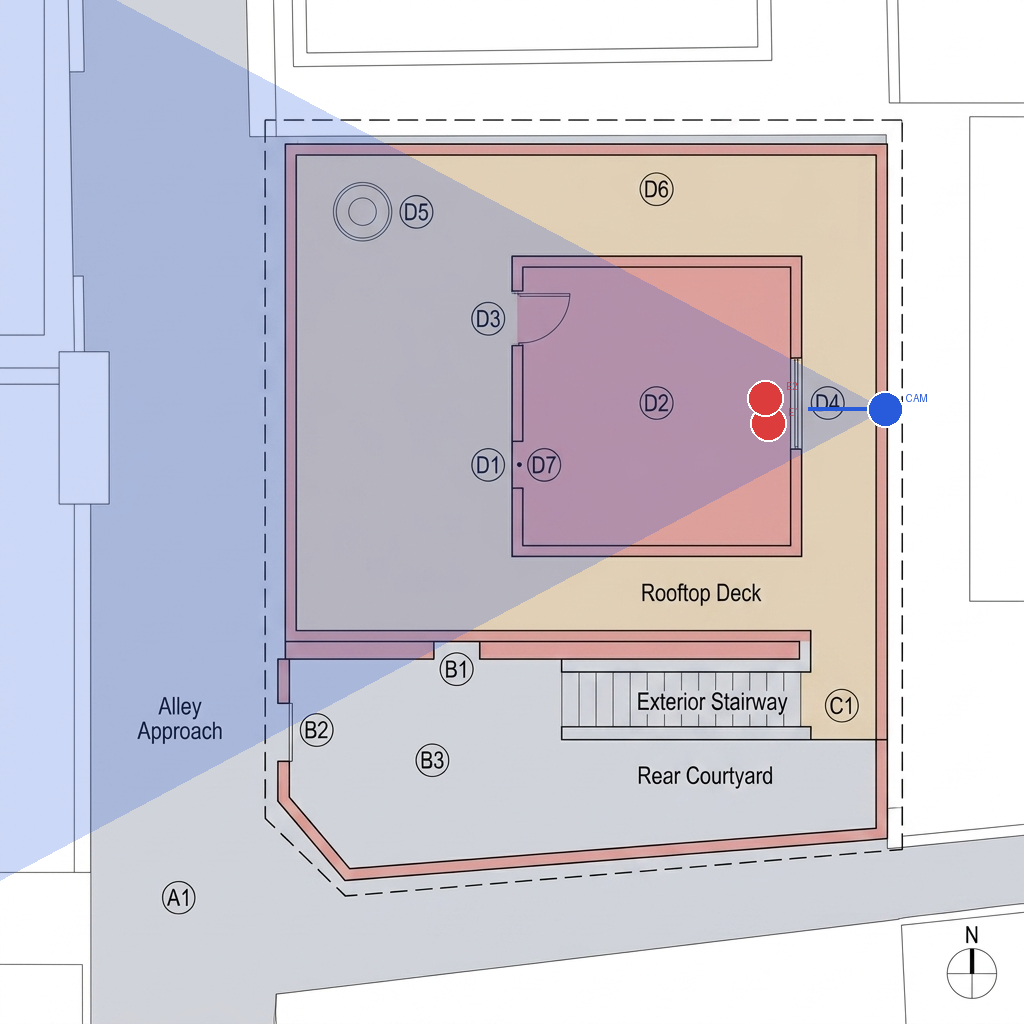
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S11sh3 structure_plate · bg_rooftop_residence

geometry SOT: CAM=(0.55,0.46)→look(0.61,0.38) | 엔티티: E1(0.57,0.44)
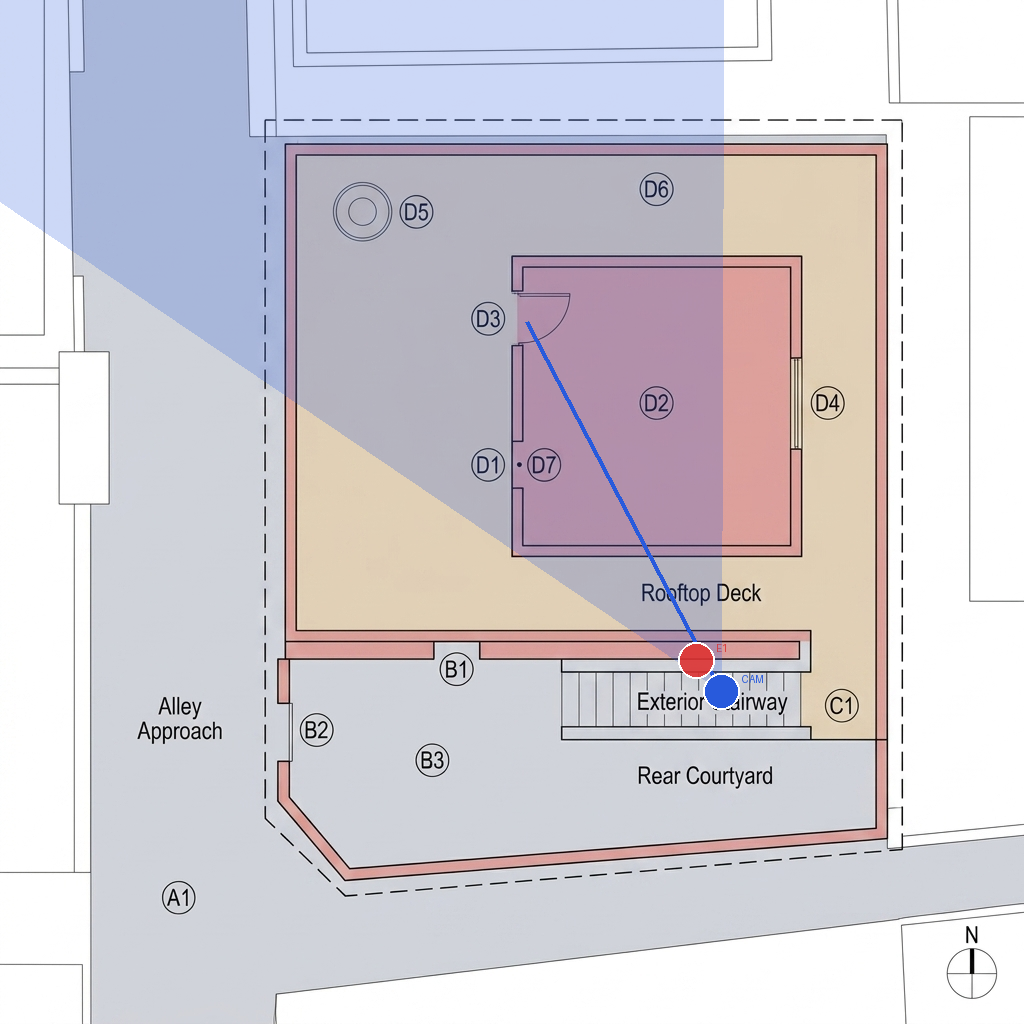
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S13sh3 structure_plate · bg_rooftop_residence

geometry SOT: CAM=(0.35,0.56)→look(0.41,0.52) | 엔티티: E1(0.41,0.52)
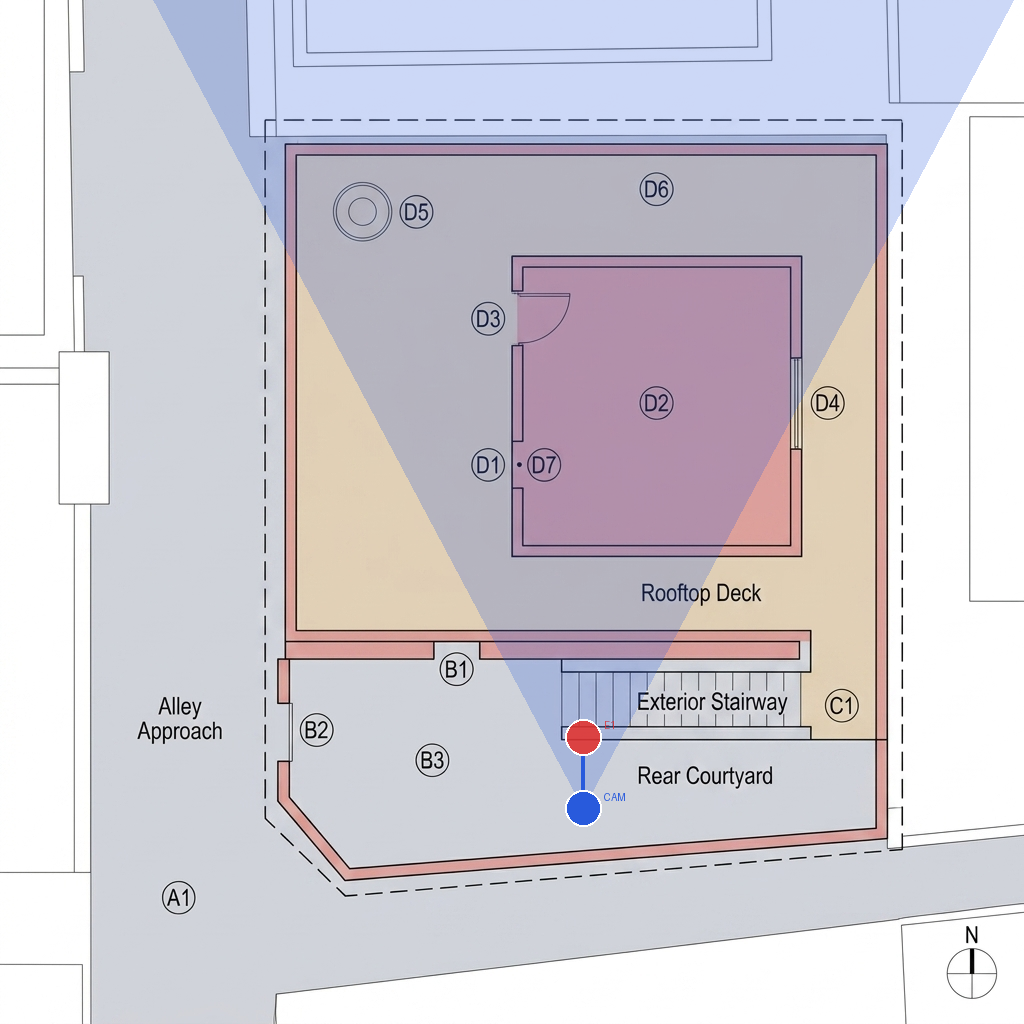
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

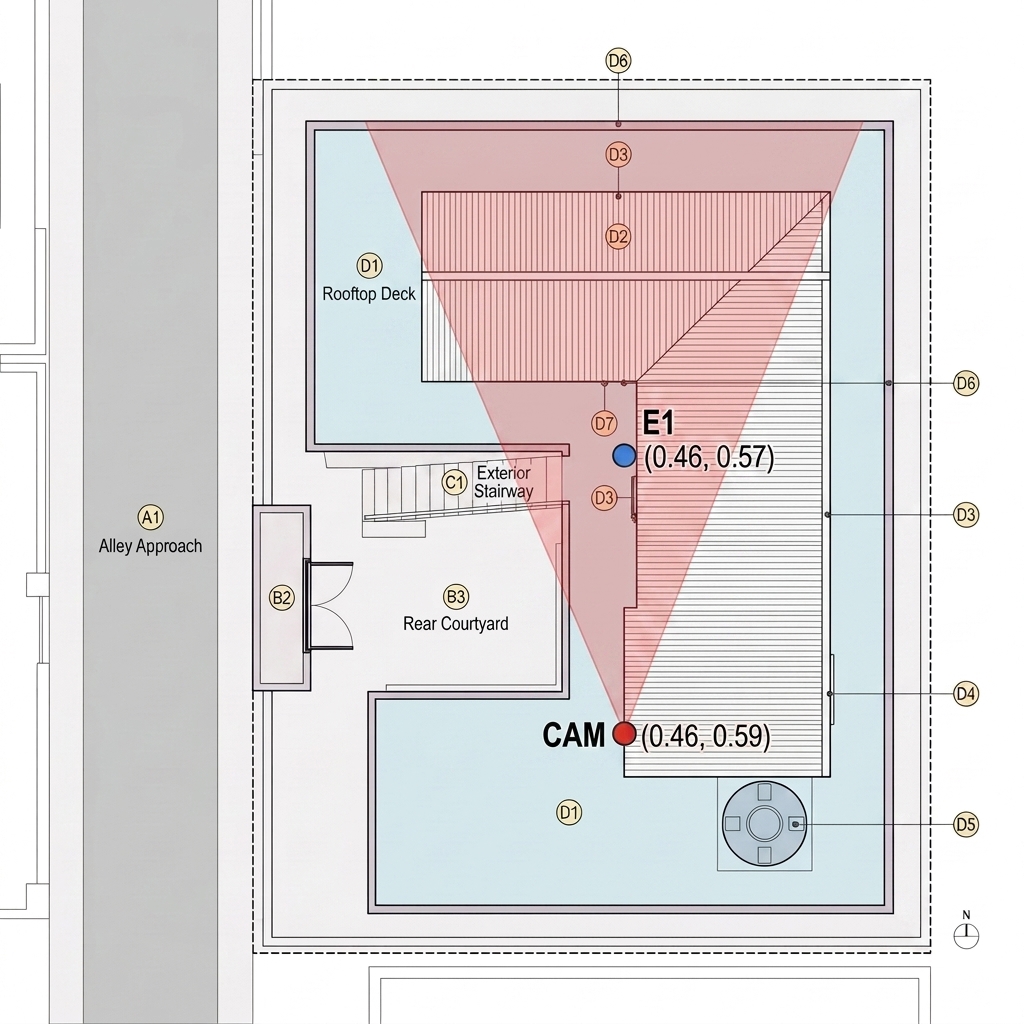
S13sh4 structure_plate · bg_rooftop_residence

geometry SOT: CAM=(0.46,0.59)→look(0.46,0.57) | 엔티티: E1(0.46,0.57)
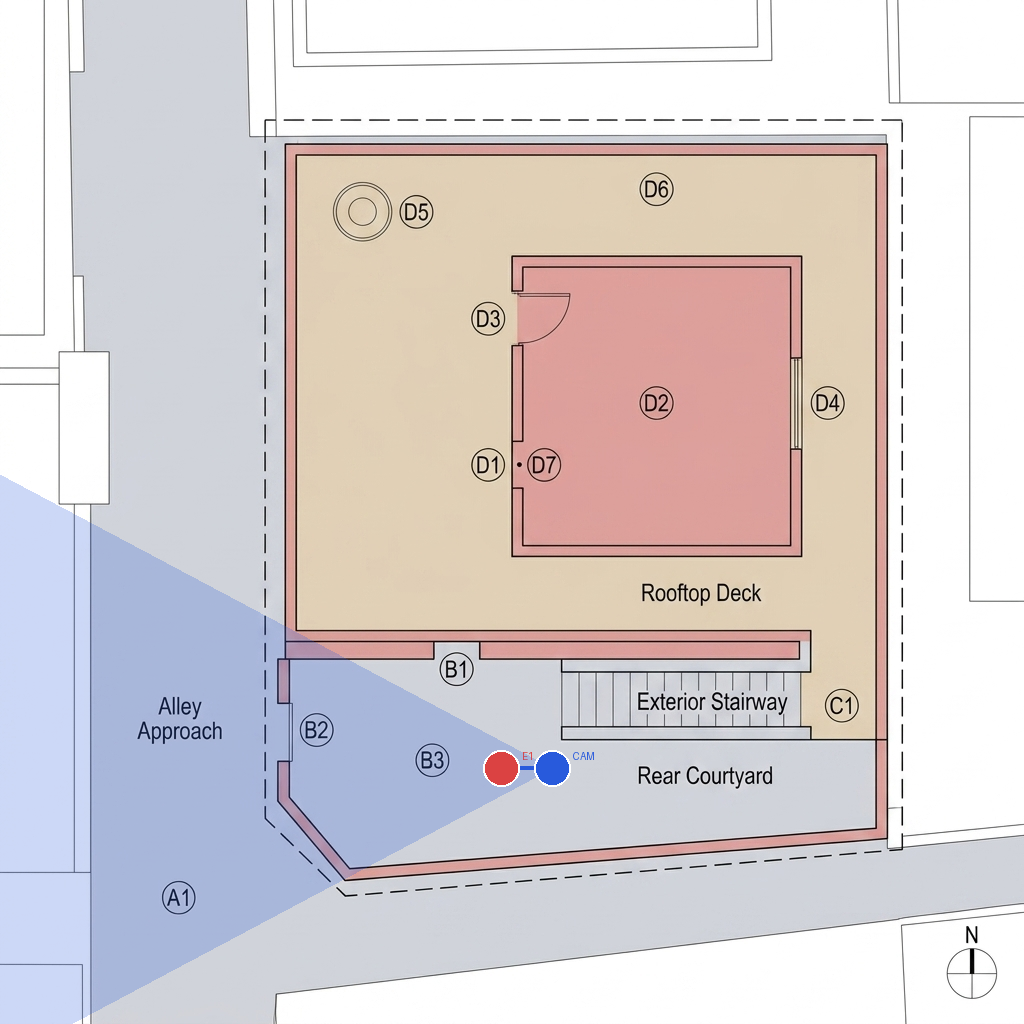
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S15sh2 map_marker · bg_coastal_road

geometry SOT: CAM=(0.74,0.55)→look(0.74,0.52) | 엔티티: E1(0.73,0.52), E2(0.76,0.52)
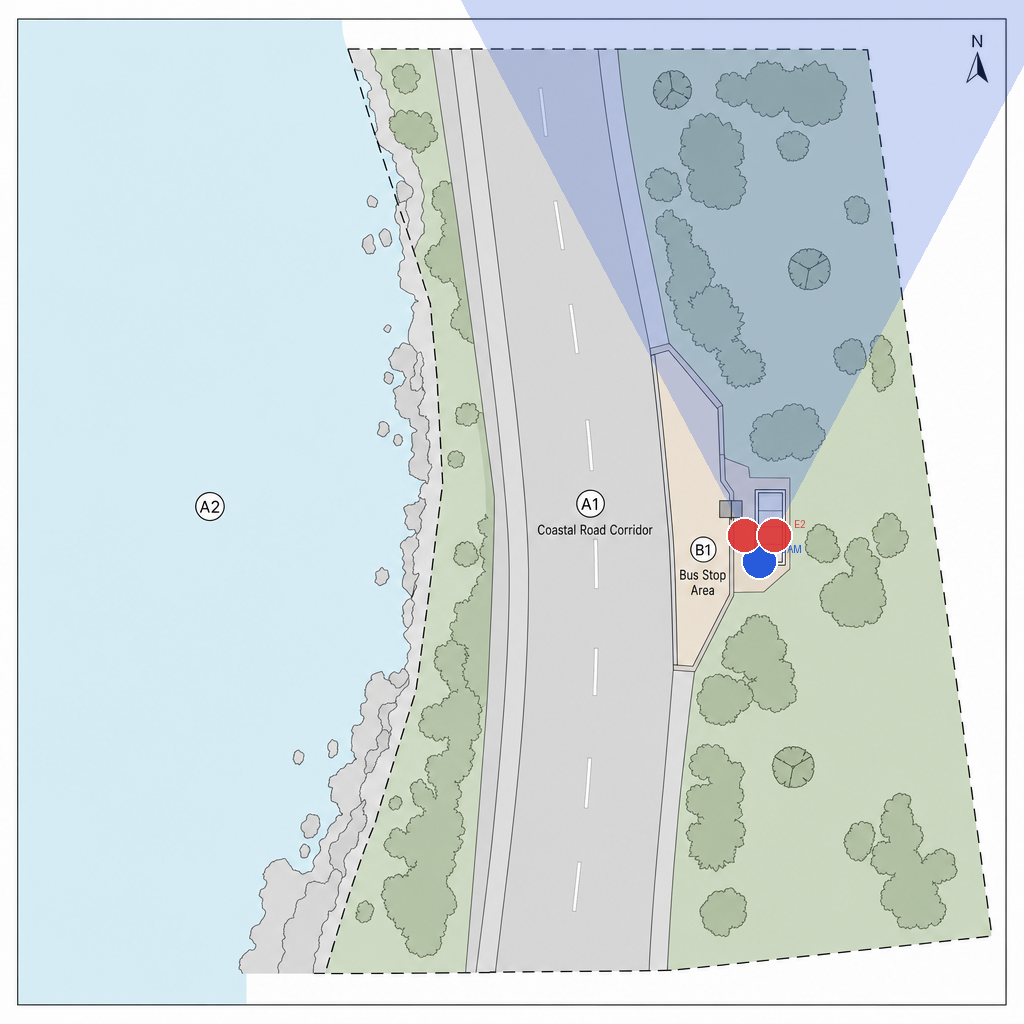
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S15sh5 map_marker · bg_coastal_road

geometry SOT: CAM=(0.49,0.58)→look(0.64,0.49) | 엔티티: E1(0.59,0.47), E2(0.70,0.55)
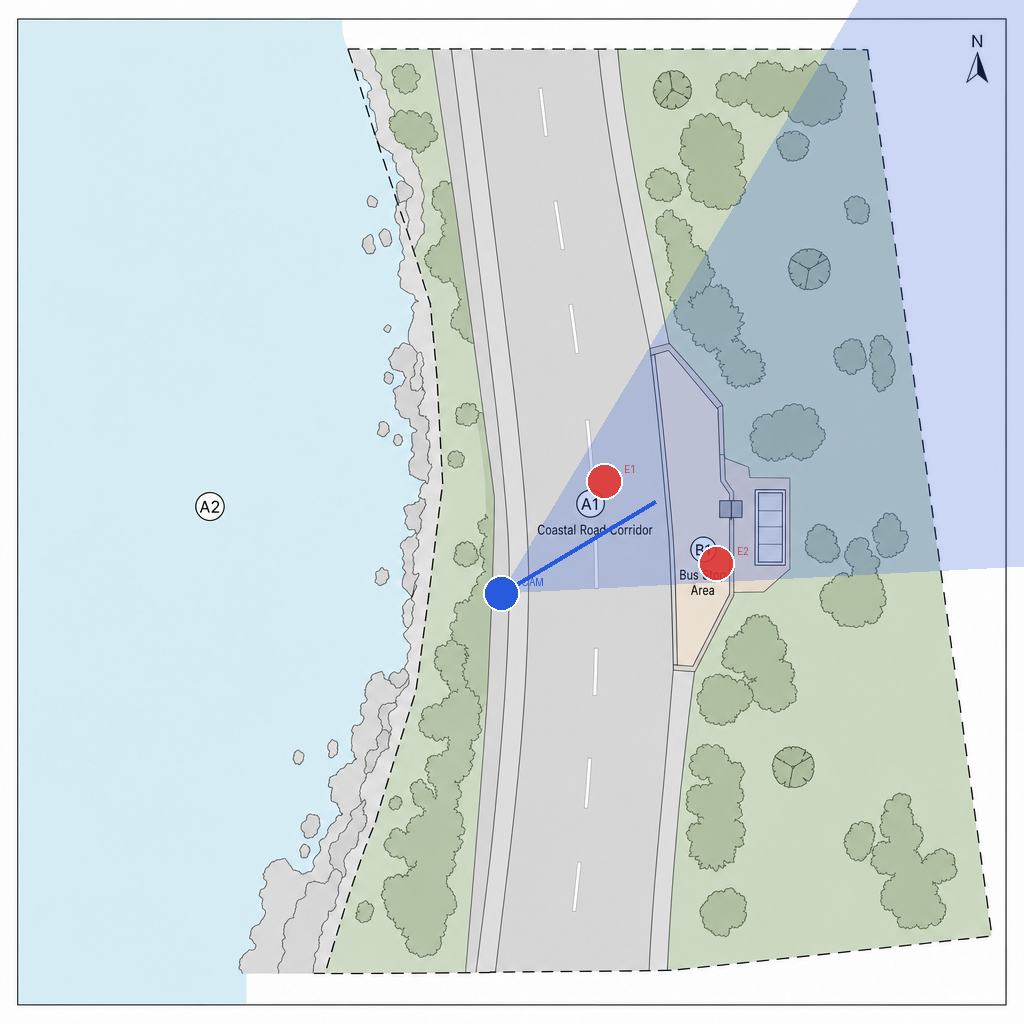
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S17sh1 structure_plate · bg_rooftop_residence

geometry SOT: CAM=(0.69,0.25)→look(0.86,0.54) | 엔티티: E1(0.91,0.39)
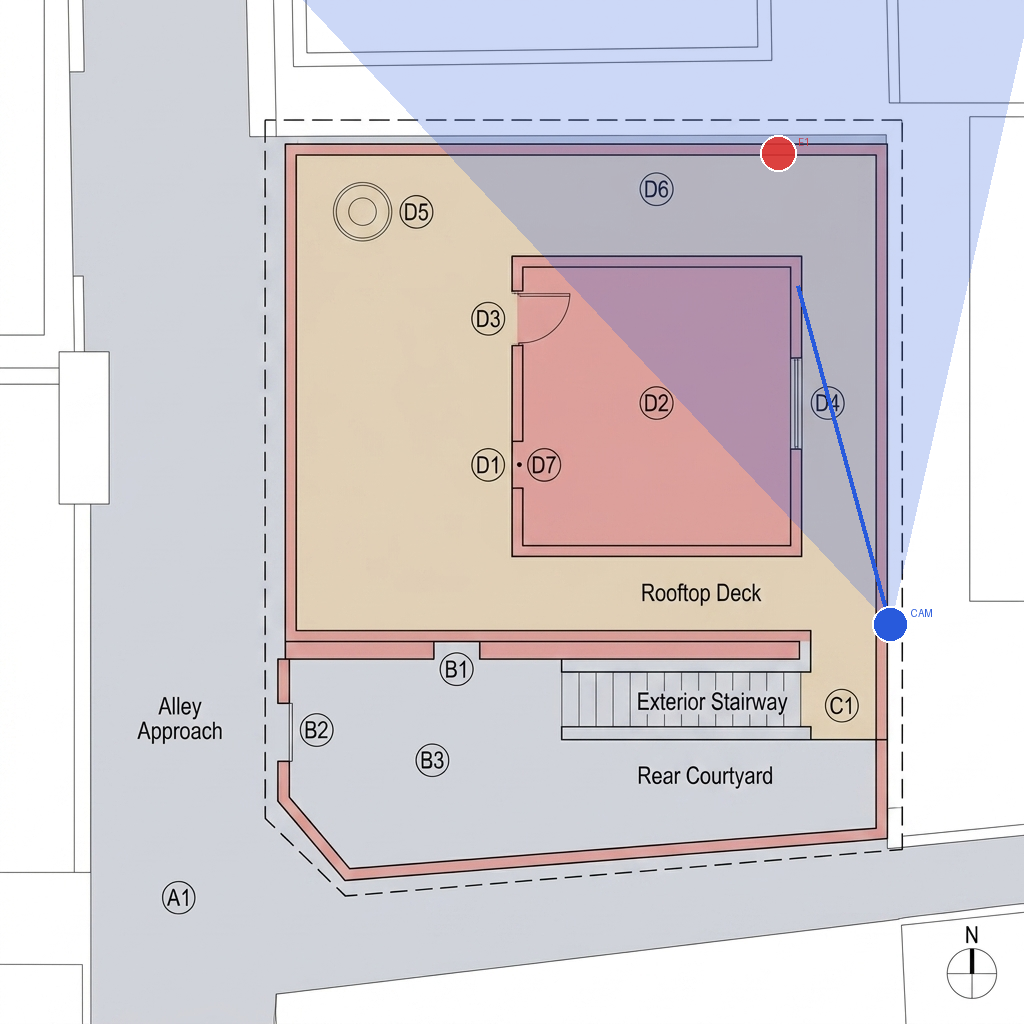
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S22sh1 structure_plate · bg_coastal_road

geometry SOT: CAM=(0.56,0.30)→look(0.49,0.30) | 엔티티: E1(0.49,0.30)
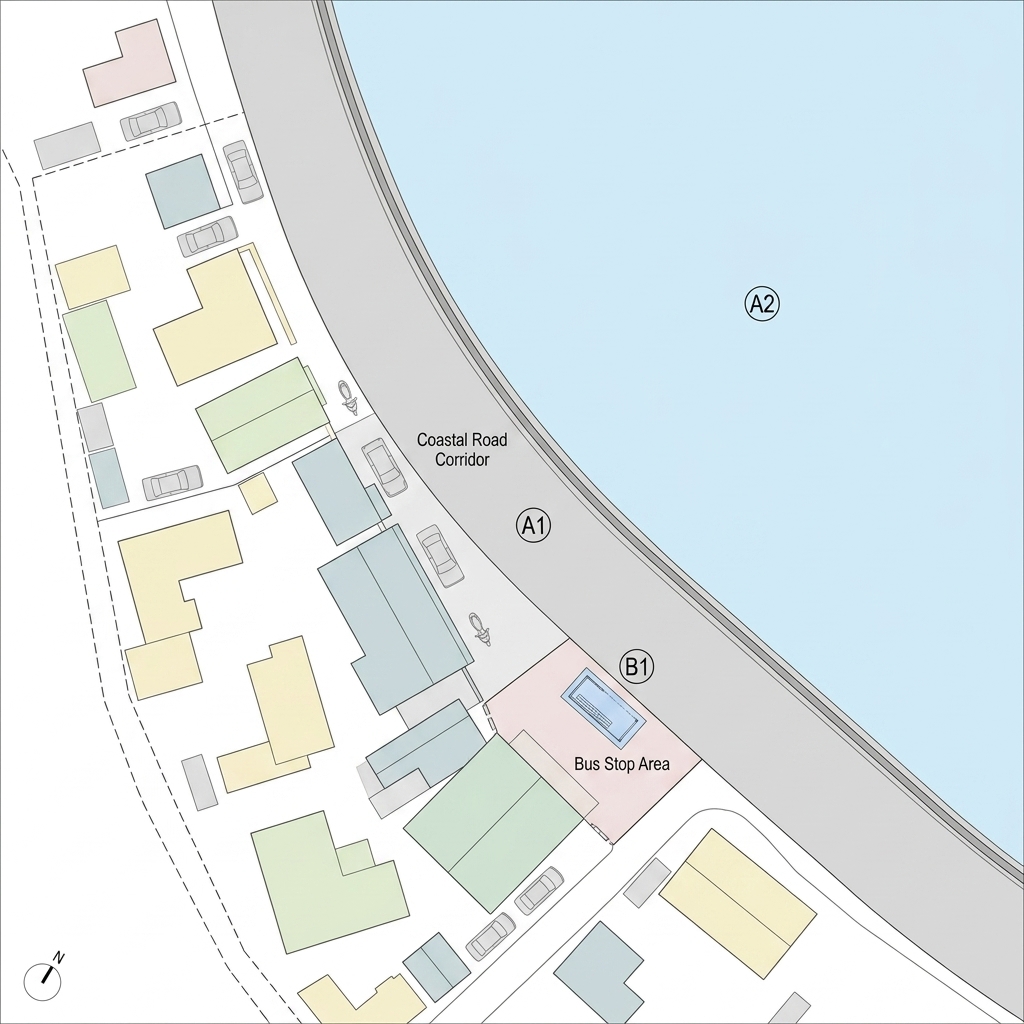
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S24sh1 map_marker · bg_coastal_road

geometry SOT: CAM=(0.48,0.58)→look(0.57,0.58) | 엔티티: E1(0.57,0.58)
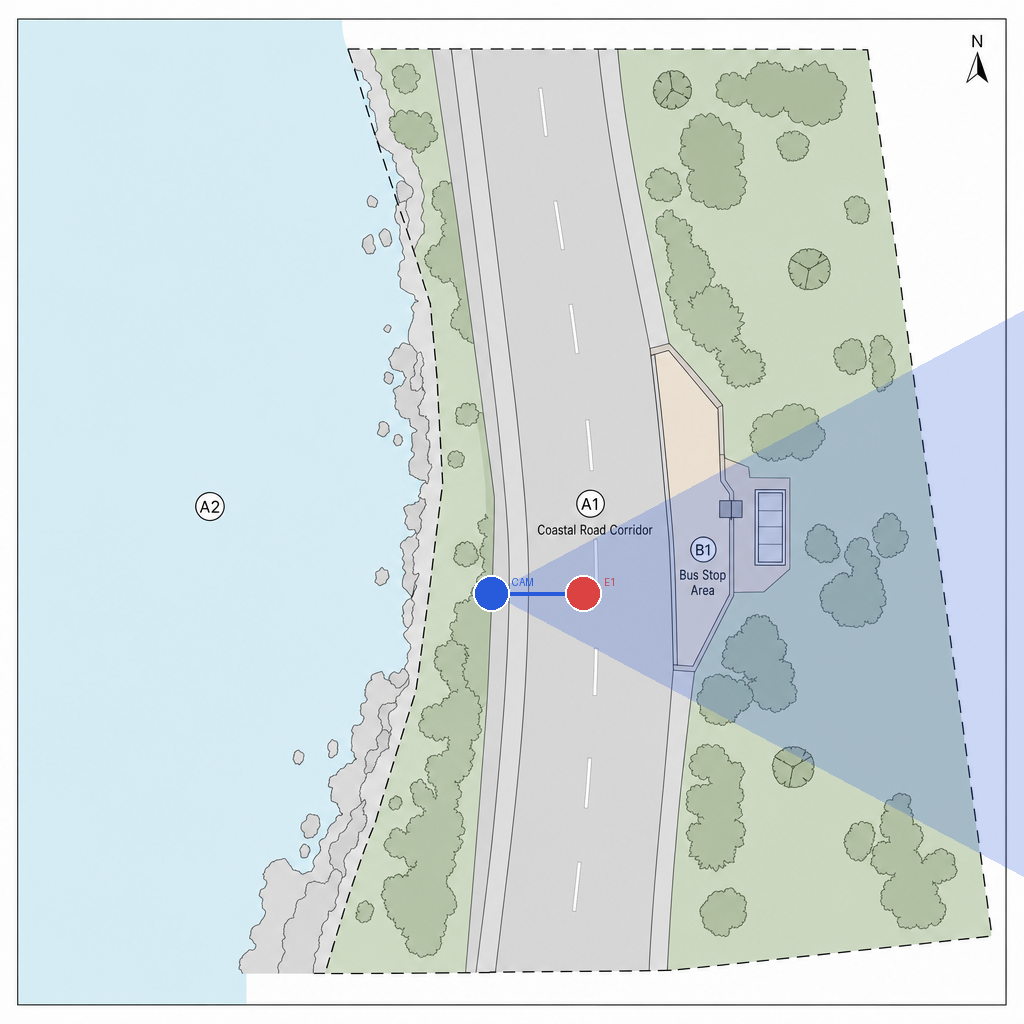
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S26sh2 map_marker · bg_foggy_harbor

geometry SOT: CAM=(0.27,0.56)→look(0.27,0.48) | 엔티티: E1(0.27,0.48)
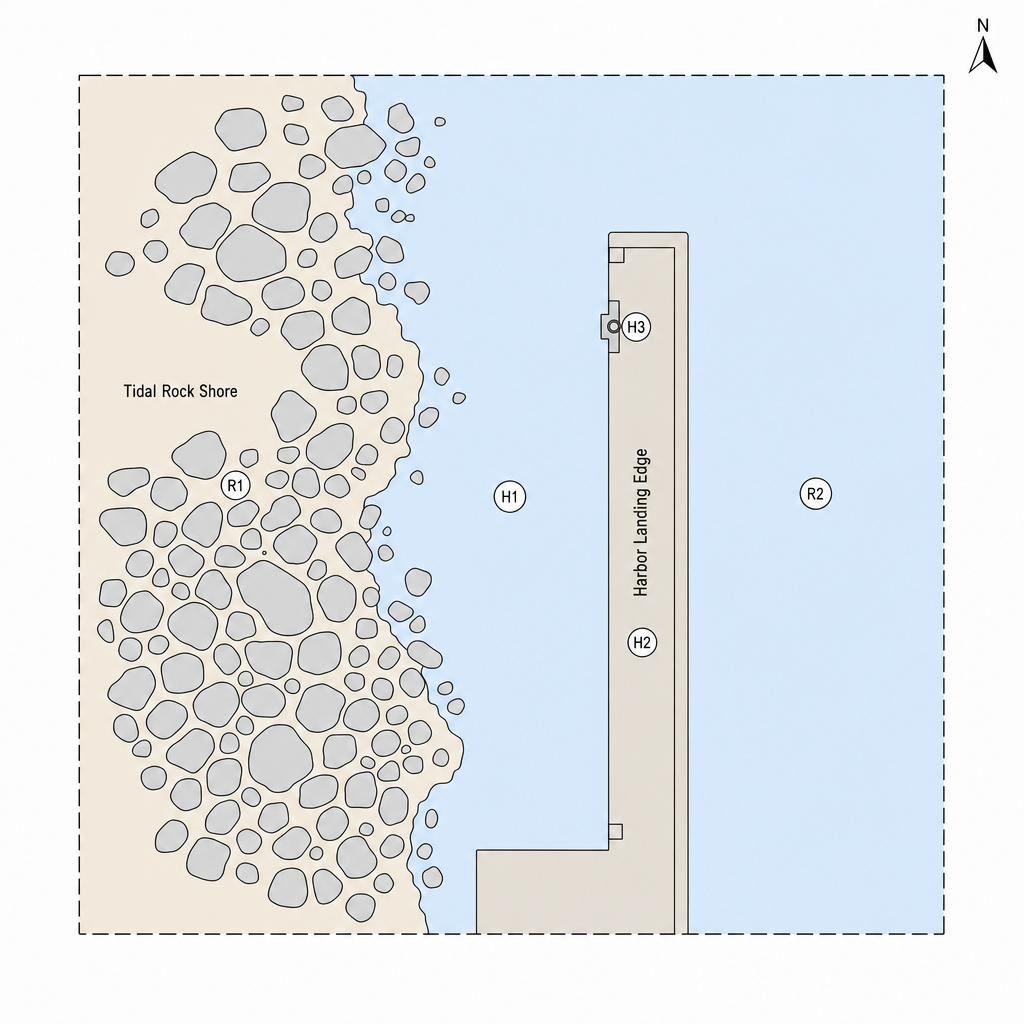
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S26sh6 map_marker · bg_foggy_harbor

geometry SOT: CAM=(0.66,0.36)→look(0.61,0.32) | 엔티티: E1(0.63,0.35), E2(0.60,0.32)
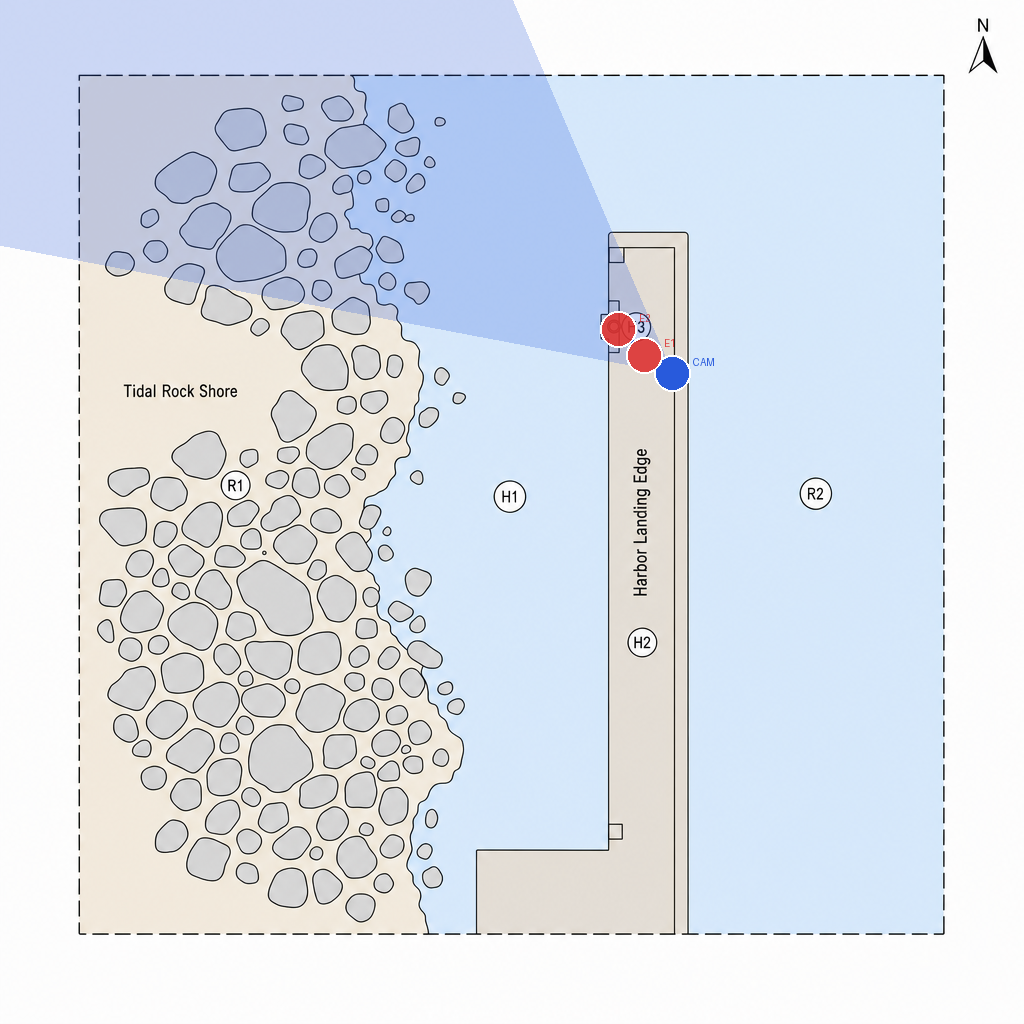
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S28sh3 map_marker · bg_small_fishing_boat

geometry SOT: CAM=(0.44,0.41)→look(0.48,0.40) | 엔티티: E1(0.48,0.40), E2(0.55,0.37)
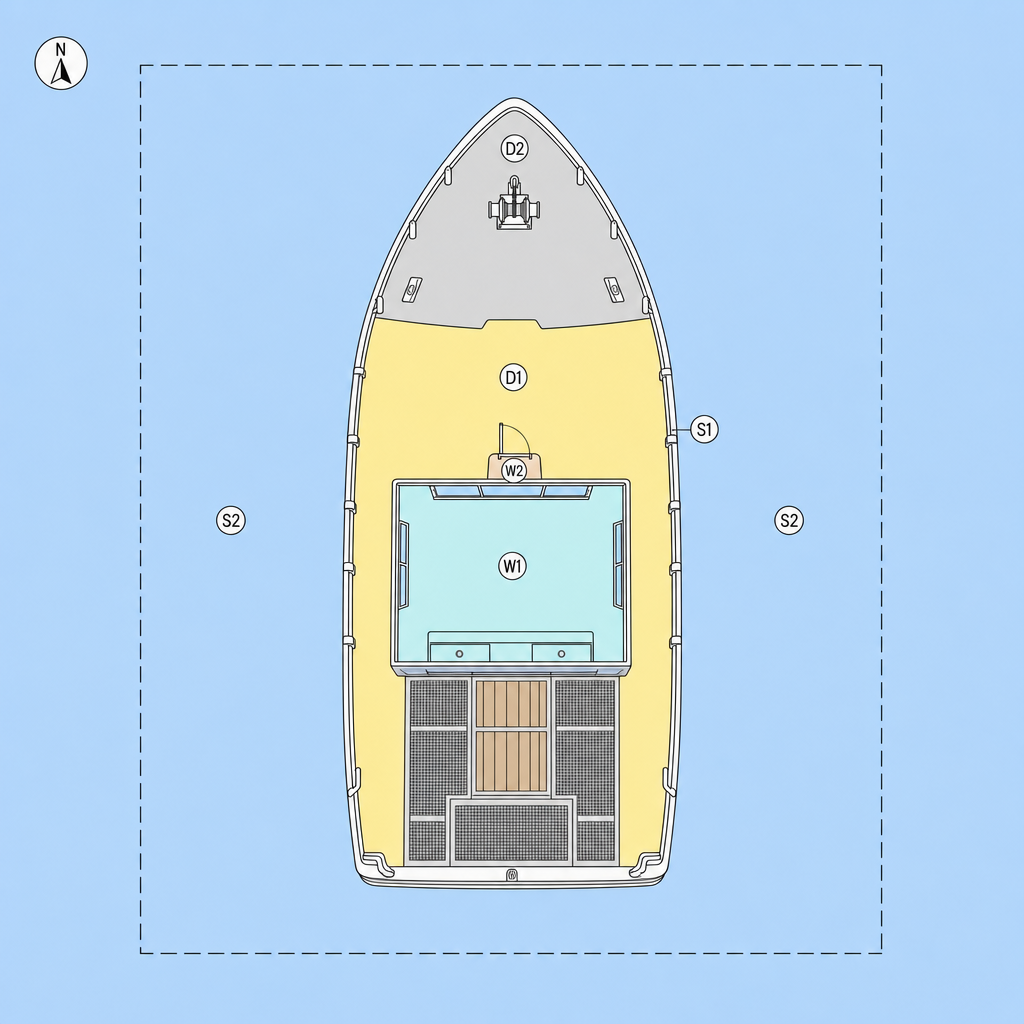
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S28sh4 map_marker · bg_small_fishing_boat

geometry SOT: CAM=(0.46,0.35)→look(0.50,0.41) | 엔티티: E1(0.50,0.41)
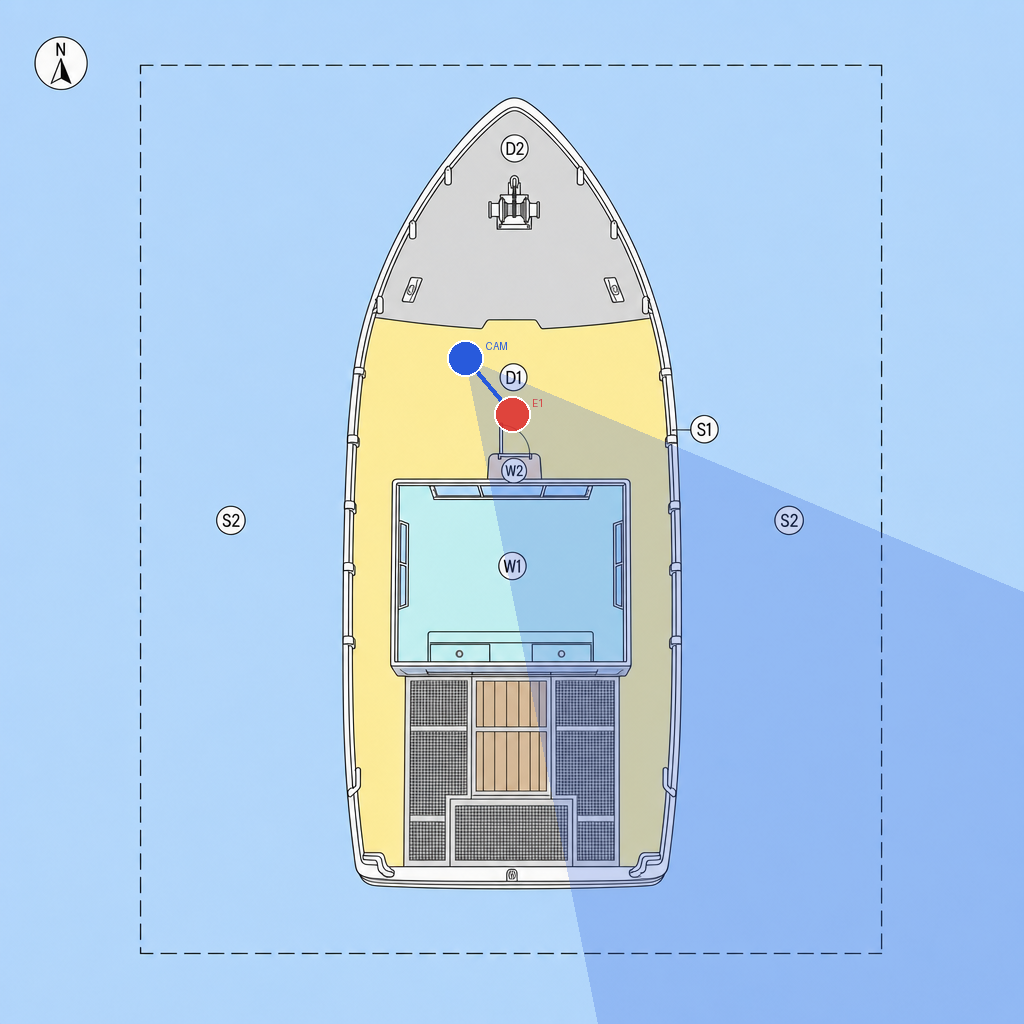
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)

S30sh1 map_marker · bg_small_fishing_boat

geometry SOT: CAM=(0.79,0.89)→look(0.50,0.40) | 엔티티: E1(0.50,0.51)
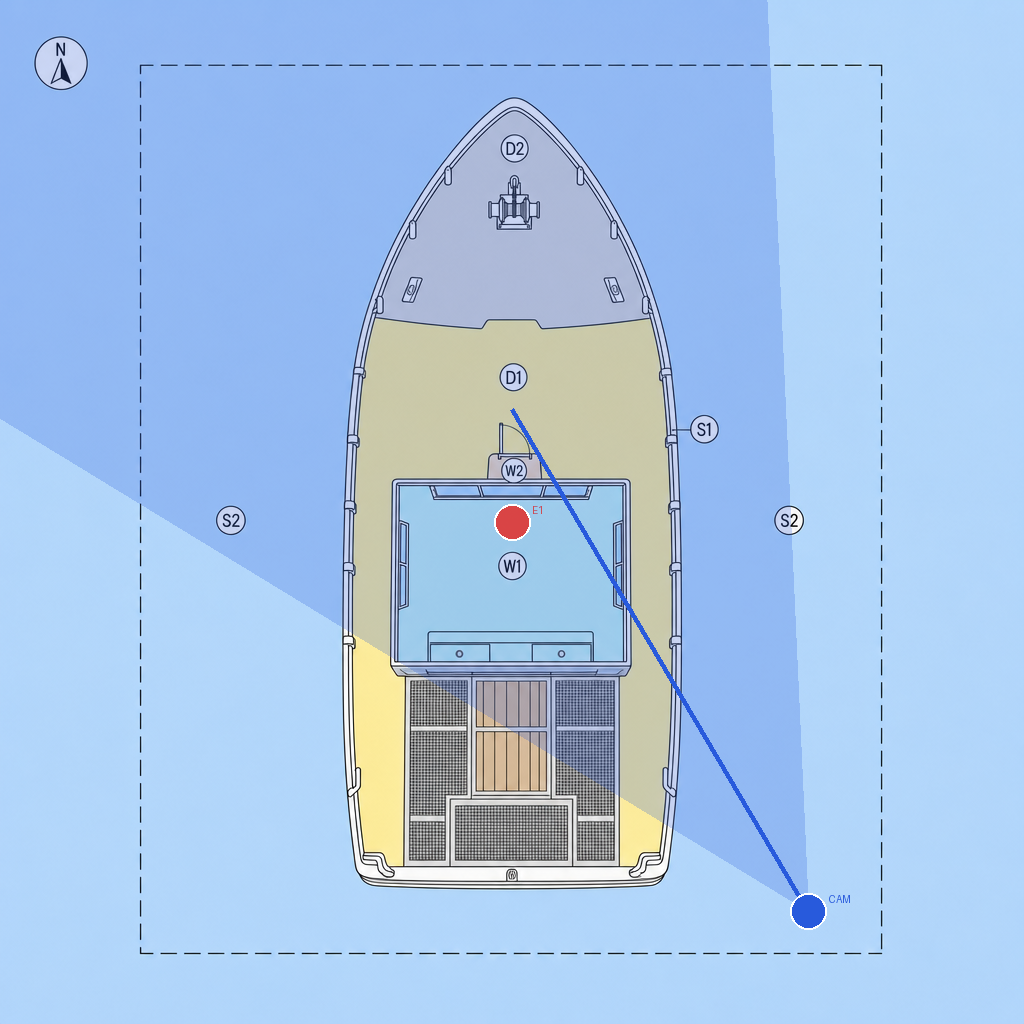
BASE 맵
PIL control (현행)
nb2 control (실험)
스케치 — PIL 기반 (현행)
스케치 — nb2 기반 (실험)